
Zoox Patents a Color-Coded Lane Map System for Its Self-Driving Cars
When a self-driving car gets a destination, it needs to know not just where to go but which lane to be in at every moment. Zoox's latest patent describes a system that colors a bird's-eye map of nearby lanes to reflect exactly how much each lane aligns with the car's planned route, then uses that picture to make steering and speed decisions.
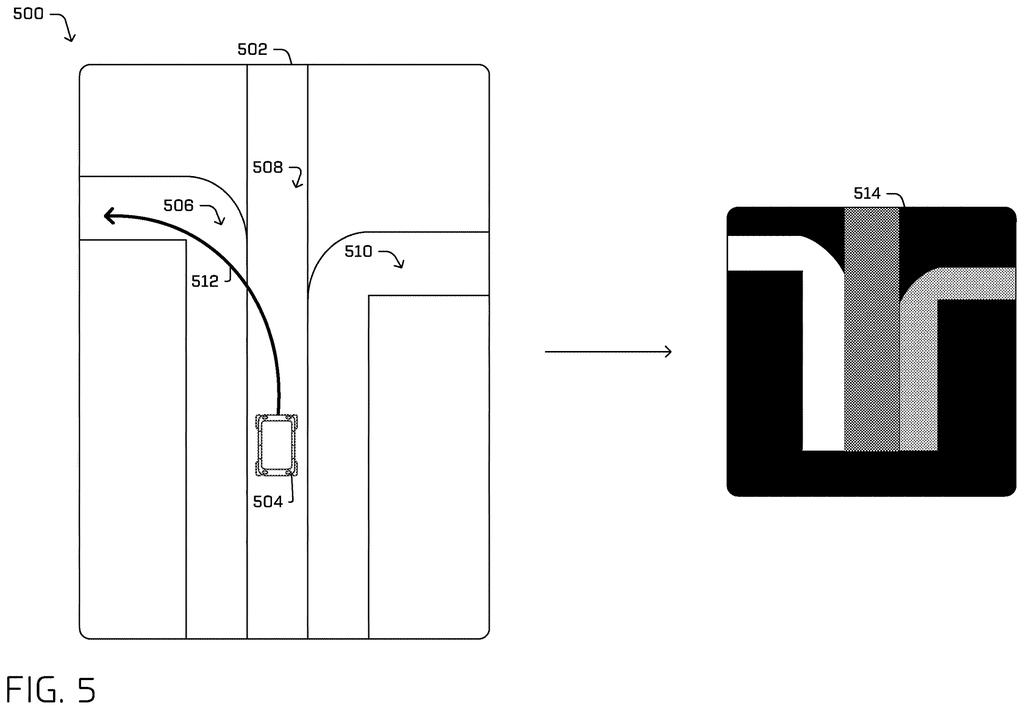
How Zoox's colored lane maps guide a driverless car
Today's self-driving cars carry detailed digital maps, but a static map alone can't tell a vehicle which specific lane to commit to as it moves through a live, changing environment. That gap between "head to this address" and "merge left now" is where most routing complexity lives.
Zoox's approach turns that gap into a picture. When the car receives a destination, it generates a local map of the lanes immediately around it, then calculates how much its planned path overlaps with each lane. That overlap score gets translated into a color value, so lanes that closely match the route get one color and irrelevant lanes get another. The result is a top-down, color-coded image of the road around the vehicle.
The vehicle's control system then reads that colored image to decide when to steer, accelerate, or change lanes. It's a bit like giving the car a highlighted map rather than a paragraph of directions, turning a complex routing calculation into a visual signal the car's software can act on quickly.
determining a data structure comprising a representation of a driving lane in an environment; receiving a path for a vehicle to traverse through the environment; determining, based at least in part on the path, the representation of the driving lane; and controlling at least one of a steering system or an acceleration system of the vehicle …
Translation: The car maps out its lane and route to steer and speed up safely.
How overlap data becomes a steering and throttle signal
The system works in three main stages.
First, the vehicle builds a local graph, a data structure that represents the driving lanes in its immediate vicinity. Unlike a full city map, this graph focuses only on what's nearby and relevant right now.
Second, the system measures overlap data: how much of the vehicle's planned path physically coincides with each lane in that local graph. A lane that runs parallel to the route for a long stretch gets a high overlap score; a lane the car is about to leave gets a low one.
Third, those overlap scores are converted into color values and painted onto a top-down (bird's-eye) image of the surrounding road. The claim describes the output as one or more "colored top-down images" of the driving lanes.
Finally, that colored image feeds directly into the vehicle's steering and acceleration systems. The control logic reads the image to determine what the car should do next, keeping the vehicle in the lanes that best match its route without requiring a human-readable instruction at each step.
The vehicle may utilize the overlap data to determine a color value(s) to associate with the driving lane(s) in a top-down image. Accordingly, based on determining the color value(s), the vehicle may generate colored top-down image(s) of the driving lane(s) and use such data to control the vehicle.
Translation: It assigns colors to lanes on an overhead map to help guide its driving.
What this means for robotaxi reliability on real streets
The routing problem in autonomous vehicles isn't really about finding a path from A to B. Mapping apps solved that years ago. The hard part is translating a high-level route into continuous, moment-by-moment lane decisions on streets that don't always match the map. A car that hesitates or picks the wrong lane in a complex intersection is a safety and efficiency problem, not just an inconvenience.
Zoox keeps filing around full-stack autonomous vehicle control, and this patent fits that pattern. For passengers in a Zoox robotaxi, a system like this would mean fewer abrupt lane corrections and more predictable behavior in dense urban areas, the exact conditions where autonomous vehicles have historically struggled most.
This is the 26th Amazon filing we've tracked in our self-driving sensing race since May, following earlier Zoox work like a radar speed fix and a polite lane-change scorer.
The problem this patent addresses is genuinely difficult. Urban intersections, lane drops, and construction zones expose a fundamental weakness in autonomous driving: the gap between a route planner saying "go here" and a control system knowing which lane to occupy at each second. Getting that wrong costs time, causes erratic maneuvers, and in the worst cases creates accidents.
The approach here, converting route-lane overlap into a color-coded image that feeds the control system, is an interesting way to unify routing and low-level vehicle control into a single pipeline. Encoding the routing intent as a visual signal is elegant because it means the same image-processing infrastructure the car already uses for camera feeds can handle routing decisions too.
That said, this is one patent in a very large engineering puzzle. Self-driving companies file hundreds of patents covering incremental pieces of their systems, and it's impossible to tell from a single filing how central this technique is to Zoox's actual software stack. The underlying problem is real and costly; whether this specific coloring method is the best solution to it is a question only road performance data can answer.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
8 drawing sheets from US 2026/0274305 A1 · click any drawing to enlarge


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in