Waymo and Nvidia Patents in the Self-Driving Sensing Race, and What They Reveal
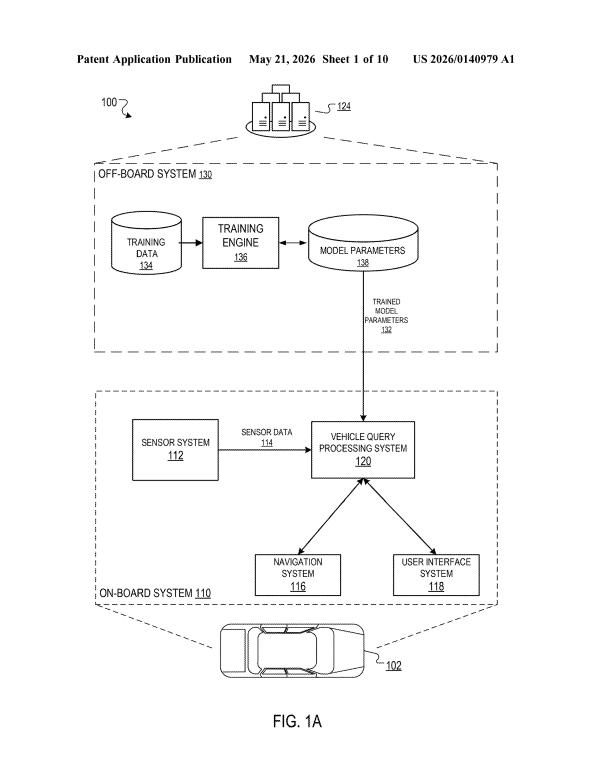
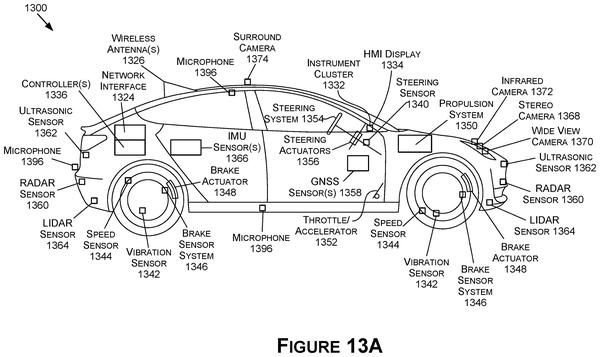
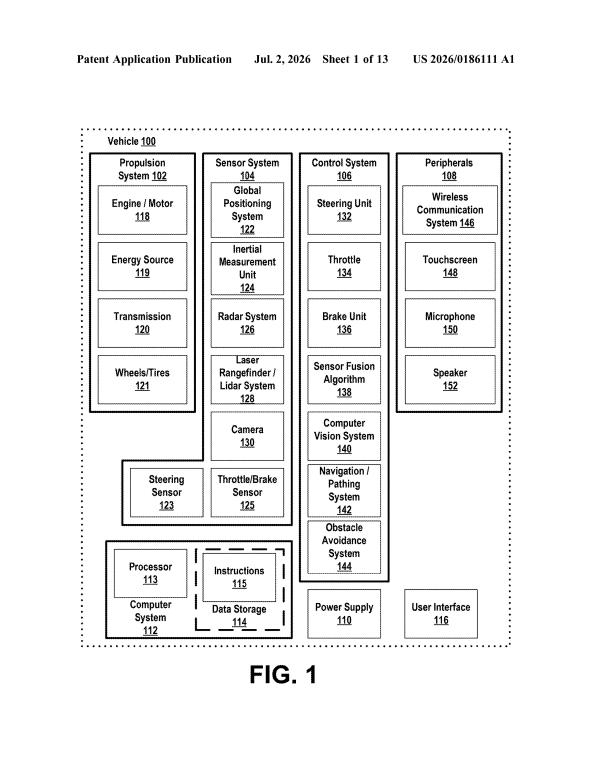
This watchlist tracks Waymo and Nvidia patents on the sensors, models, and software that let self-driving cars map roads, hear sirens, see through fog, predict hidden pedestrians, and time lane changes. Together the filings show two companies working to close the gap between raw sensor data and split-second driving decisions.
355 filings
· tracking since Apr 2026 · latest Nov 2026 · updates weekly
based on all tracked filings in this watchlist · refreshes every week
These patents fight over the same core question: how does a car see the world well enough to drive itself safely, covering everything from reading brake lights through fog to predicting where a pedestrian is about to walk.
Nvidia and Google carry the most weight here by raw filing count, with Nvidia pushing hard on what cameras and radar understand and Google focused on how a car decides what to do with what it sees.
What’s new in the self-driving sensing race
a dated entry each week this watchlist moves · older entries stay archived
Nov 5, 2026 22 filings joined
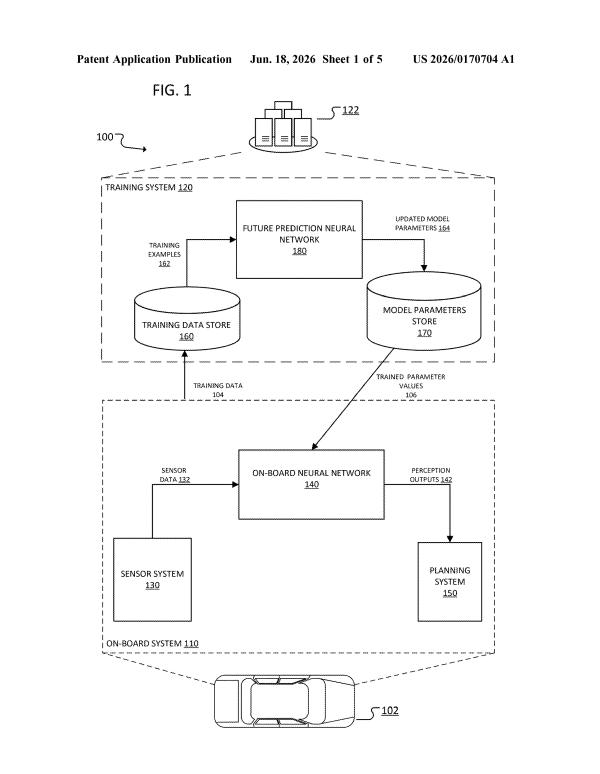
Qualcomm and Waymo led this week, each filing heavily around cameras, sensors, and road awareness. Most new work focuses on helping cars see more clearly, judge distance, and handle tricky road conditions.
Nvidia leads this week with six filings, mostly around helping cars spot and track people and vehicles nearby. Google and Sony also filed, covering smoother braking and better distance sensing.
Nvidia leads this week with six filings covering radar, cameras, maps, and parking. Most new filings focus on helping cars see and understand the world around them more clearly, especially in bad conditions.
Nvidia leads this week with eight filings covering everything from spotting road hazards to teaching cheaper sensors to do more. Sony and the two Intel filings round out a week focused on making cars see and locate things more reliably.
Most new filings this week focus on helping cars see and sense better, from night cameras to rain-clearing windows. Nvidia leads the pack, with Google and Qualcomm also filing several sensing and prediction ideas.
Most filings this week focus on helping cars see, predict, and make decisions more reliably. Google and Nvidia are the busiest, with Google pushing prediction and self-grading tools and Nvidia targeting cameras, depth sensing, and image quality.
Nvidia leads this week with eight filings covering how self-driving cars see, map, and catch their own mistakes. Google and Qualcomm also added filings around predicting other drivers and flagging road dangers.
Nvidia leads this week with filings on merging sensor feeds, spotting blind spots, and running dual decision systems. Qualcomm also filed several patents around depth sensing, camera alignment, and focusing on the most dangerous objects first.
Most new filings focus on helping self-driving cars sense, check, and understand the world around them more reliably. Qualcomm and Nvidia are the busiest this week, each filing multiple patents on reading sensors and catching errors.
This week's filings lean heavily on helping cars see through problems: hidden objects, bad weather, timing errors, and tampered footage. Nvidia and Sony each added multiple patents, with Nvidia focused on spotting blocked objects and Sony focused on catching errors in its own sensors and cameras.
Aug 27, 2026 21 filings joined
This week's filings are heavily focused on helping self-driving cars see and map the world more reliably, covering everything from sharper cameras to smarter road maps. Nvidia and Sony led the pack, with Nvidia filing the most patents overall and Sony pushing hard on camera and sensor work.
Aug 20, 2026 12 filings joined
Most filings this week focus on helping self-driving cars see more clearly and handle gaps in what their sensors pick up. Nvidia and Google each added four patents, with Nvidia targeting sensor accuracy and Google focusing on blind spots and bad conditions.
Who’s filing patents in the self-driving sensing race
counts from tracked filings · focus read from each company’s own filings
The battlegrounds inside the self-driving sensing race
the fights inside the fight · each with its three newest filings · new filings join every week
Cars That Share What They See 20 filings
Qualcomm 5, Nvidia 4, Google 3
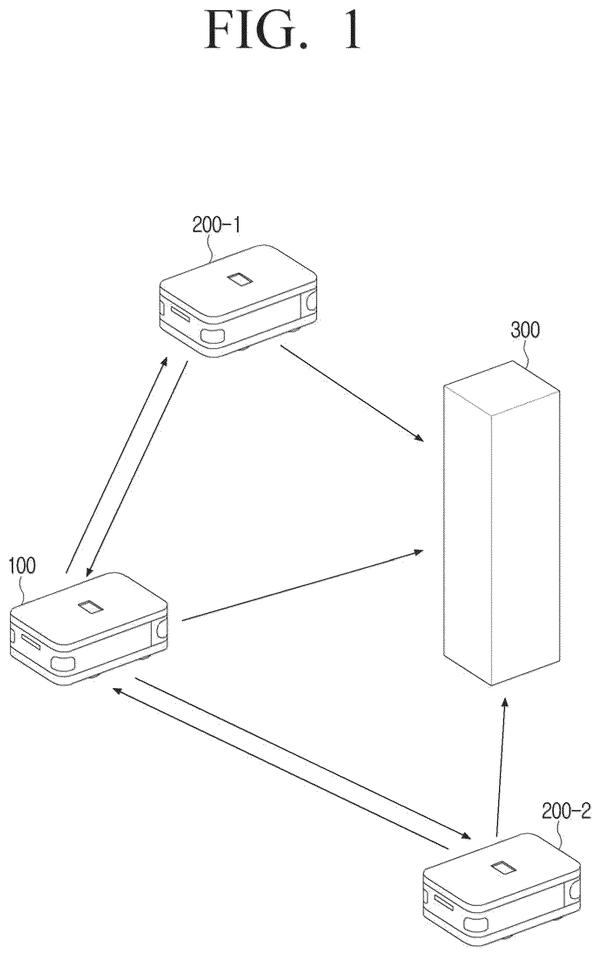
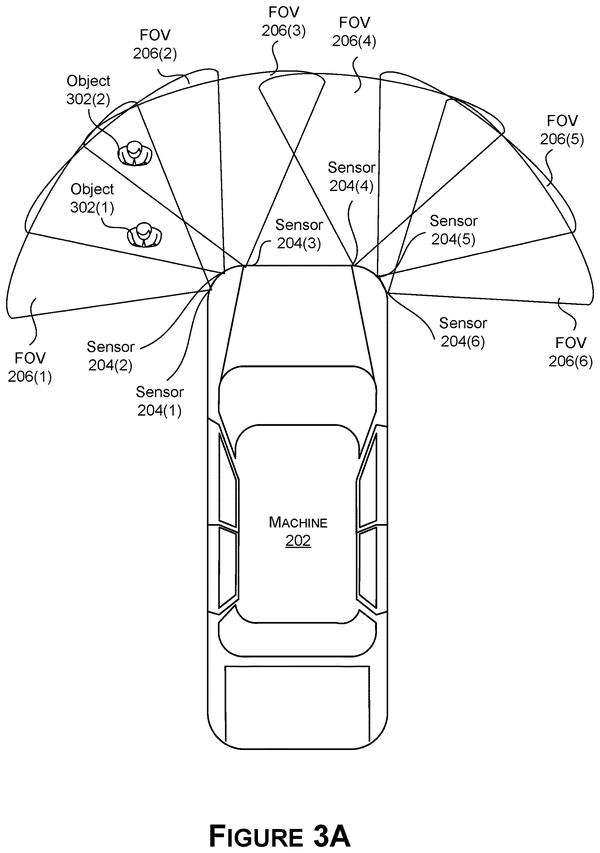
Several companies are filing around the idea of vehicles sharing sensor readings with each other to cover blind spots and verify locations. The filings range from sharing raw sensor feeds to cross-checking positions using shared landmarks.
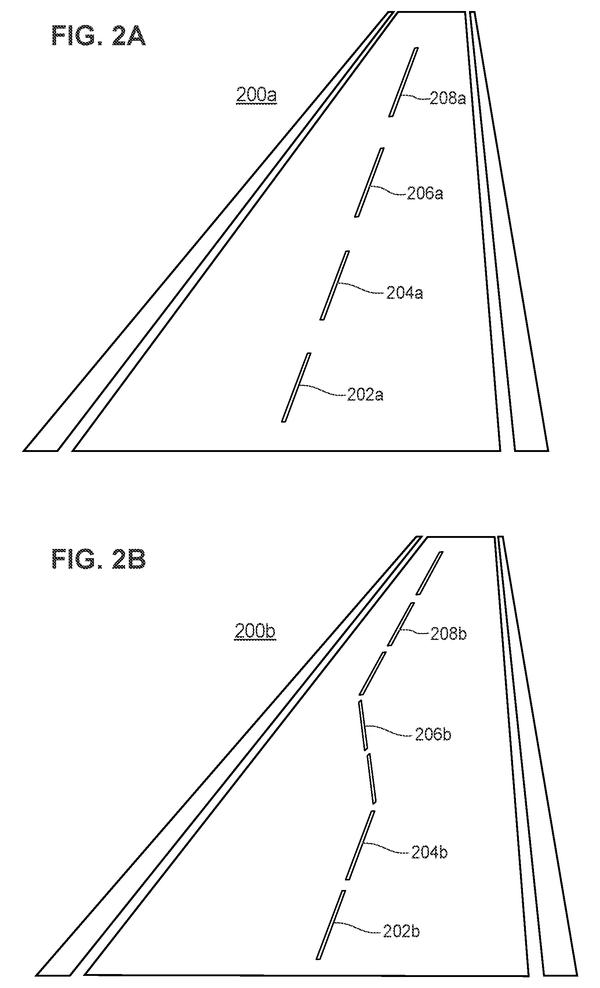
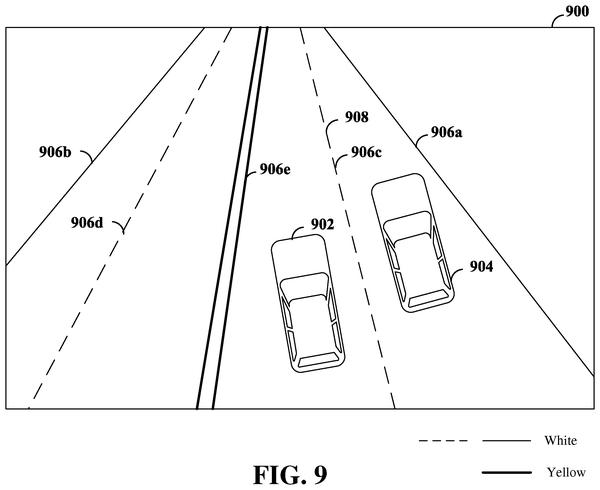
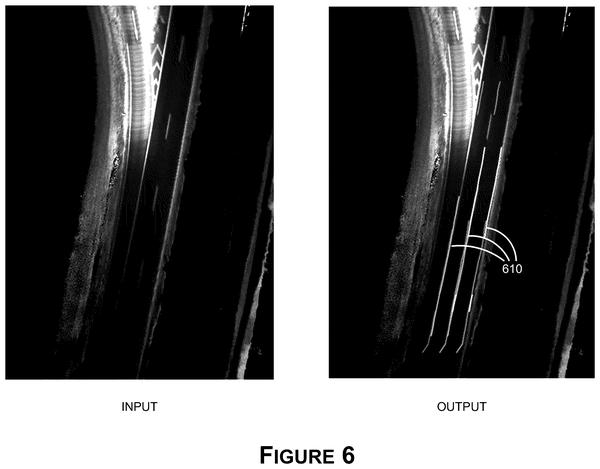
A large cluster of filings covers how cars identify lane lines, road signs, road wetness, and markings from camera and radar feeds. The aim is a car that understands the road surface itself, along with the objects on it.
Multiple companies are filing around sensors and cameras that detect when they are broken, blocked, or giving bad data and then correct themselves without a human stepping in.
Building 3D Pictures From Ordinary Cameras 36 filings
Nvidia 18, Qualcomm 7, Sony 6
Rather than relying on expensive dedicated depth sensors, several companies are filing ways to pull three-dimensional information out of regular camera footage.
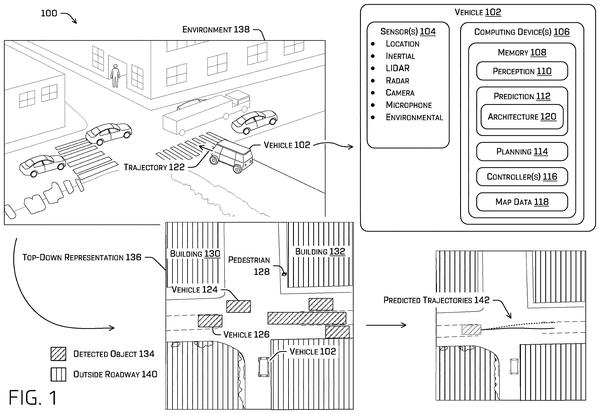
A tight group of filings focuses on guessing where pedestrians, cyclists, and other drivers are about to move before they move. They cover body language, hidden pedestrians, and future movement of all road users at once.
Because real dangerous situations are rare, companies are filing systems that generate artificial driving scenes to train their software. These pipelines create or label fake data so the car learns from situations it has never actually seen.
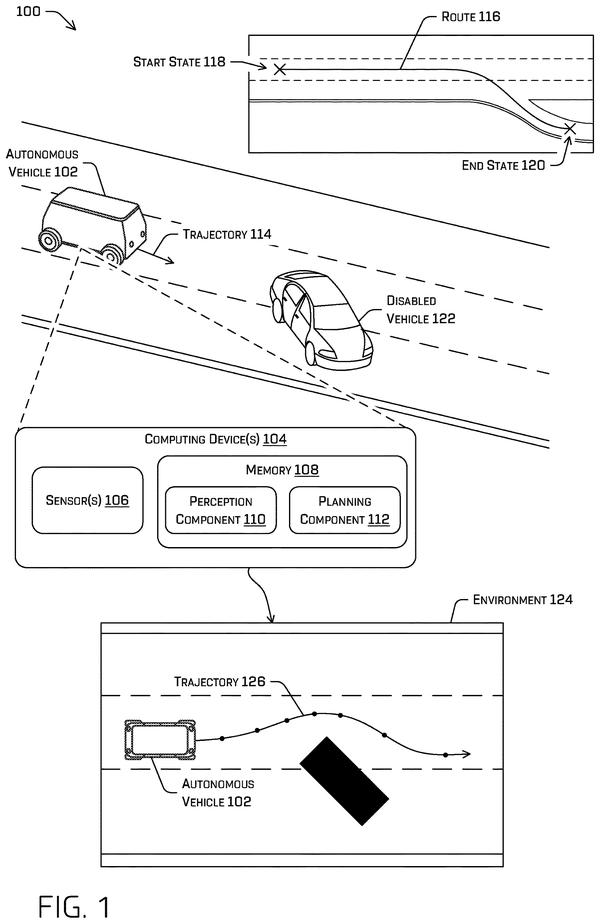
Once the car can see, it has to pick a route and weigh the risk of every move: dodging collisions, handling double-parked cars, deciding which threats to ignore.
Sensors that keep working in weather and bad light: heated windows, invisible light for night, lidar that adapts to fog or spots reflectors before they blind it, anti-glare glass.
Zoox adds a localization recovery layer: the car uses distinctive landmarks like charging bays and parking spaces as visual anchors to relocate itself after power loss or being towed, fixing the cascade of errors that follows a bad position estimate.
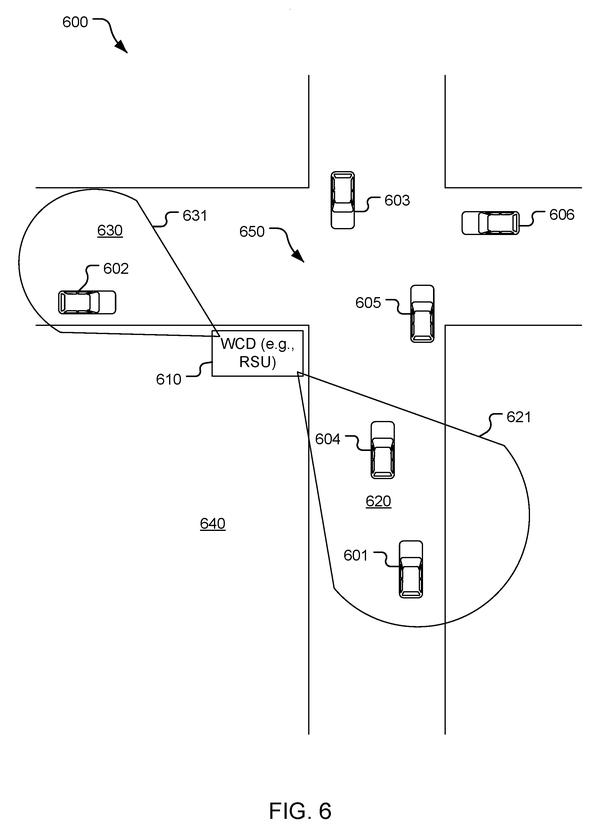
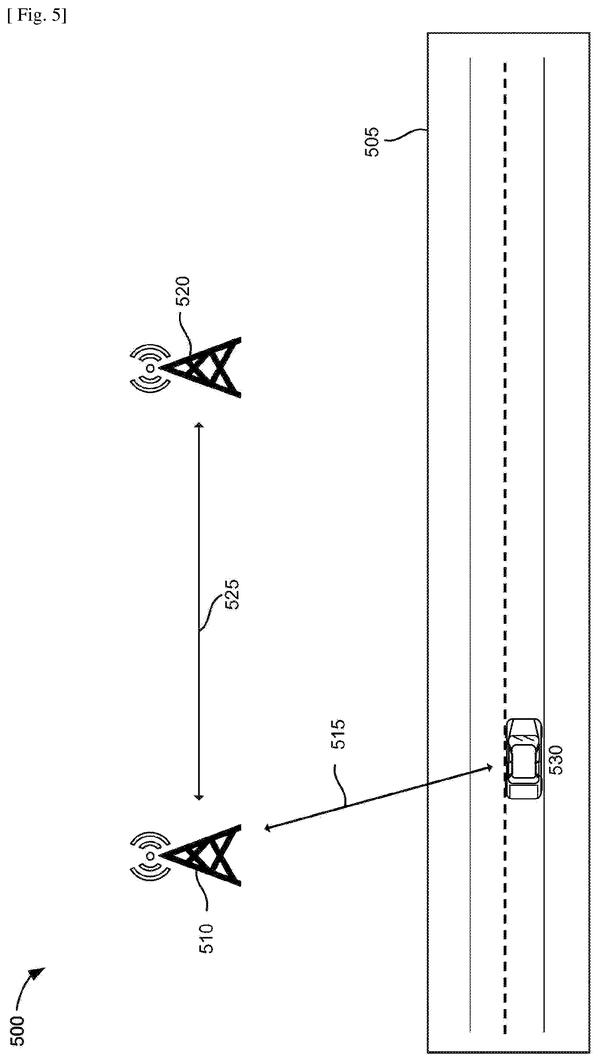
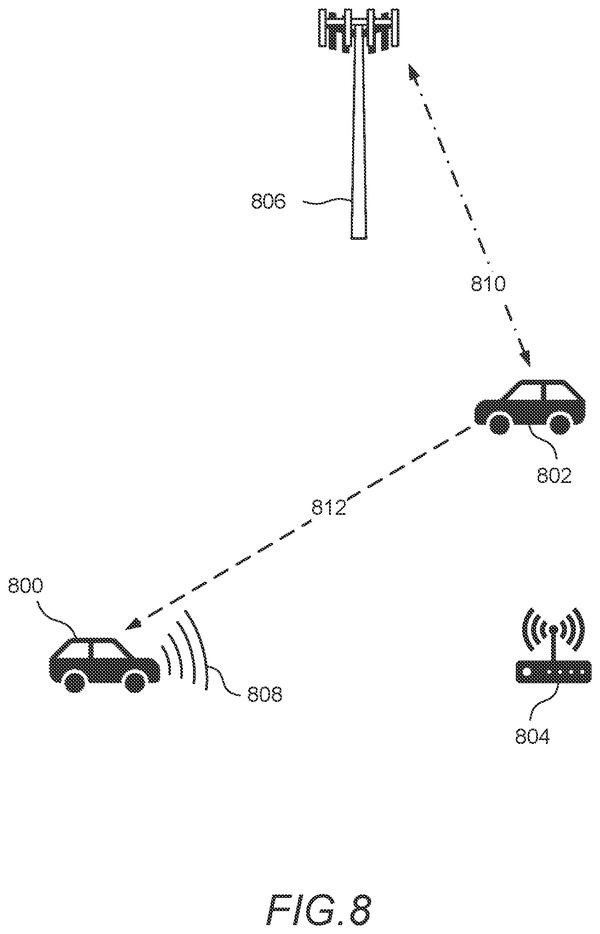
The watchlist has focused on sensors and prediction models; this patent shifts to the connectivity layer, ensuring network handoffs between cell towers don't drop the safety guarantees a self-driving system requires.
Maps rely on stale lane geometry during construction. This patent lets camera-equipped cars detect shifted lines and feed corrections back to the server, keeping navigation current.
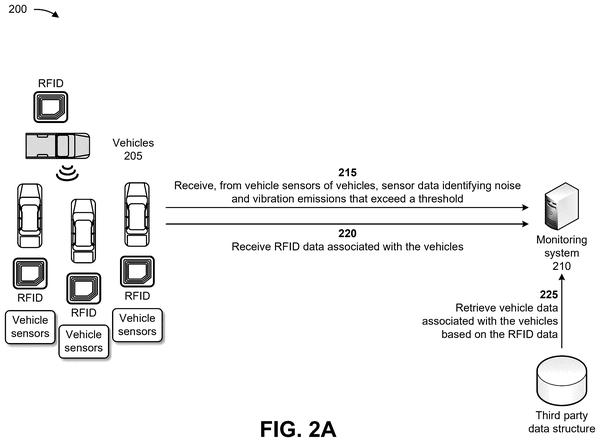
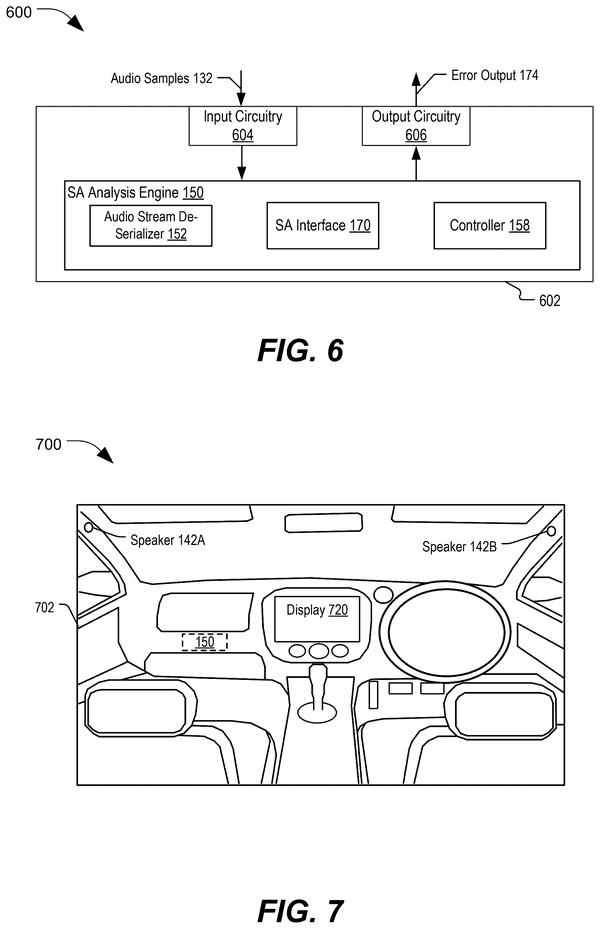
The watchlist has focused on what cars sense about roads and pedestrians; this filing shifts to identifying other vehicles by their acoustic signature, using sound to flag mechanical problems that affect safety.
The watchlist so far has focused on what the car's sensors see. This filing shifts to monitoring what the driver sees, flagging safety gaps when attention breaks from its normal pattern on familiar routes.
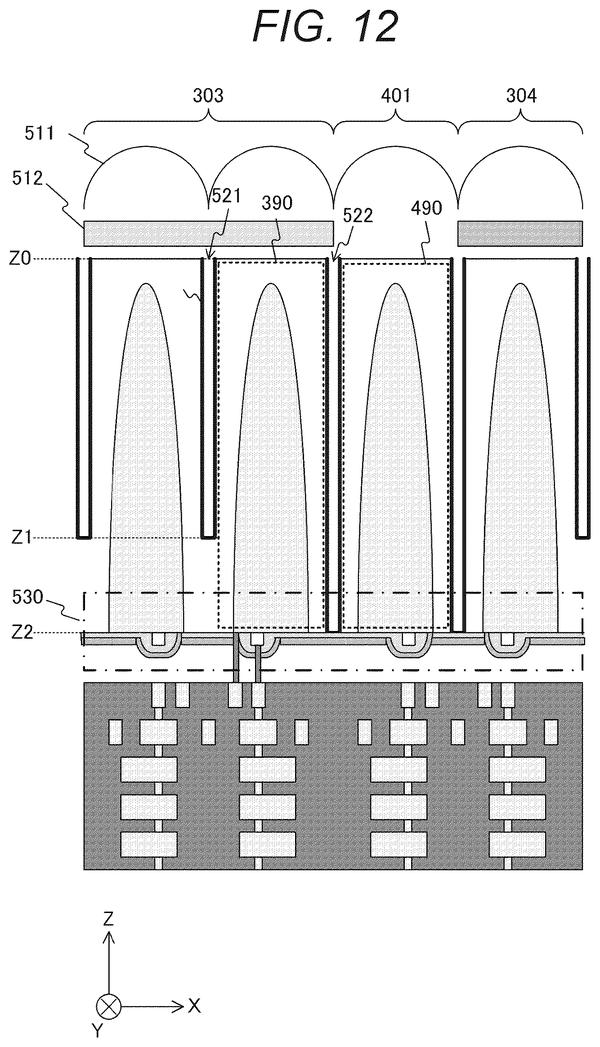
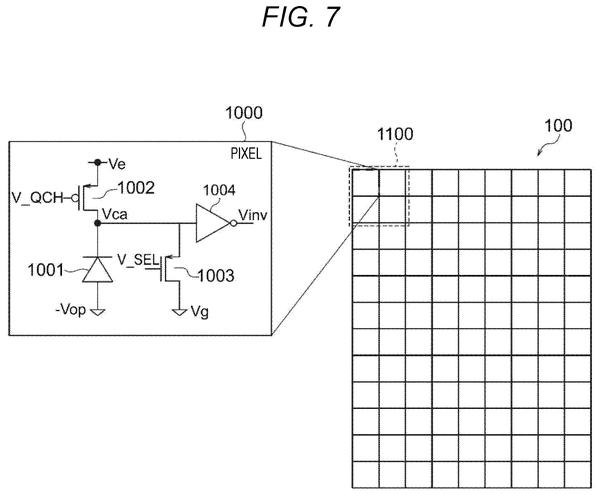
Dual-pixel sensors need isolation to work: Sony's tiny barriers keep motion-detection pixels from crosstalk when standard imaging pixels fire, solving a core problem for real-time hazard spotting.
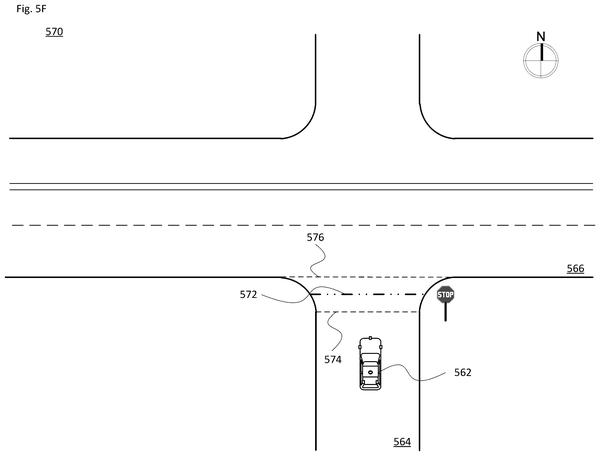
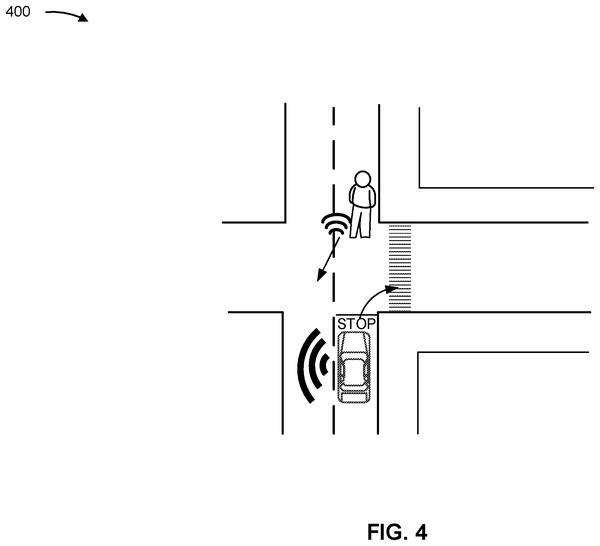
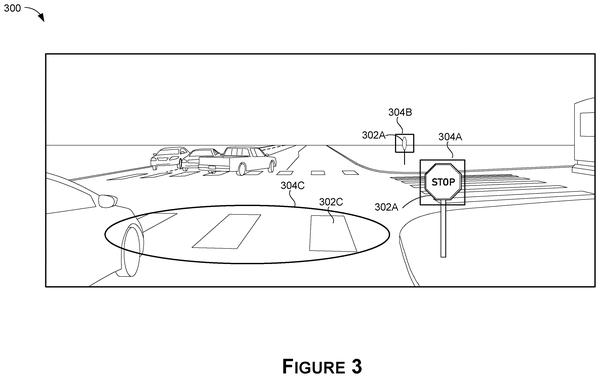
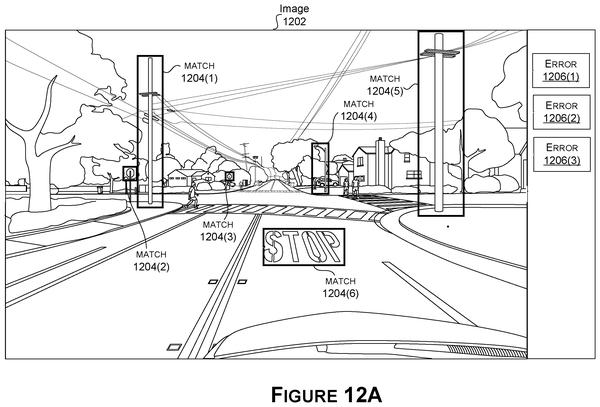
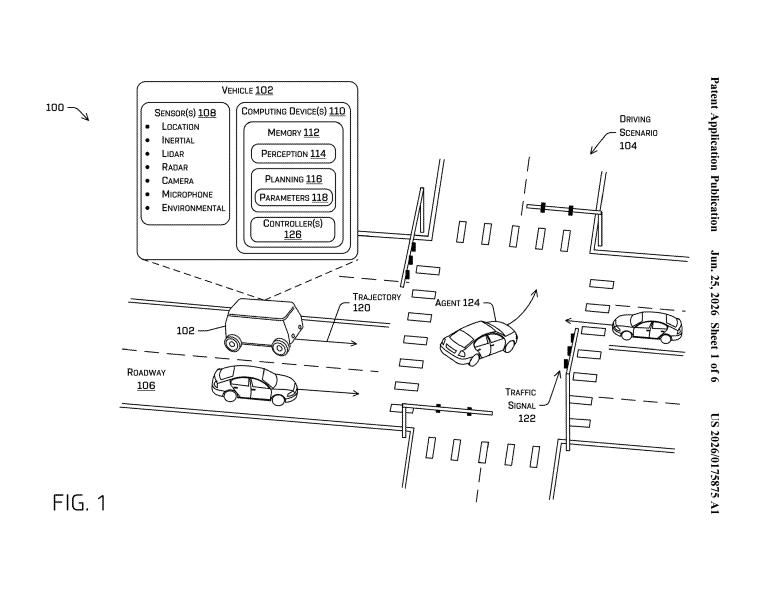
Stop signs without painted lines test whether the car can replicate human judgment about safe stopping position. This filing confirms Waymo's focus on the ungoverned intersections that still trip up most autonomous systems.
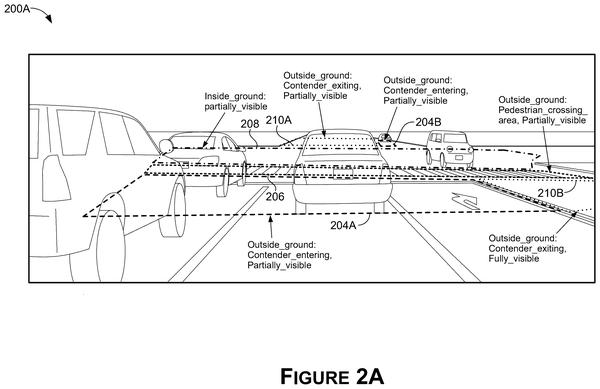
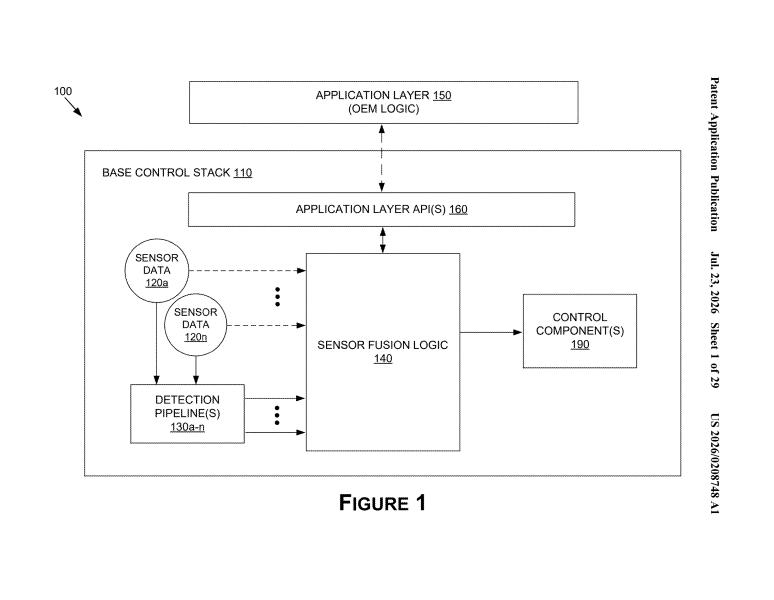
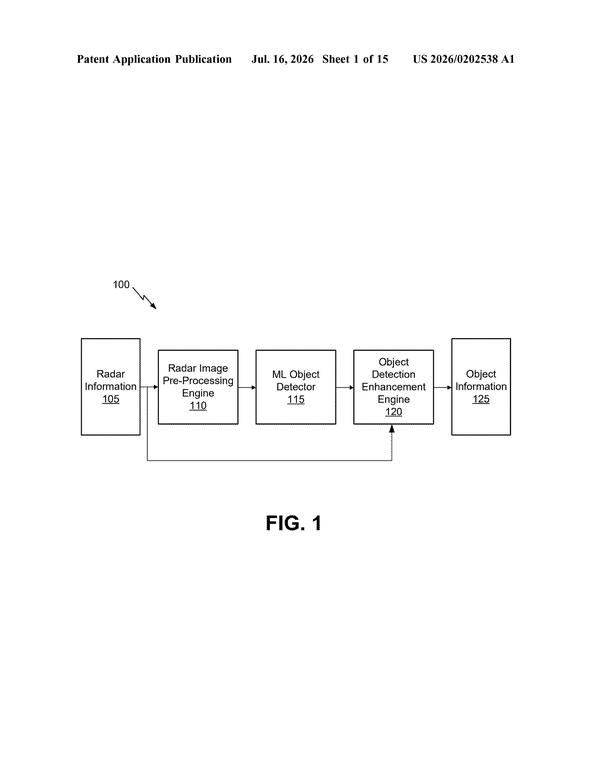
Radar and lidar pre-filter camera processing by flagging likely vehicle locations, letting the vision system focus compute on detecting brake lights instead of scanning every pixel.
The sensor's dual-pixel approach lets self-driving cars detect motion without the computational overhead of processing continuous full-color video, reducing the load on downstream perception models.
Rolling shutter timing varies frame to frame as a car moves, and Qualcomm's patent embeds those exposure details directly in the video file so training models know exactly when each pixel was captured.
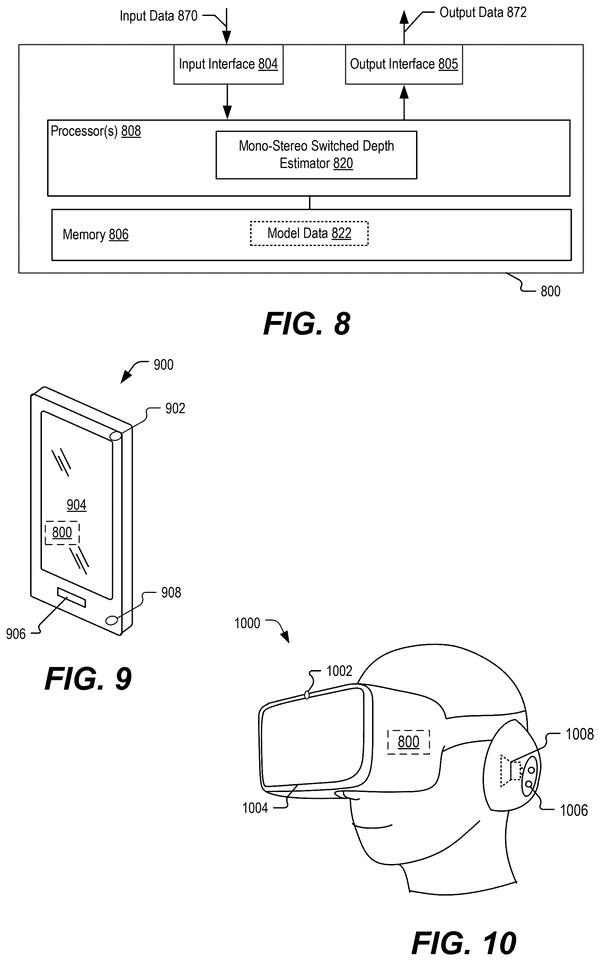
Switching between monocular and stereo depth sensing per frame lets autonomous vehicles trade off precision and power consumption on the fly, rather than locking into one mode for an entire drive.
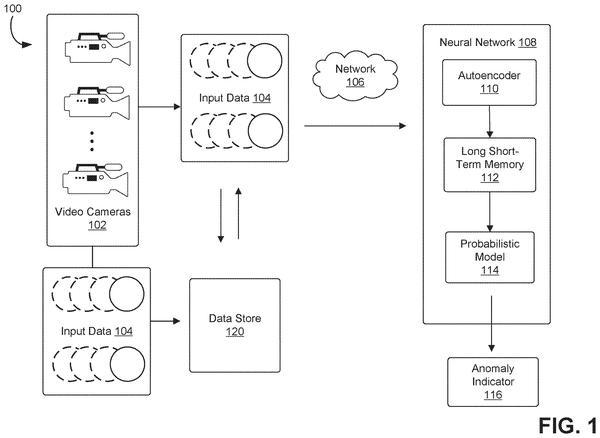
The sensor suite needs to know what normal traffic looks like before it can spot hazards. Nvidia's approach learns baseline patterns from continuous video, then flags deviations without building separate detectors for each edge case.
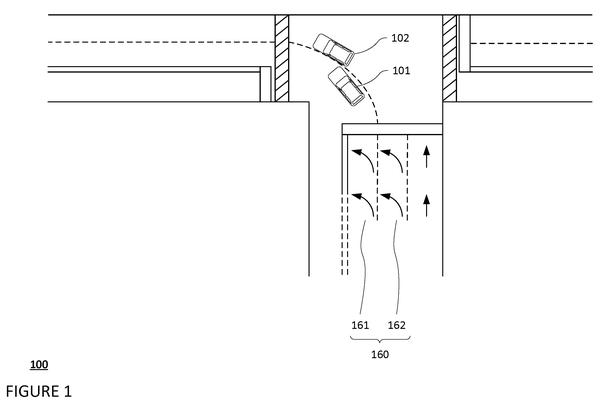
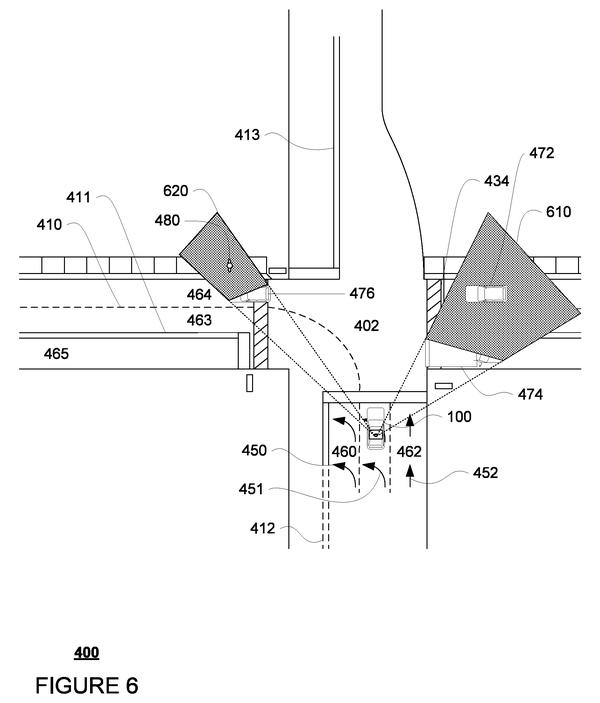
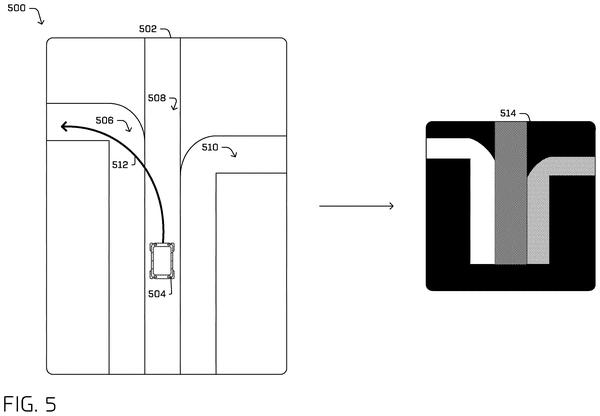
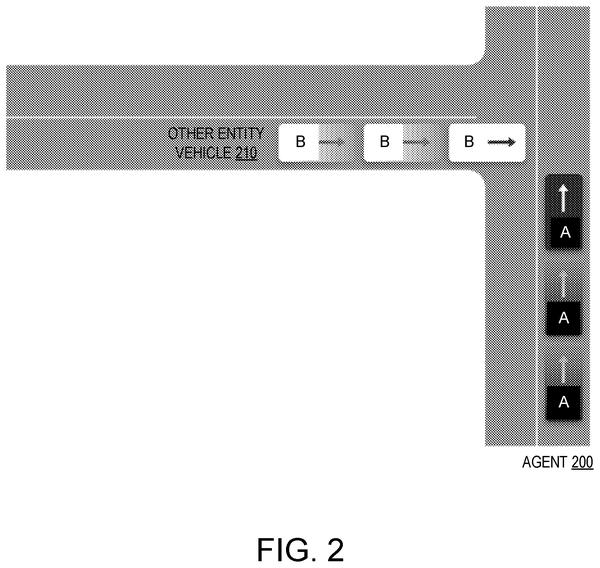
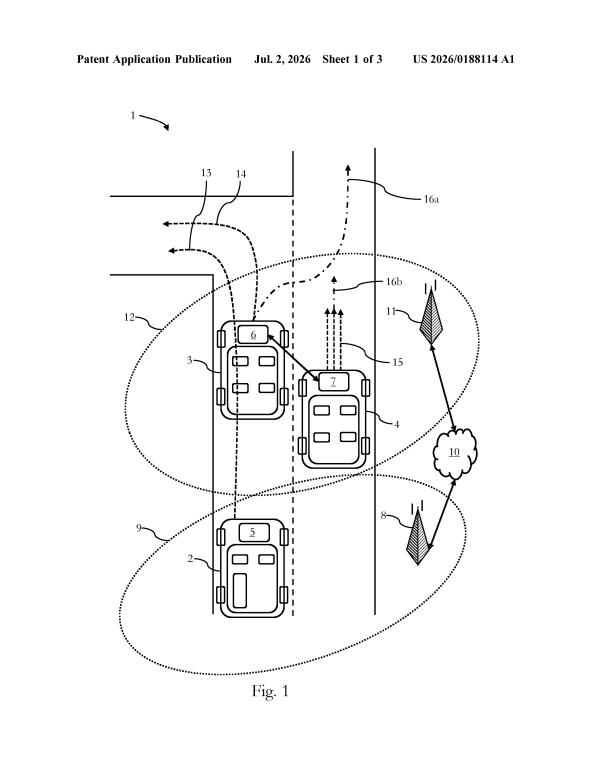
Positioning the autonomous vehicle wider on double left turns keeps it visible to adjacent cars that naturally cut the corner, converting a collision risk into a predictable passing geometry.
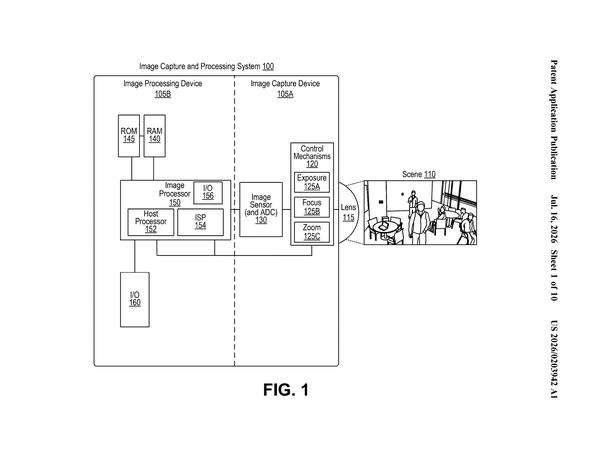
Camera frame processing has been a bottleneck in the sensing pipeline, Nvidia's approach pipelines edge detection across different core types to keep up with the constant stream of frames arriving from multiple cameras.
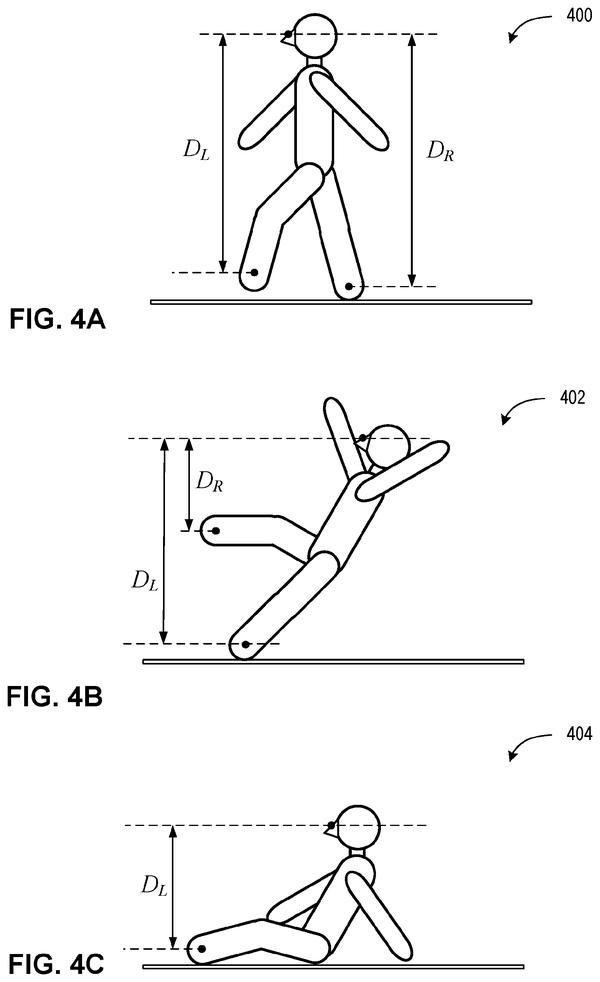
Predicting pedestrian falls before impact: Waymo's approach uses skeletal pose detection to spot loss of balance in real time, letting the car brake or swerve ahead of a collision rather than respond to one already underway.
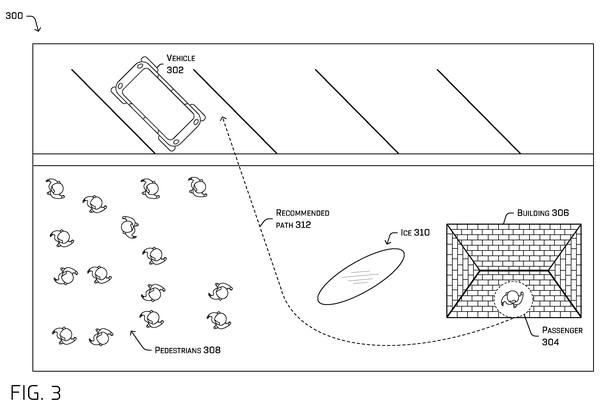
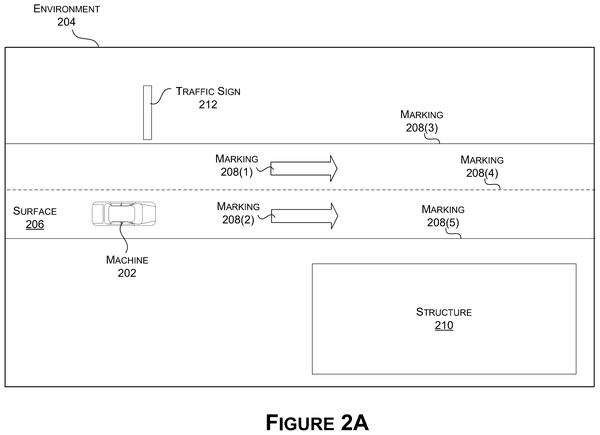
The sensing race includes mapping road conditions in real time: Waymo's system flags slippery surfaces and redirects pickups away from ice or water, then notifies the rider and adjusts arrival time accordingly.
Unified sensor fusion into a single environmental model cuts down error propagation between perception and planning stages that plague sequential processing architectures.
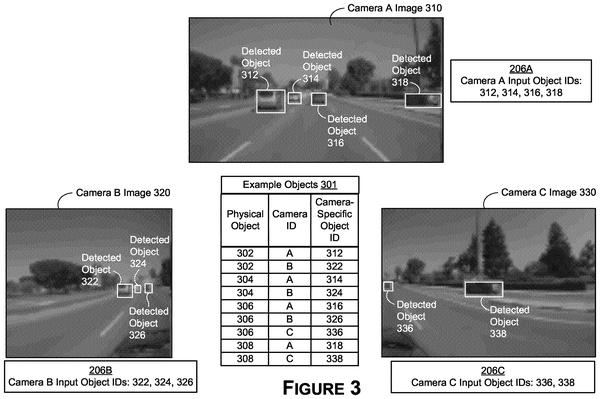
The multi-camera fusion problem gets sharper here: when overlapping fields of view catch the same object, the system must stitch those sightings into one track fast enough to avoid phantom duplicates that crash the prediction pipeline.
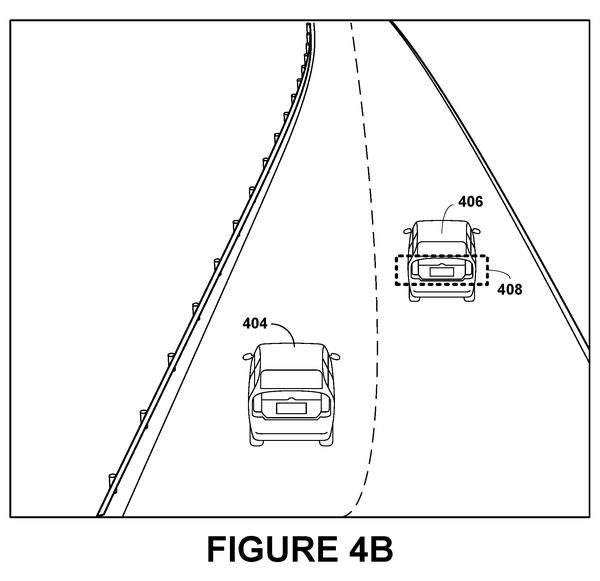
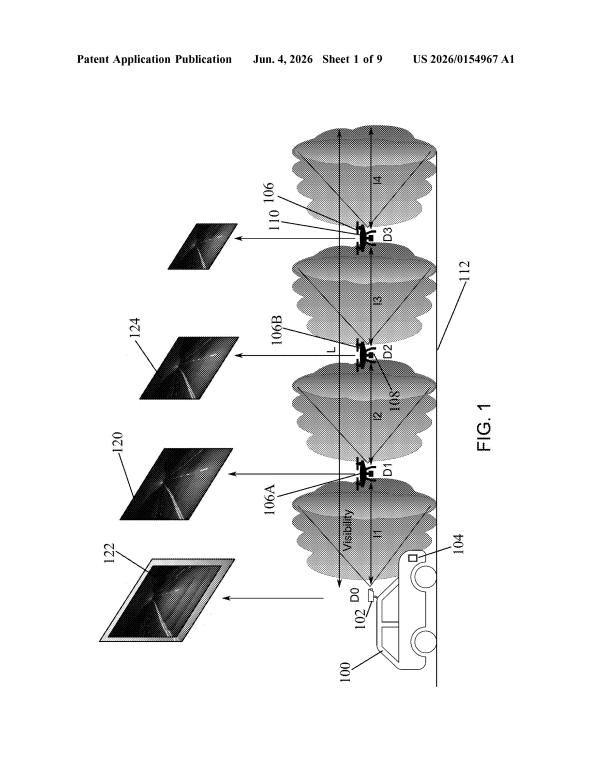
The sensing race has focused on what cars see ahead in poor conditions. This filing shows how to read brake intent from another vehicle's lights when fog and glare wash them out, using camera, infrared, and LiDAR in concert to catch signals humans would miss.
Sensor data is always incomplete, scanners see only what faces them. Nvidia's approach reconstructs hidden geometry to give test systems a full 3D environment instead of fragments.
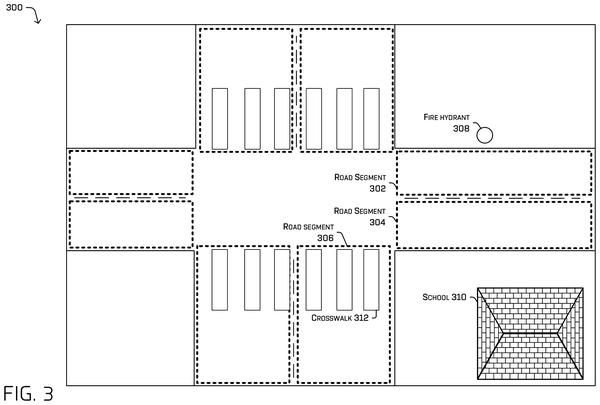
The watchlist tracks how companies predict what streets their cars can handle. Zoox proposes scoring each road segment on specific hazards like hills and school zones, replacing manual site surveys with a data-driven baseline for expansion decisions.
The watchlist has tracked Waymo and Nvidia building better road perception; Zoox extends that outward, using sensors to map hazards between the car and passenger so the app can reroute them to safer ground.
Propagating vehicle warnings past radio dead zones created by buildings requires intermediate relays, either roadside infrastructure or nearby cars, to retransmit safety broadcasts around obstacles that block direct signals.
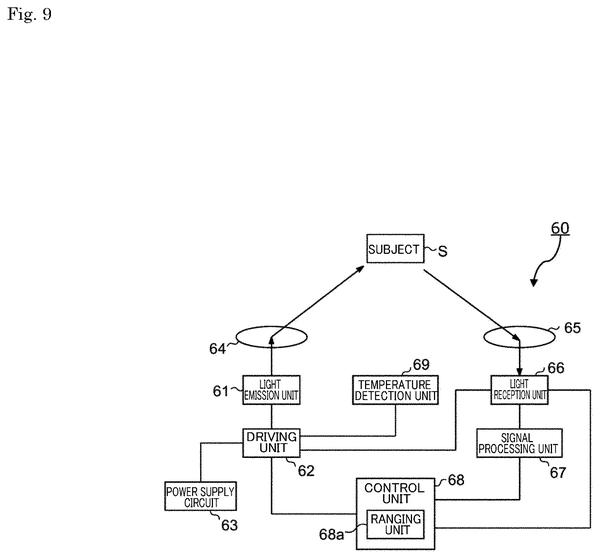
Keeping laser brightness consistent across different firing patterns means depth sensors can measure distance accurately whether scanning sparse or crowded scenes, fixing a voltage-drop problem that currently makes some returns weaker than others.
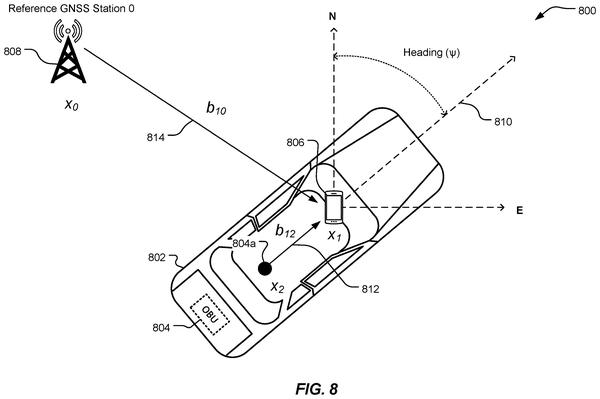
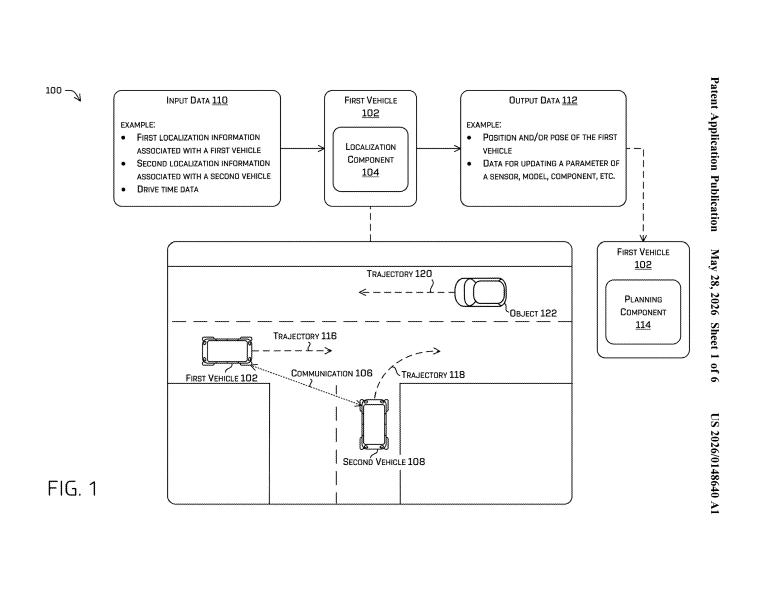
Localization on featureless highways: cars use painted lane markings as a common reference frame to calculate each other's position and heading from camera feeds alone, eliminating dependence on landmarks or infrastructure.
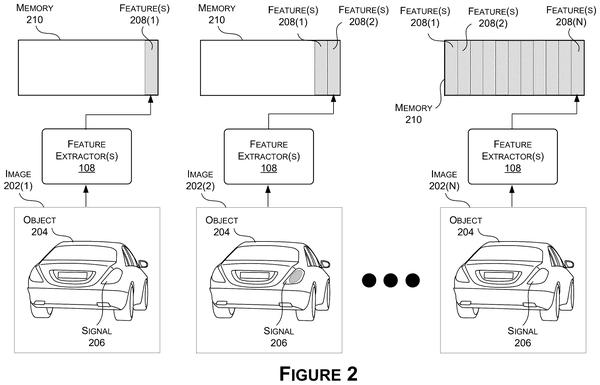
Self-driving cars need to track turn signals across multiple camera frames to distinguish actual blinking from momentary occlusion or timing gaps in image capture.
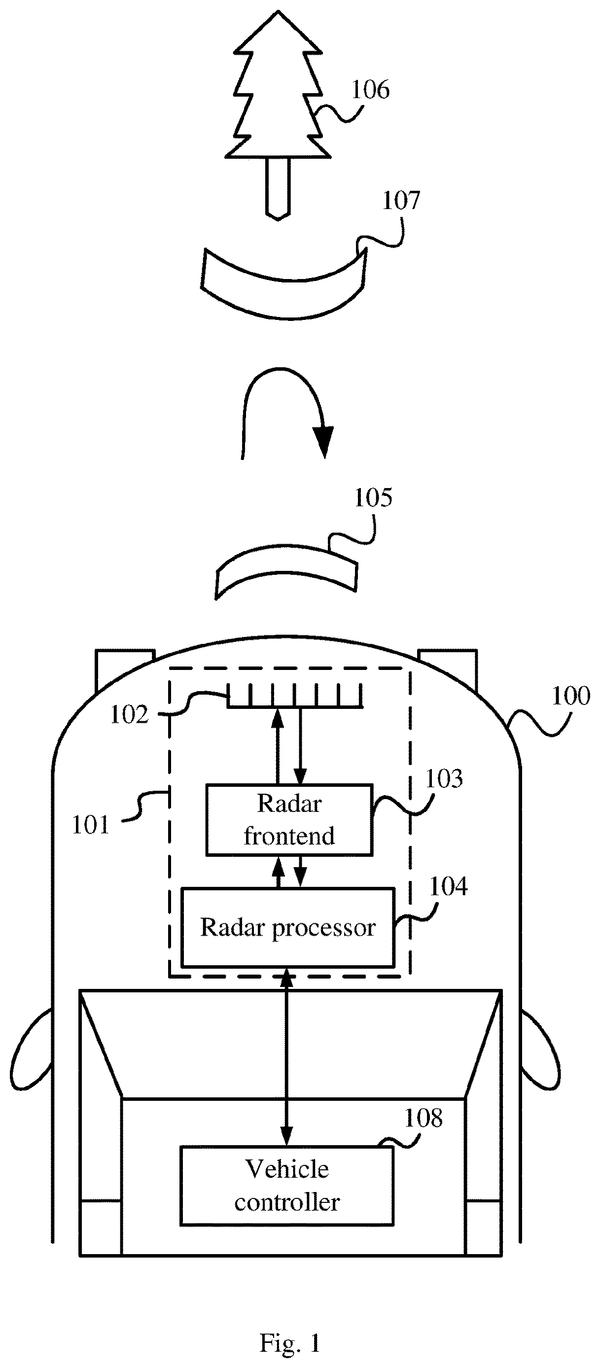
Separating a stalled truck from guardrail clutter requires radar to pick out targets at sharp angles without multiplying antenna count. Mobileye's uneven antenna spacing lets noise fade naturally at wide angles while keeping beam focus tight.
Filtering out irrelevant traffic before tracking begins cuts processing load and lets the system focus compute on nearby vehicles that affect driving decisions.
Matching pedestrians across frames requires linking 2D camera images to 3D spatial models; Nvidia's approach runs parallel tracking in both domains to prevent confusion between nearby objects.
Sensor noise has pushed Waymo toward filtering out false threats. This patent adds tolerance zones that let the car proceed cautiously through marginal detections instead of panic-braking on every jitter.
Better driving means checking each planned move against real-world constraints. Waymo's approach evaluates the AI's route segment by segment for collision risk, passenger comfort, and legal compliance rather than just copying human driving patterns.
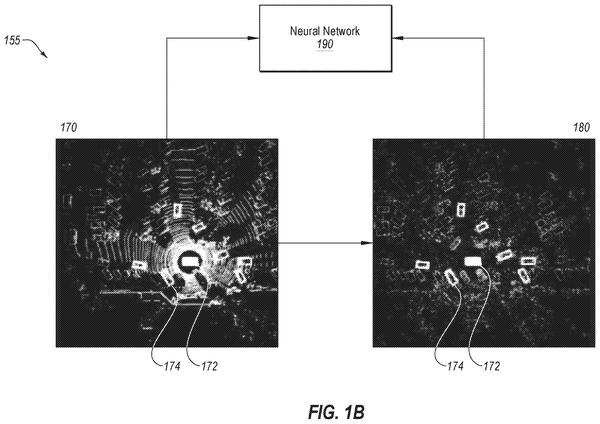
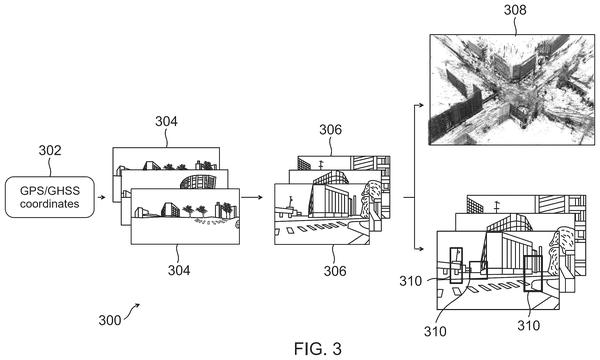
Self-driving cars need to recognize pedestrians in laser scans to brake safely. Nvidia's method trains that recognition by having humans label normal camera images instead, where pedestrians are actually visible.
Laser beam drift during distance measurement degrades sensor accuracy on every sweep. Sony's approach maps systematic drift patterns and corrects them in real time, improving consistency without hardware redesign.
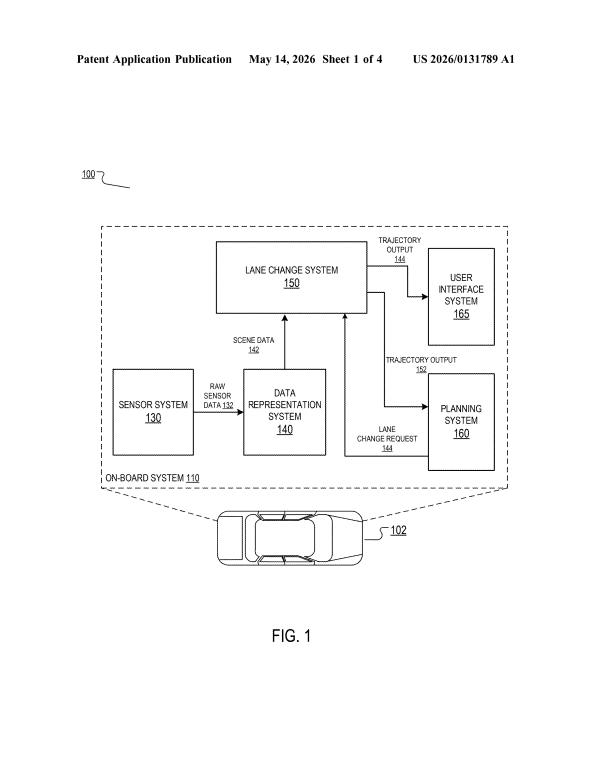
Self-driving on unmapped roads means relying on standard navigation cues instead of expensive custom maps. This filing shows how to execute lane changes from ordinary routing instructions, reducing the need for hyper-detailed road data.
Resolving ambiguous turn signals matters because a wrong guess cascades through downstream predictions. Nvidia's approach scores each possible road until one pulls ahead, rather than locking in a single choice early.
Predicting road geometry and surface type from camera images alone would let self-driving cars navigate unfamiliar terrain without relying on pre-mapped data, filling a gap in how they understand immediate driving conditions.
Geofenced broadcast zones let pedestrian phones transmit location only in high-risk areas like school crossings, cutting battery drain and network load while keeping detection active where collisions cluster.
A coarse filter ranks candidate driving moves by computational cost before the system runs full predictions, letting the car skip expensive simulations of unlikely paths.
Cameras trained on clean daylight photos fail in rain and darkness. Nvidia's approach lets the camera itself degrade its confident detections, creating synthetic poor-condition training data without needing to collect real bad-weather footage.
Radar velocity estimates get faster when the AI model validates its own speed guesses against raw sensor returns instead of waiting for multi-frame tracking to converge.
Camera-based localization using 2D map landmarks sidesteps the need for expensive, constantly-updated 3D mapping infrastructure that currently constrains deployment in new regions.
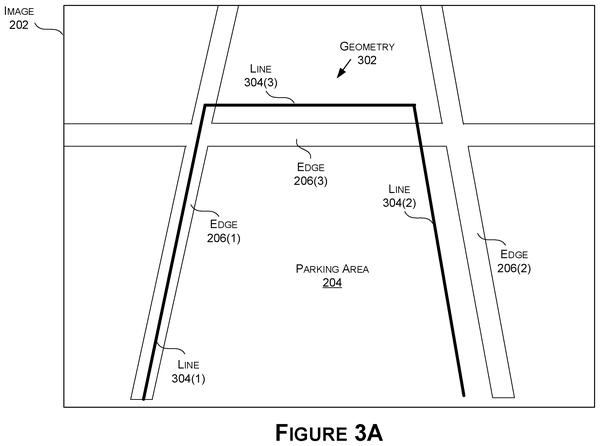
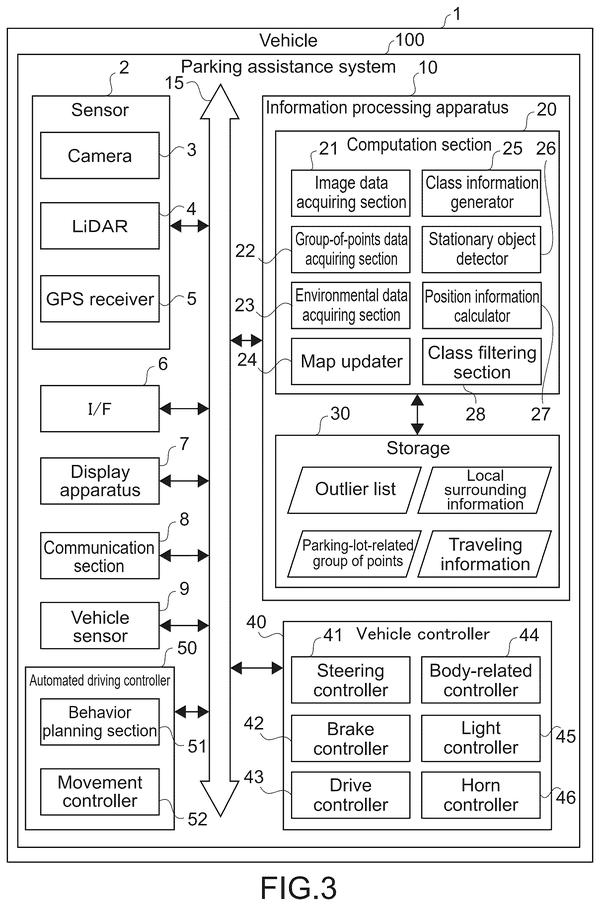
Edge detection refines AI parking-space predictions by cross-checking neural network estimates against raw camera edges, grounding learned guesses in physical line-finding where paint is worn or obscured.
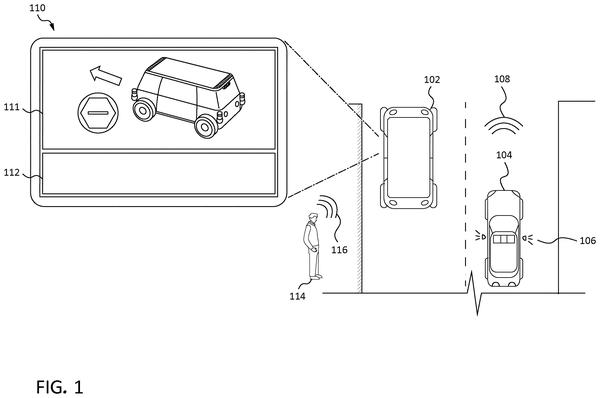
Self-driving cars need to broadcast warnings onto pavement; Sony's filing solves the collision-avoidance problem of identifying which vehicle sent each projection when multiple cars signal at once.
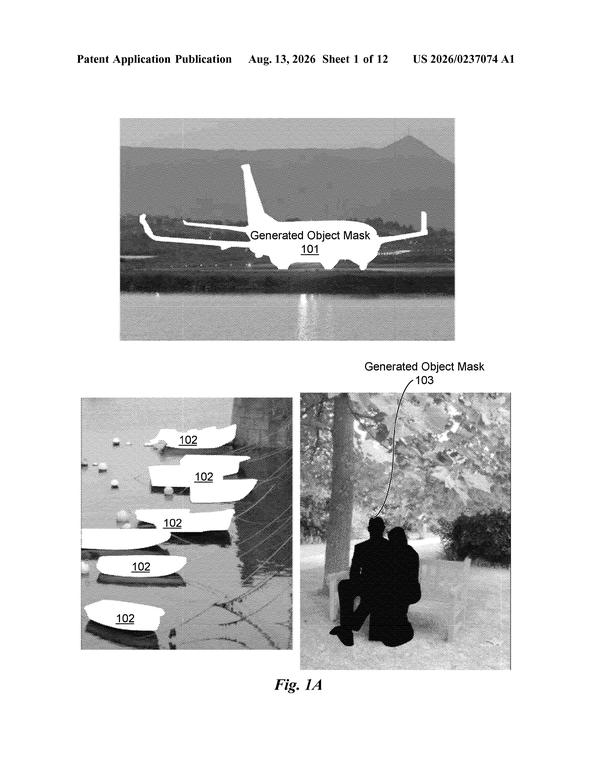
Laser sensors see partial objects all the time; this system generates training labels from video rather than requiring human annotation, letting engineers name new hazards in text.
A watchdog circuit that detects when a camera's internal clock drifts or fails, preventing the self-driving system from processing stale or corrupted image data without knowing the sensor has gone silent.
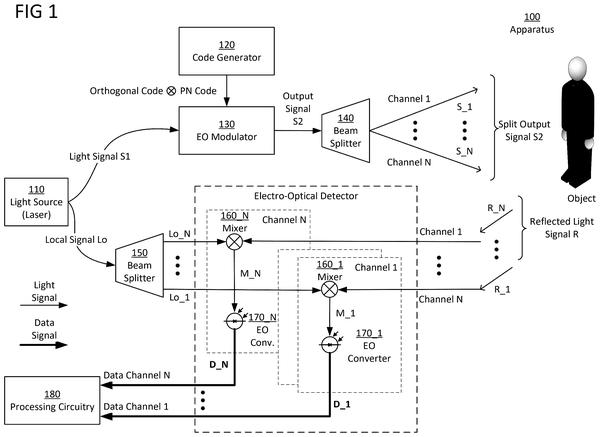
Sensor interference becomes critical as autonomous fleets scale: Intel's coded laser signatures let vehicles distinguish their own reflections from neighboring cars' pulses on crowded roads.
Selective denoising based on the eventual display region cuts processing load compared to cleaning all four camera feeds in full, sharpening the bird's-eye view feeds that actually reach the driver's screen.
Self-driving pickups depend on knowing where pedestrians can actually reach the curb. This patent lets cars learn real walking patterns from sensor data rather than trust static maps, so they stop where riders can realistically board.
The sensor fusion challenge here shifts from collecting rare events to synthesizing them: Nvidia's method generates unseen combinations of occlusion, speed, and weather rather than waiting for roads to provide them.
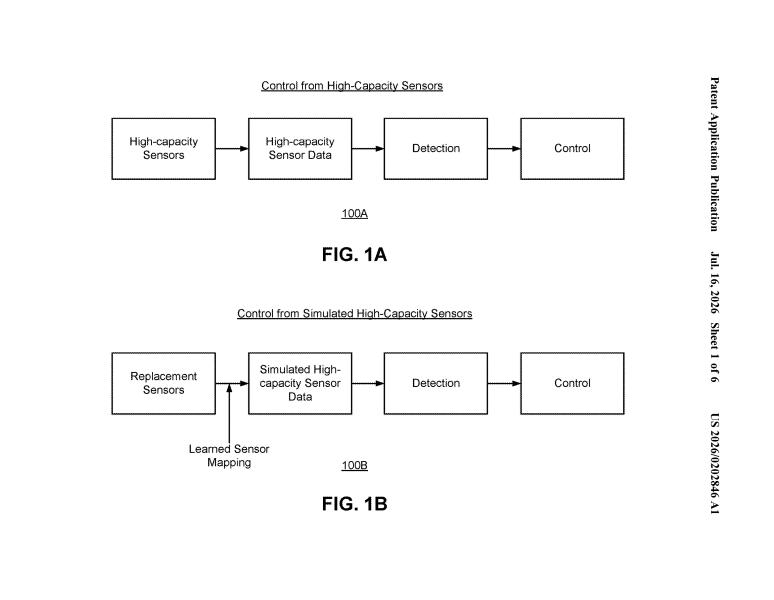
Radar learns to read a laser's 3D maps during training, then operates solo on deployed vehicles to cut both sensor cost and compute load in the perception stack.
Synchronizing camera and sensor timestamps across distributed hardware prevents the fusion errors that could send a misaligned car into the wrong lane or through a red light, triggering safe shutdown if clocks drift beyond tolerance.
Using map data to pinpoint where rare signs appear lets training systems skip through thousands of hours of video and grab only the relevant frames, cutting the work of building sign-recognition datasets.
Localization confidence scoring fills a gap in the perception stack: when sensor data grows sparse or ambiguous, the system now quantifies how much to rely on its position estimate rather than defaulting to potentially wrong assumptions.
Non-rigid alignment warps overlapping map sections into consistency, allowing edges to shift without cascading misalignment across the full map. Solves the registration problem when stitching vehicle-recorded tiles together.
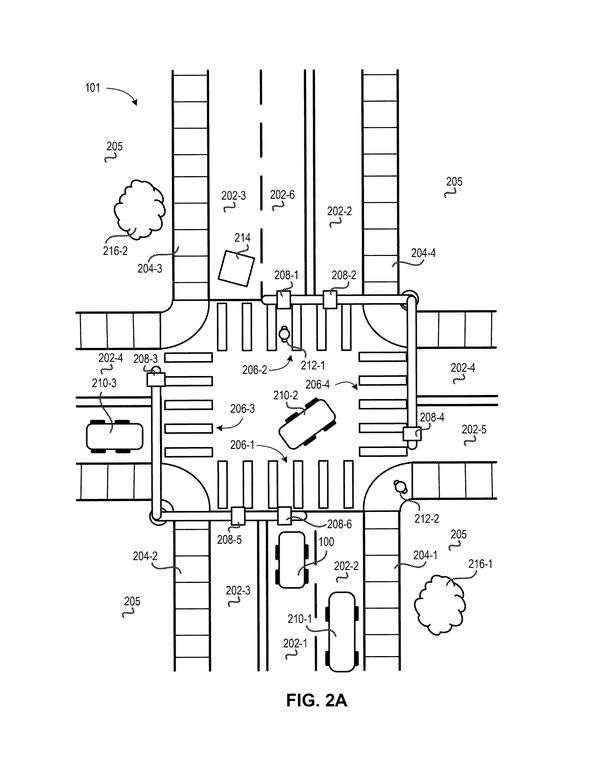
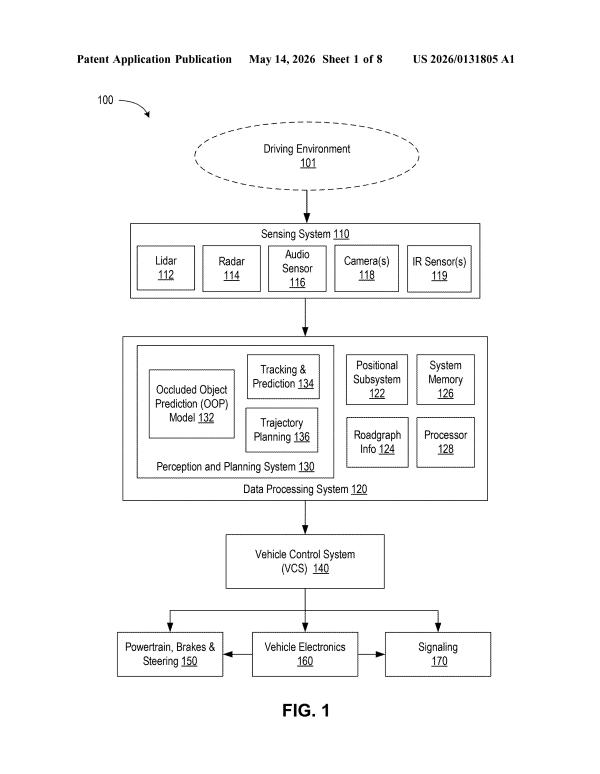
Predicting occluded pedestrians: Waymo's system maintains object tracking when sensors lose line of sight, preventing false assumptions about empty crosswalks.
Real-time height mapping lets the car detect road surface changes without relying on pre-loaded maps or image recognition, shifting obstacle detection from memory and learning to direct sensor measurement.
Nvidia's approach reconstructs occluded object geometry by learning from video sequences rather than hand-labeled 3D annotations, letting the system infer where hidden parts of parked cars and obstacles actually sit.
A laser that modulates its own pulse strength by adjusting electrical current, rather than relying on fixed internal design, solving the conflict between detection range and eye safety for objects right in front of the vehicle.
The sensing stack needs to understand not just what objects are present but how they behave. Nvidia's approach learns traffic patterns directly from raw video, building predictive models without manual labeling of driving behaviors.
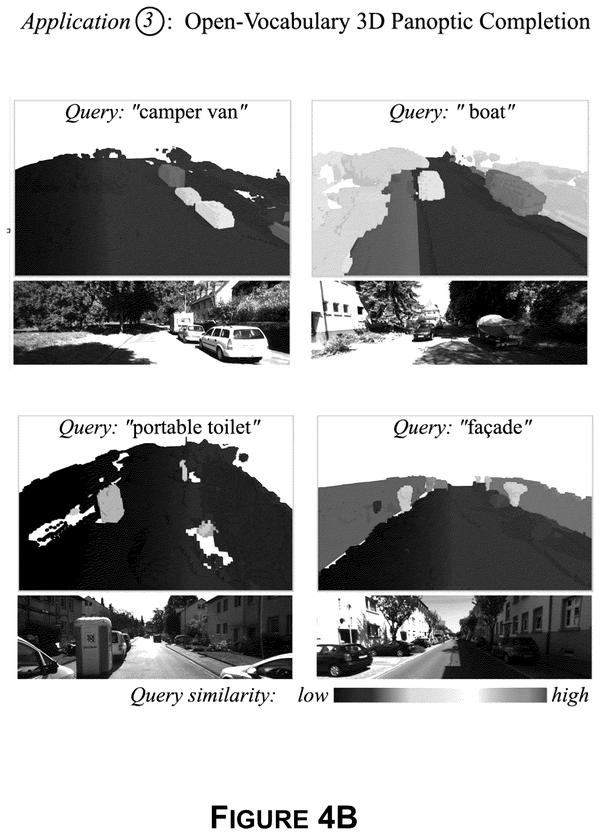
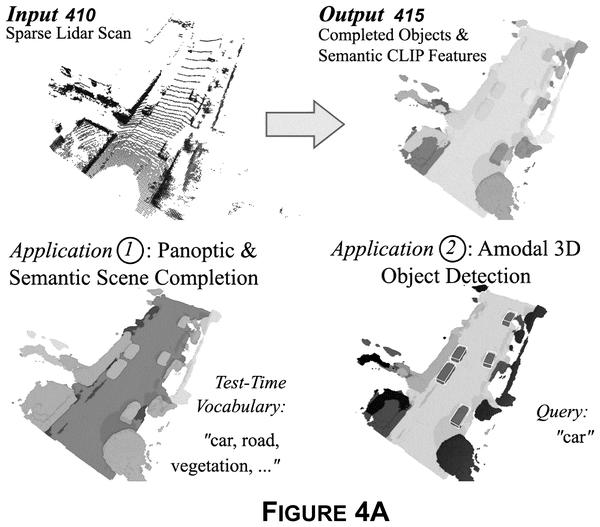
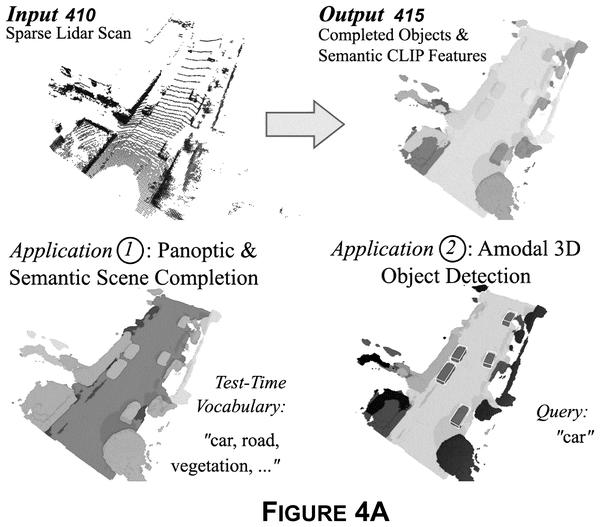
Laser scanner data gets converted to 3D object outlines that can be matched against any text description, letting the system recognize objects beyond its training set without retraining the underlying model.
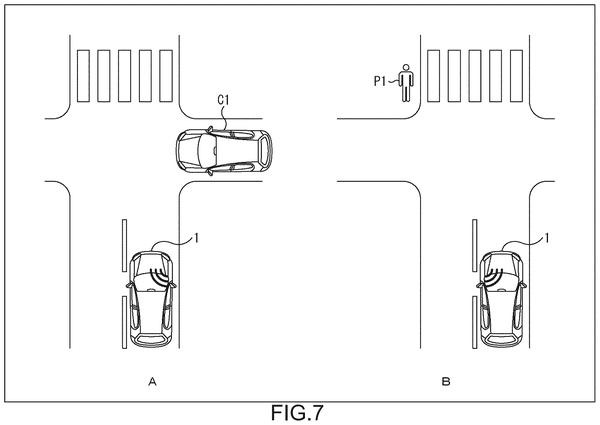
The car's audio system now catches police commands that a human driver would hear naturally, routing them to passengers and the vehicle's decision-making logic.
Cameras report their own exposure settings alongside the image feed, letting the car infer ambient light conditions and adjust headlights and display brightness without a separate light sensor.
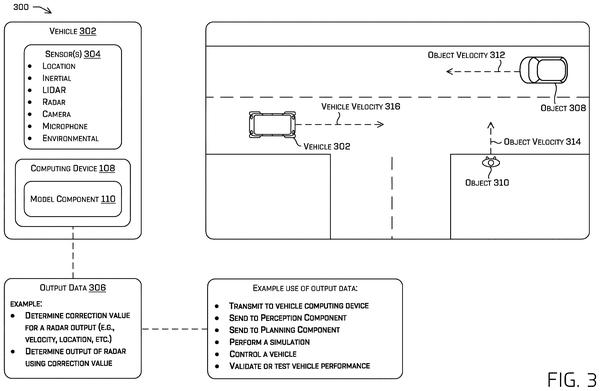
Waymo's dual-radar approach fills a critical gap in motion prediction: capturing lateral movement that single radars miss, which matters when distinguishing between oncoming traffic and pedestrians crossing adjacent lanes.
Front wheel angle gives earlier warning of a vehicle's intended turn than waiting for actual motion, letting the car predict and react to nearby traffic shifts sooner.
A distributed quality-scoring system where each vehicle grades lane paint segments and reports only the scores and locations, not raw camera feeds, lets autonomous systems build condition maps while cutting data transmission by orders of magnitude.
Infrared sensors on budget car cameras produce dim, noisy night images; Nvidia's method pulls fine details from the simultaneous color capture to reconstruct sharper thermal data for detecting pedestrians and obstacles in darkness.
Predicting what other cars will do requires reading their intentions, not just their lights. This patent adds motion-tracking as a reality check on turn signals, filtering out the false positives that camera glare and brake lights create.
A 3D model of the driver's head lets the camera measure actual eyelid position rather than guessing from a flat image, so head angle no longer tricks the system into false drowsiness alerts.
Spinning glass discs in front of cameras use centrifugal force to shed water and debris rather than relying on wipers or coatings, keeping sensors clear during rain without moving parts that could fail or block the view.
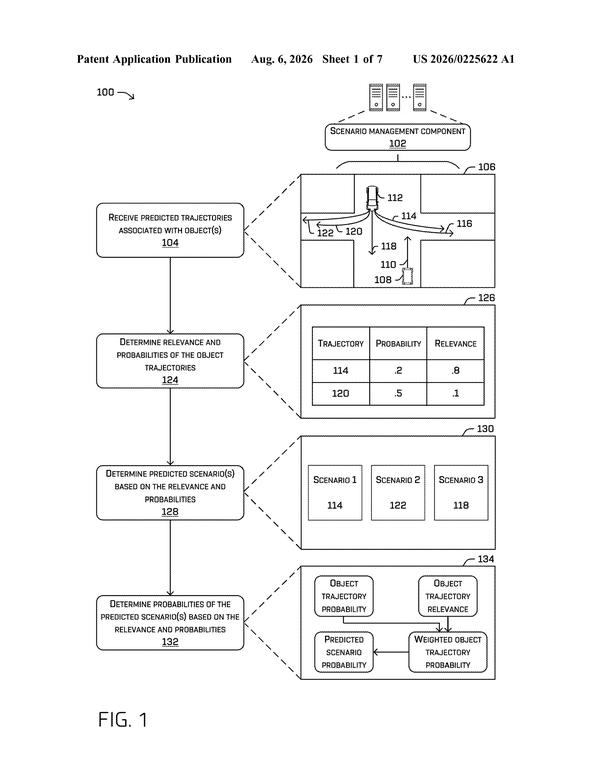
Predictive scoring of proposed moves before execution lets the system reject paths that lead to unsafe future states, adding a validation layer beyond the initial motion planner.
Detecting a hitched trailer rather than an obstacle eliminates false alarms when reversing, reducing nuisance alerts that could desensitize drivers to real collision warnings.
Measuring occlusion directly from camera input helps self-driving systems gauge confidence in object identification when road features or other vehicles are partially blocked from view.
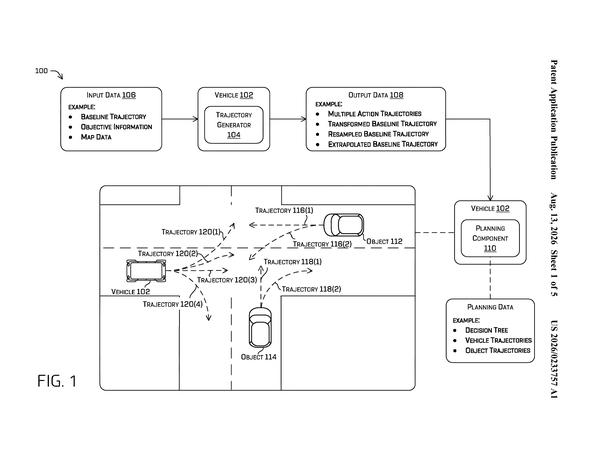
A decision tree that weights each possible path forward lets the system rank maneuvers by safety and feasibility rather than applying fixed rules, which matters most when traffic becomes unpredictable and the car must choose between competing valid options.
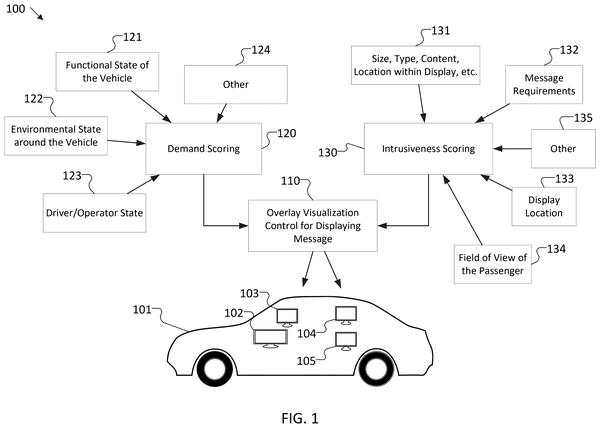
Queuing notifications based on vehicle state and driving conditions lets the display hold non-urgent messages until moments when driver attention isn't already committed to the road or weather.
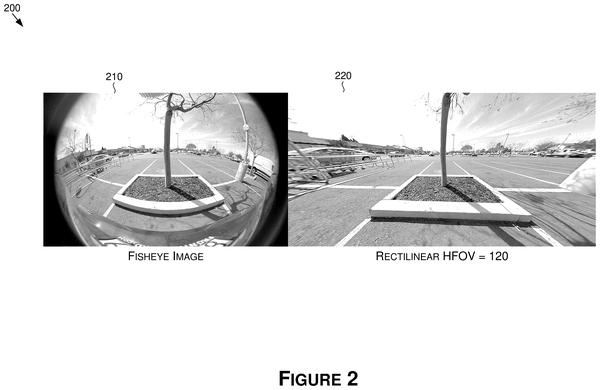
Automated distortion correction lets wide-angle cameras feed cleaner input to perception models, removing a preprocessing step that otherwise demands manual calibration across different camera placements on the vehicle.
A unified neural network predicts sensor inputs across the entire vehicle simultaneously, letting the car anticipate pedestrian and traffic movements rather than react to them after they occur.
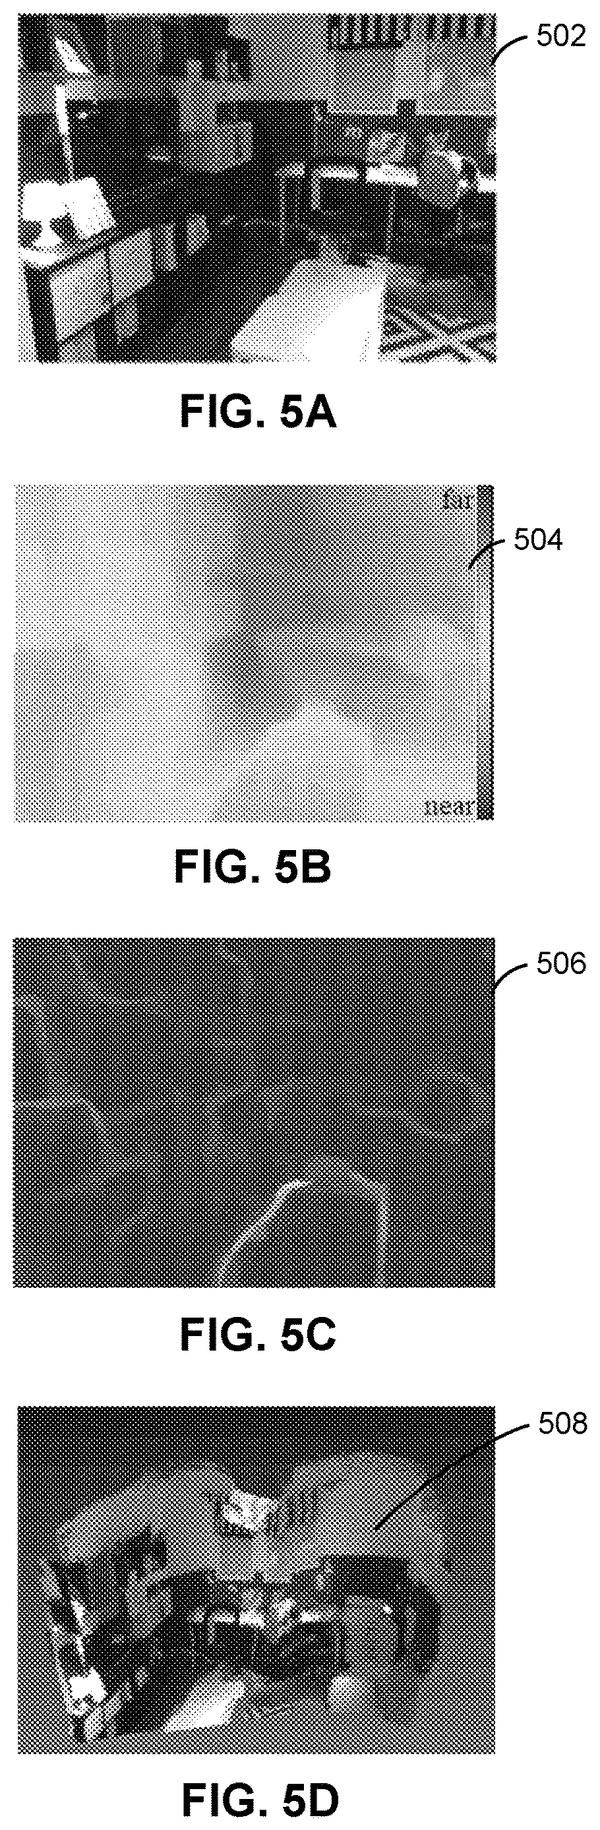
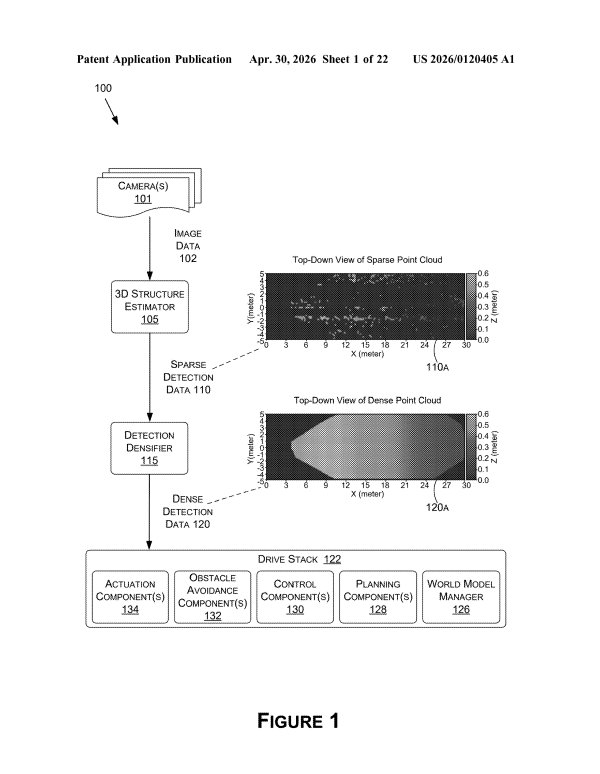
Fusing monocular and stereo depth estimates from standard video frames generates distance maps without specialized depth hardware, cutting costs for autonomous systems that need accurate 3D scene understanding.
Aligning reference frames before compression prevents the spatial mismatches that degrade 3D point cloud video quality, cutting the bandwidth needed to stream real-time sensor maps to autonomous vehicles.
Automatic alignment between depth and camera sensors eliminates the need for manual calibration targets, letting self-driving systems maintain sensor agreement in the field rather than relying on factory setup procedures.
Infrared light projection lets the cabin camera recalibrate itself without manual setup, reducing the drift that accumulates across different drivers and seating positions.
Where prediction meets prioritization: Sony's system ranks detected objects by collision risk rather than just distance, adding a severity layer to what competitors currently measure.
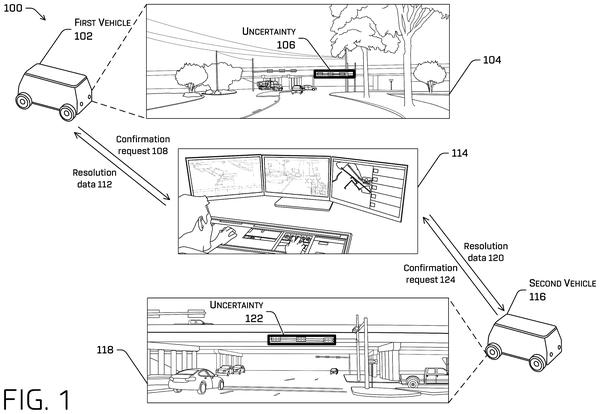
The fleet's communication gap: Zoox proposes sharing confusion signals between vehicles so trailing cars can anticipate road hazards that stumped the car ahead, rather than each robotaxi independently hitting the same problem.
Pairing camera and radar feeds through separate AI models lets each sensor compensate when the other fails, critical for reliably reading signs in rain, glare, or occlusion that would blind a single sensor approach.
The sensing stack already maps static geometry; this patent focuses on the dynamic problem of calculating approach geometry before entry, using only camera input.
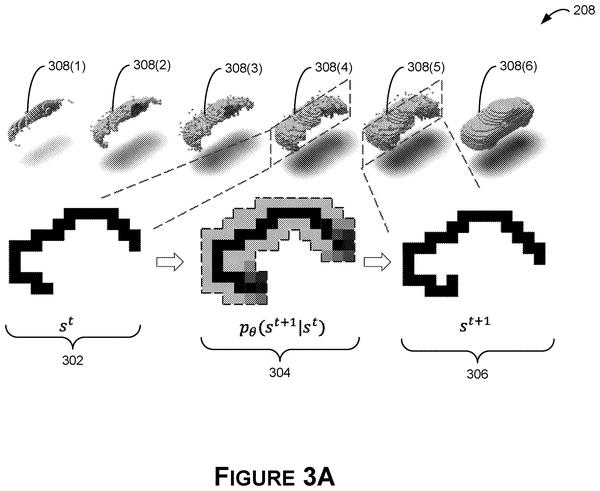
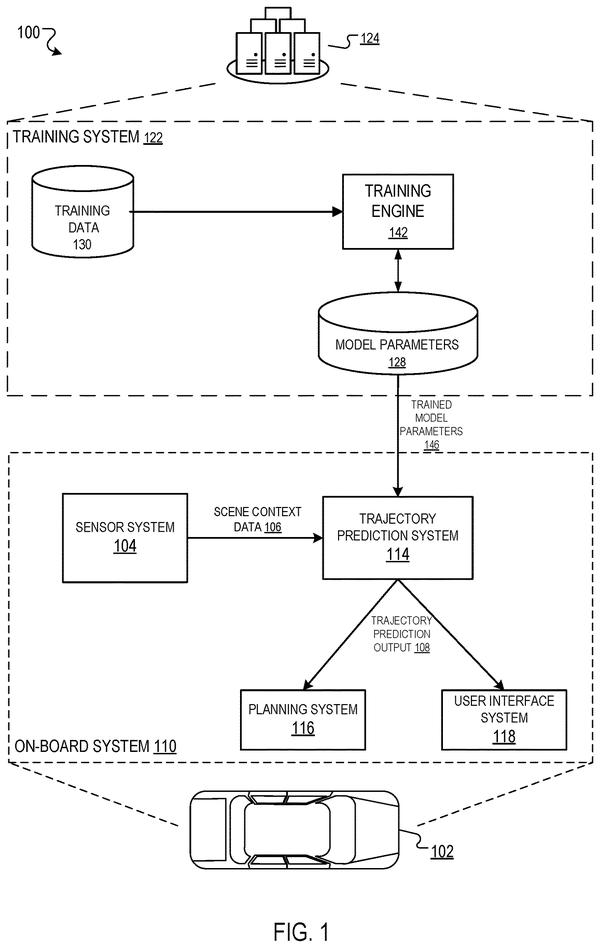
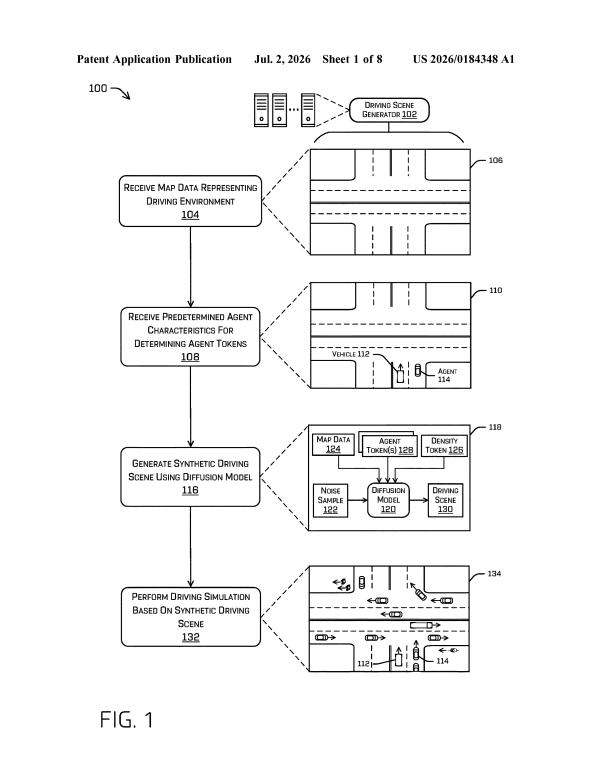
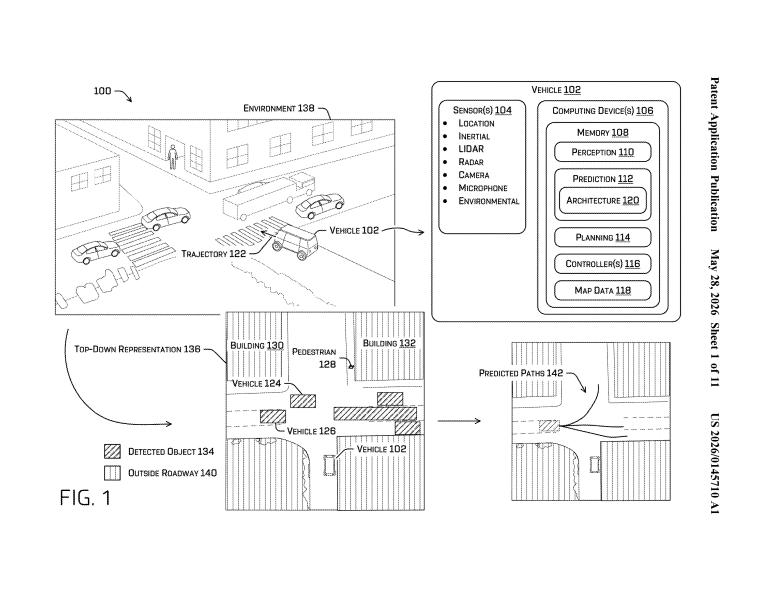
Predicting multiagent movement in dense traffic requires modeling dozens of actors at once. Waymo applies diffusion models, the same architecture behind image generation, to forecast trajectories of all nearby vehicles and pedestrians simultaneously.
Neural networks that infer depth from stereo camera pairs improve accuracy at occlusion boundaries, where one object blocks another, a common problem when pedestrians hide behind parked cars or other road obstacles.
A dual-model comparison lets the car score its own driving by measuring decisions against both normal traffic behavior and worst-case scenarios, filling a gap between safe outcomes and actually safe driving.
Waymo's approach to predicting hidden hazards moves past reactive sensing toward fused multi-sensor forecasting, letting the car simulate the next few seconds of road conditions before deciding when to brake or steer.
Decoupling path geometry from speed timing lets the planner adjust how fast the car moves along a fixed route without recalculating the whole trajectory, useful when obstacles or traffic suddenly change the safe speed but not the intended direction.
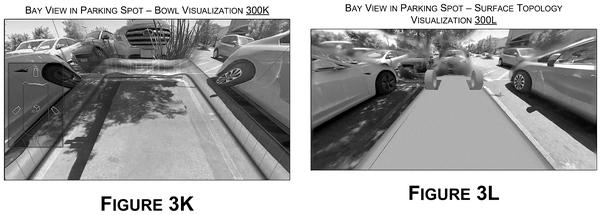
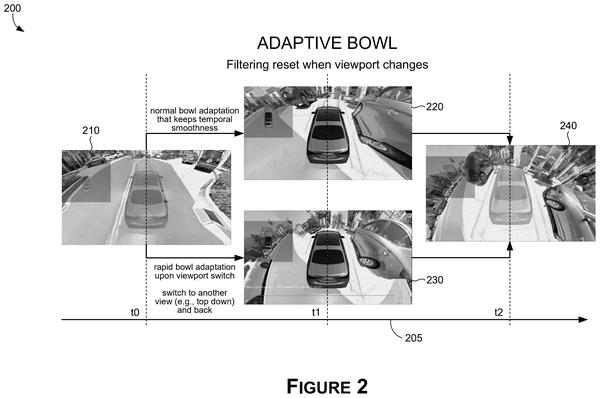
Adaptive camera projection switches between orthographic and perspective rendering based on scene geometry, keeping overhead parking views sharp whether the car sits on flat ground or uneven terrain.
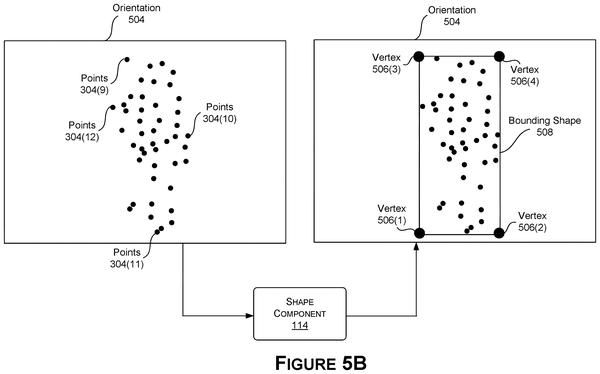
Rotating bounding boxes to minimize wasted space around detected objects reduces false positives from crowded scenes, letting the prediction models work with cleaner spatial data when multiple vehicles occupy the same frame.
Elevation profiles from maps let cameras resolve distance ambiguity when road grade obscures the horizon line, a recurring failure mode when cresting hills or navigating valleys where depth cues collapse in the image.
A neural network that reconstructs 3D intersection geometry from 2D camera images alone, replacing the need for lidar or pre-built maps to understand curb positions, crosswalk corners, and signal locations.
Calibrating alert sounds to match both object type and predicted trajectory lets the car communicate risk severity without requiring driver interpretation of raw sensor data.
Distributed sensor calibration lets autonomous vehicles correct drift by cross-checking readings with nearby cars in real time, avoiding service-bay downtime and keeping perception accuracy sharp across fleets.
Zoox's model predicts object trajectories pose-by-pose rather than guessing final positions outright, letting the car reason through each step of what's about to happen nearby.
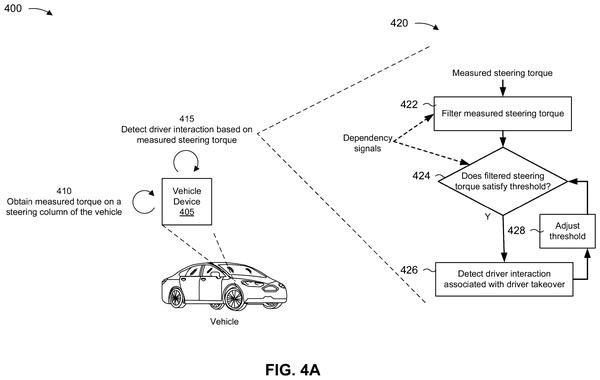
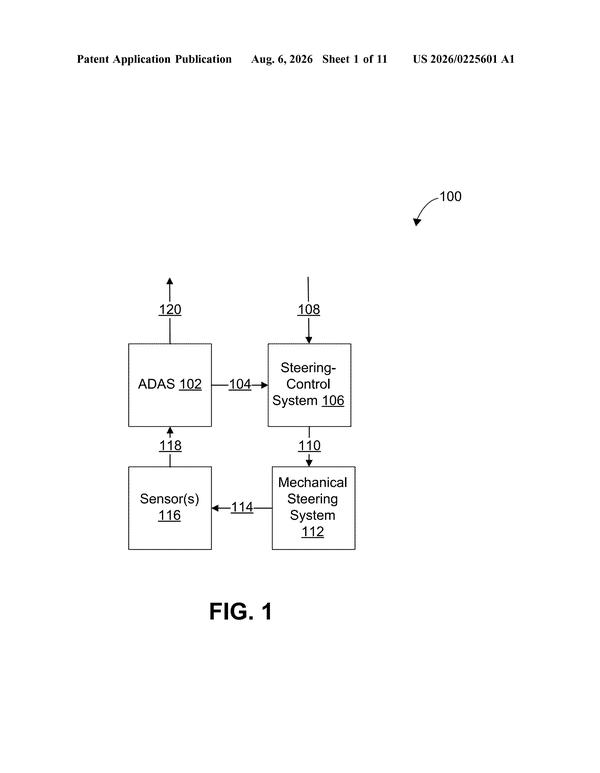
Measuring steering torque at handoff lets the car release control gradually rather than fighting the driver, smoothing transitions between autonomous and manual driving modes.
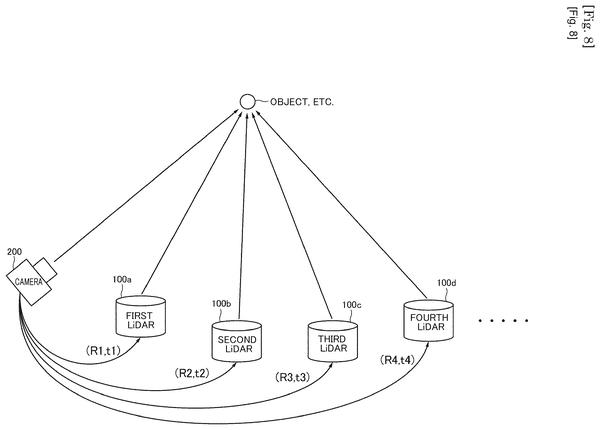
Validating camera and audio feeds against independent sensor readings flags mismatches that could indicate tampering or sensor failure, shoring up the data integrity that autonomous systems need to act safely on what they perceive.
The sensor processing challenge so far centers on speed versus accuracy in real-time segmentation. Sony's two-pass approach routes only uncertain regions through intensive analysis, preserving speed where confidence is high.
Real-time grip feedback from wheel slip lets Waymo cars detect ice patches mid-drive and choose safer road positions, extending the sensing race into surface conditions that fool camera and lidar alone.
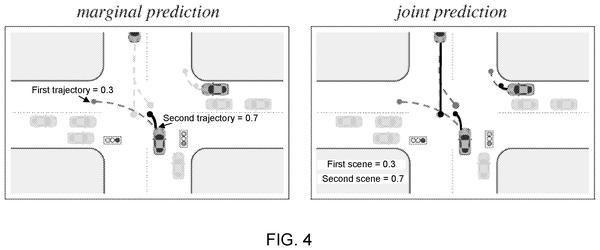
Waymo moves from predicting individual road users in isolation to modeling the full scene as interconnected agents, capturing how one person's move triggers reactions from others nearby.
A neural network that infers 3D object position and orientation from a single camera feed cuts the sensor redundancy autonomous vehicles need to build spatial maps.
A flexible 3D model that warps based on detected nearby objects solves the depth-judgment problem that plagues fixed surround-view displays, sharpening the car's ability to judge clearance during low-speed maneuvers.
A car that forgets parked obstacles between frames has a blind spot. Tesla's system keeps a persistent map of static objects in view, so the vehicle can track lane blockages and barriers even as camera angles shift.
Merging object detection and depth estimation into one inference pass cuts the latency overhead that forces self-driving systems to choose between fast recognition or accurate distance readings.
Modified image variants guide the network to isolate specific objects in a single pass, reducing reliance on massive labeled datasets for training segmentation models that distinguish road features from obstacles in variable lighting.
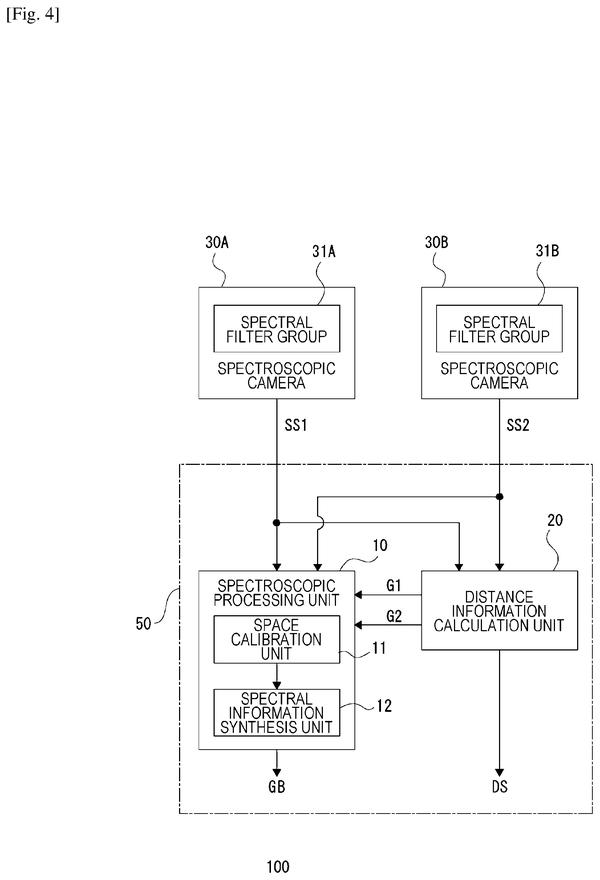
Sensor fusion has been the bottleneck: cameras and depth sensors often disagree on object location. Qualcomm's calibration method syncs the two streams to prevent detection failures from misalignment.
Self-driving cars need lane detection that fails safe, not confidently wrong. Nvidia's approach runs multiple detection systems in parallel and flags when they diverge, catching errors before the car steers into danger.
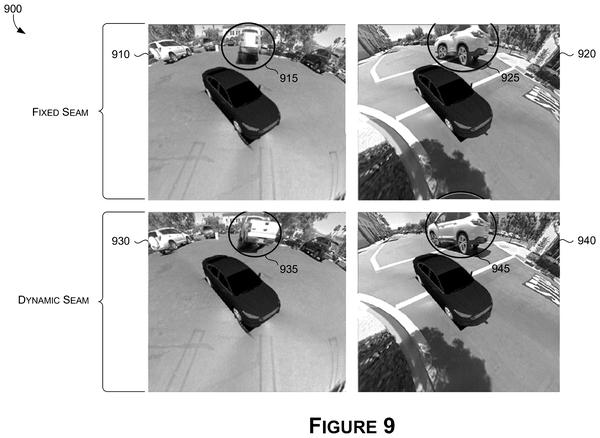
Your eyes make tiny involuntary jumps dozens of times per second, and Nvidia thinks that's the perfect moment to rearrange the seam in a stitched camera view before you notice anything changed.
Structured-light depth cameras struggle with motion blur in their distance readings. Sony's bidirectional scanning and averaging method could clean up that noise, sharpening 3D scene mapping for autonomous vehicles navigating dynamic environments.
Sensor fusion under heavy overlap cuts processing noise when multiple systems detect the same object simultaneously, letting the car build a unified scene map instead of parsing redundant alerts.
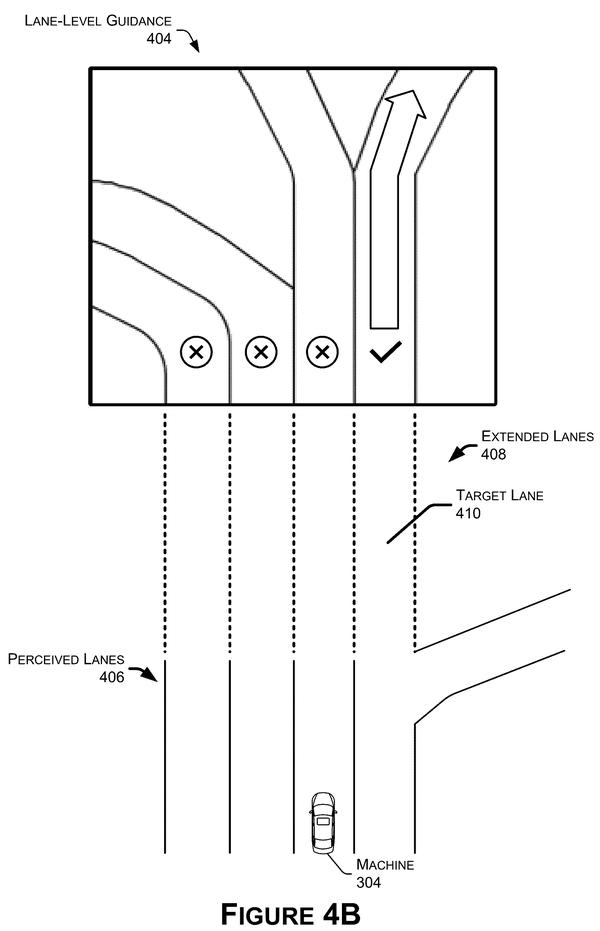
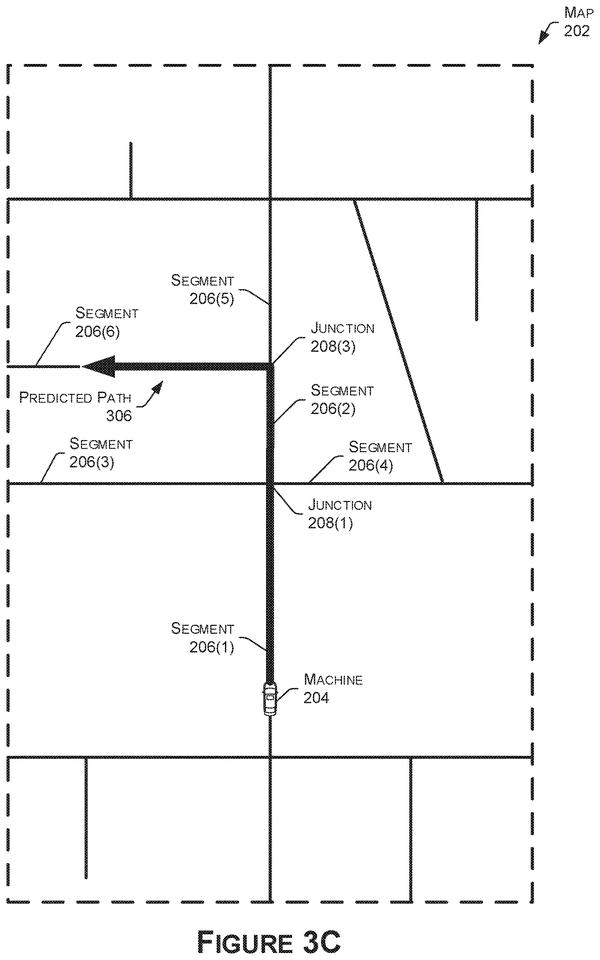
Lane selection during routing remains unsolved in most systems. Zoox's color-coded map translates destination requests into real-time lane commitment signals, bridging the gap between high-level navigation and moment-to-moment driving decisions.
Most self-driving systems pick one approach and commit to it. Nvidia's new patent describes a system that runs two different planning methods side by side and picks the better answer every single time.
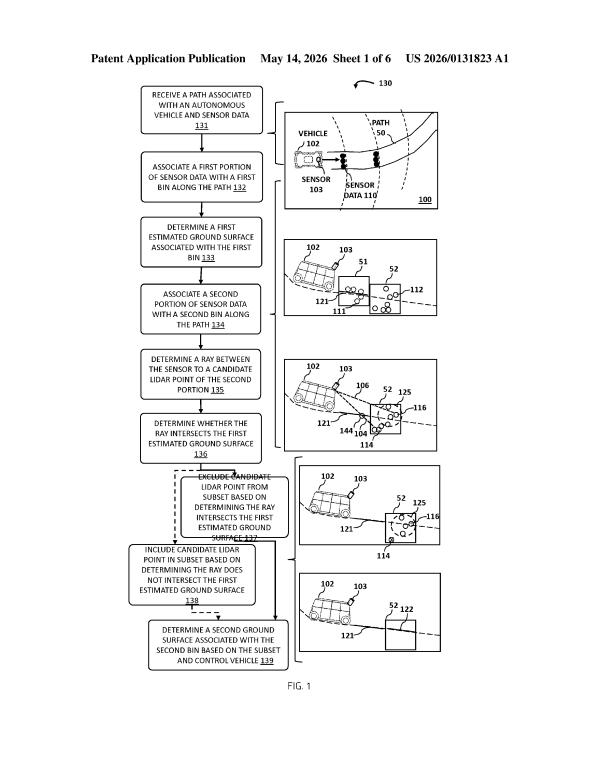
Filtering LIDAR output in real time cuts the computational load: Waymo's system drops irrelevant data points before they reach the processing pipeline, letting the car focus compute on what actually matters for driving decisions.
Predicting where a car should actually drive within a lane requires real vehicle trajectories, not just map boundaries. Mobileye's method reconstructs safe driving corridors from historical path data.
Predictive downshifting based on road geometry and grade ahead lets the transmission prepare before load spikes, smoothing acceleration and deceleration without the jerky hesitation that signals an unprepared vehicle.
Radar and camera have always fed separate AI pipelines; this patent merges them upstream so the model learns from unified sensor data rather than reconciling two partial views.
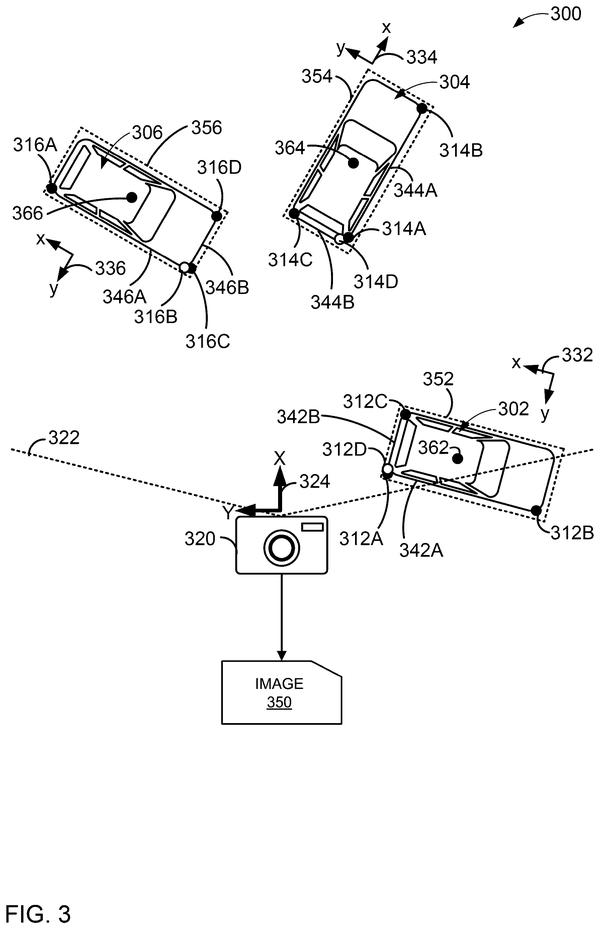
Detecting object corners directly rather than inferring orientation first removes a failure point when vehicles or pedestrians appear at odd angles to the camera, sharpening bounding boxes that downstream prediction models depend on.
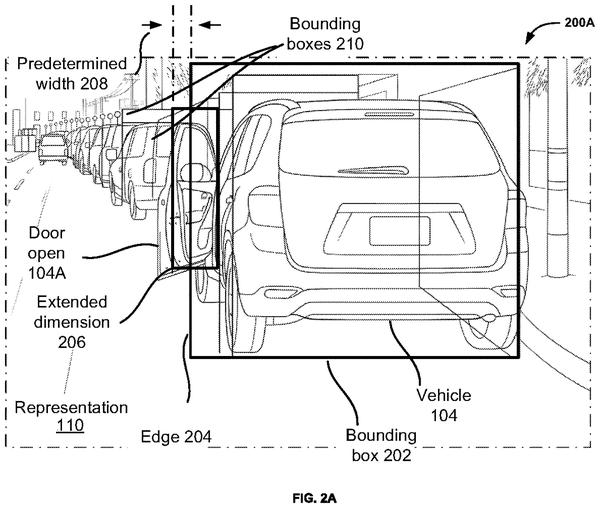
Neural networks that flag opening car doors in real-time video feed address a collision hazard that occurs faster than typical obstacle detection cycles, requiring the system to predict door movement before contact.
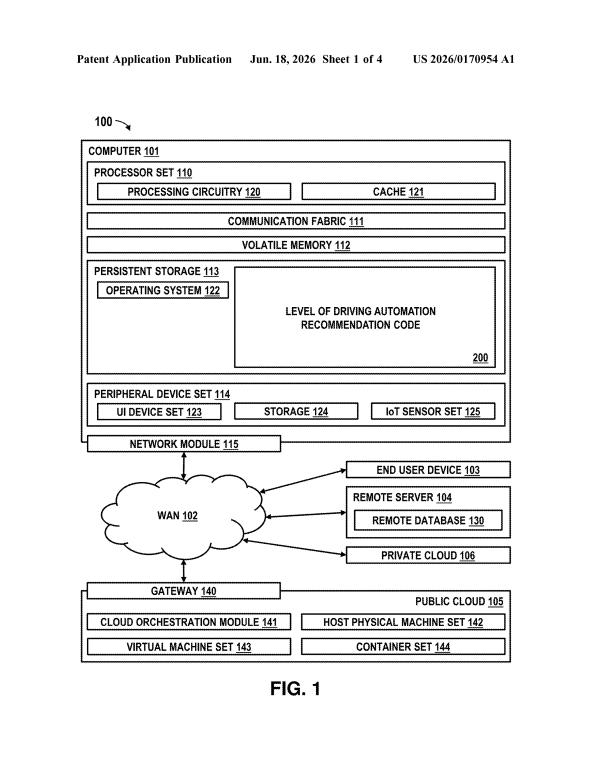
A chip-level system that pre-scans the full route and flags sections too complex for autonomous operation, letting drivers plan handoffs instead of facing surprise disengagements mid-trip.
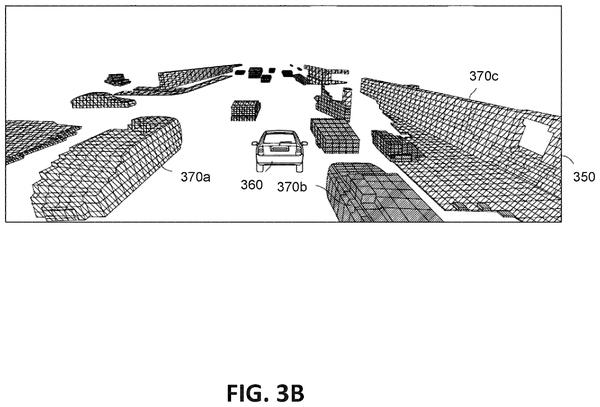
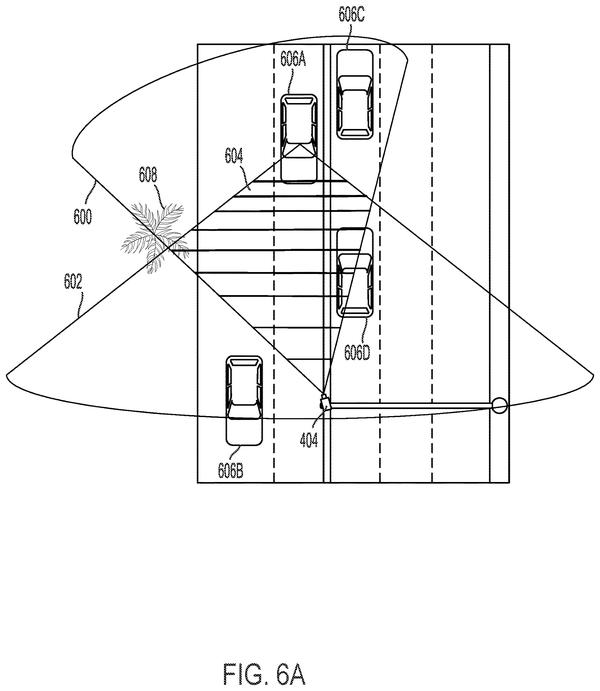
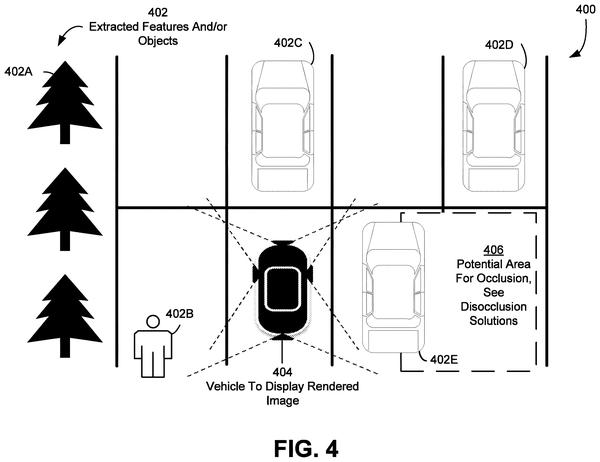
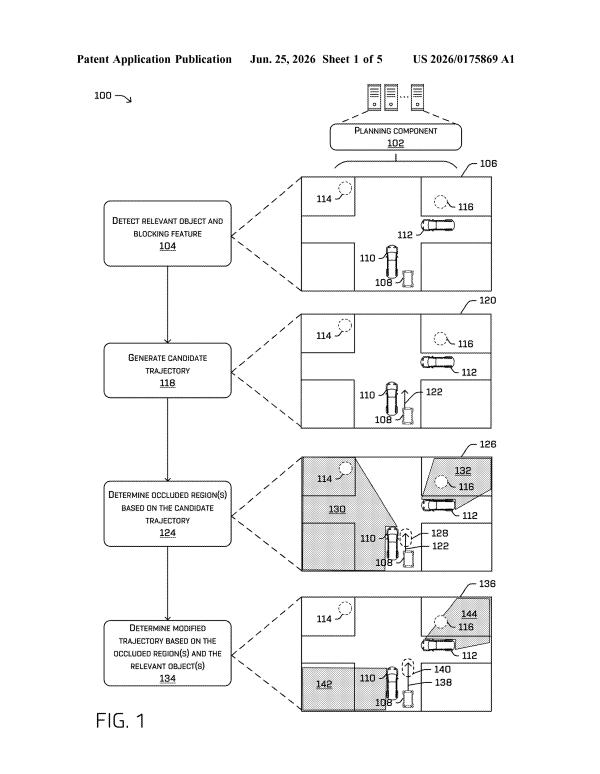
Modeling occluded zones in real time lets vehicles predict hazards behind parked vehicles and other obstacles without waiting for a clear line of sight, compressing the cautious inching-forward that human drivers do into millisecond-scale planning.
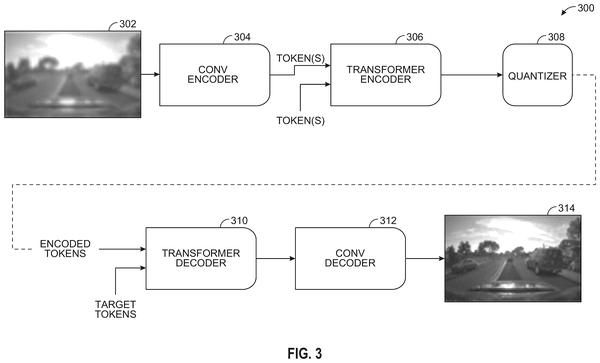
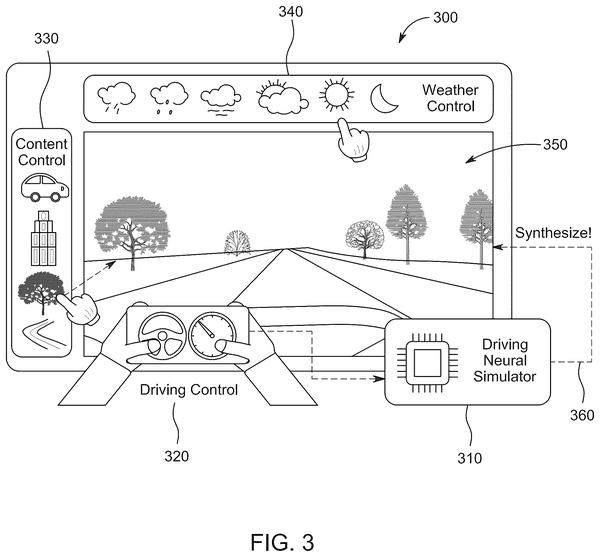
Training AI in the real world is expensive and slow. Nvidia's new patent describes a system where neural networks generate entire simulated environments on the fly, pulling from stored knowledge about the objects inside them.
Waymo and Nvidia both need to filter sensor noise before their models can react. Qualcomm's approach ranks objects by collision risk to allocate compute where it counts most.
Self-driving cars equipped with both cameras and radar could train faster if one sensor's labeled data automatically syncs to the other, cutting the manual work that currently slows down AI development.
The sensors need precise calibration to map roads accurately. This patent shows cameras syncing position data with nearby vehicles to self-correct their angles, bypassing manual setup.
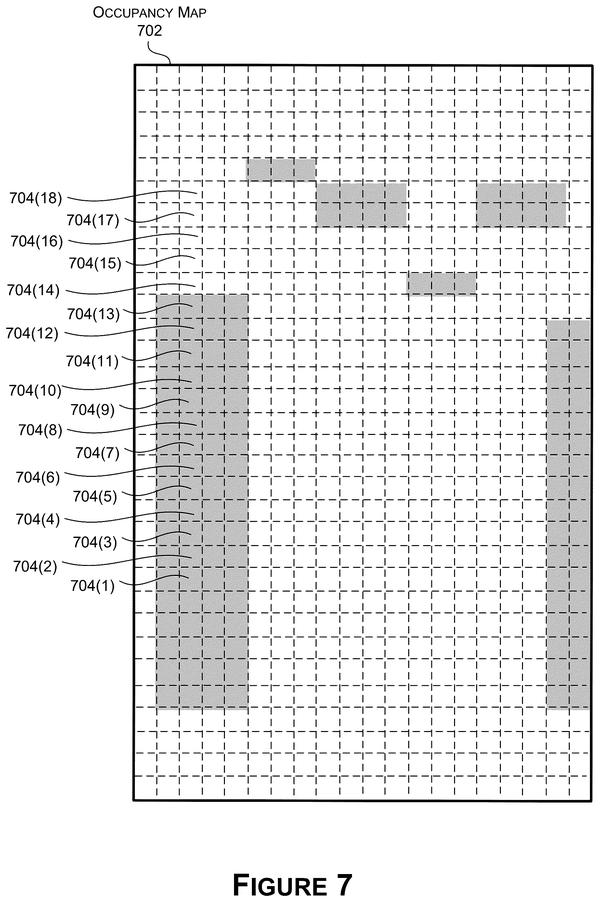
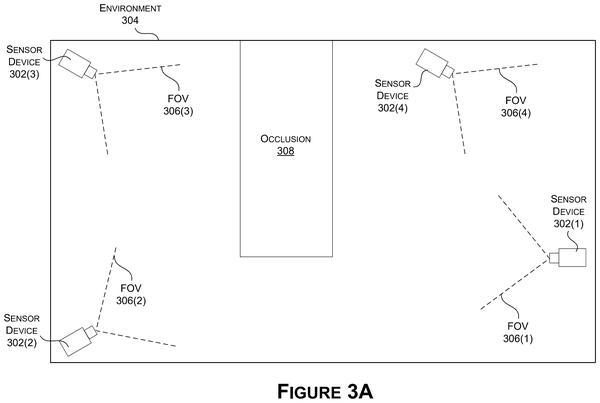
Tracking which areas sensors cannot penetrate lets the vehicle treat blocked zones as active hazards rather than unknowns, forcing explicit safety protocols around parked cars and intersection corners where pedestrians might be hidden.
Self-driving cars need accurate speed readings from radar to brake in time. Zoox's fix catches and corrects garbled speed measurements before the car acts on them.
Predicting collisions before they happen requires knowing where every actor on the road will be seconds ahead. Waymo's system generates forward trajectories for the car and all nearby objects to find conflicts early.
Self-driving stacks need simulation coverage that won't leave dangerous blind spots. Nvidia's system auto-generates missing test cases instead of relying on manual scenario building.
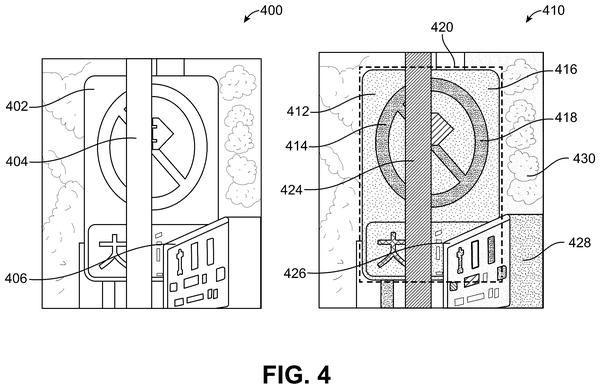
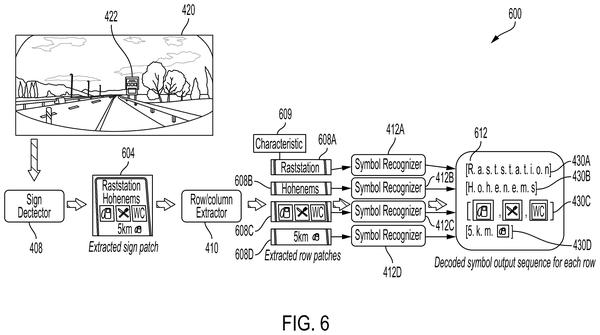
Self-driving cars need to parse cluttered road signs fast and accurately. Qualcomm's system breaks signs into individual symbols and sequences them correctly, solving a key step between raw camera input and actionable driving commands.
Longer detection range means more time to plan maneuvers, and Qualcomm's approach solves the degradation problem by retraining the AI rather than upgrading sensors, keeping costs down while extending how far ahead the car can identify obstacles.
Routing logic gets validated by a language model before execution, adding a verification layer between path planning and motion control that catches inconsistencies the initial planner might miss.
Self-driving cars need sensors to alert the central computer instantly when danger appears. Tesla's patent lets a sensor bypass the normal data queue and broadcast at higher power, so urgent warnings reach the car's brain without delay.
Fusing 3D and camera data in a single neural network cuts the computing load that normally comes from running separate perception pipelines, letting the car catch details both sensors provide without duplication.
Teleoperator control interfaces shift from screen-based inputs to gestural commands mapped onto 3D vehicle environments, reducing latency between human intention and autonomous response.
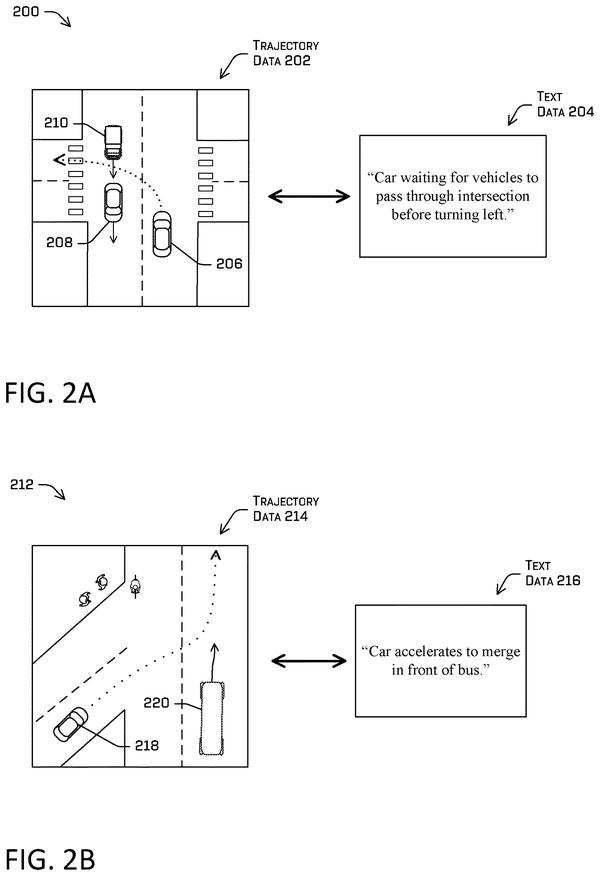
Self-driving cars need to predict what other road users will do next. Zoox's system learns to recognize behavior patterns from human descriptions, letting the car build a library of real-world driving and walking styles to anticipate.
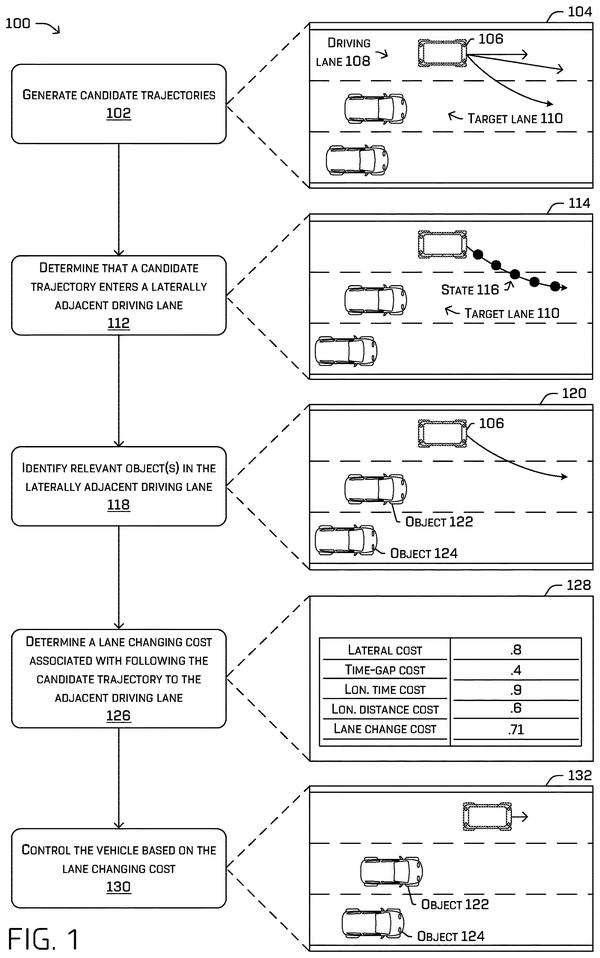
Self-driving cars that merge without spooking other drivers need to weigh how much each lane change would slow or stress nearby traffic. Zoox's cost-scoring system lets robotaxis pick moves that feel least disruptive to whoever's behind them.
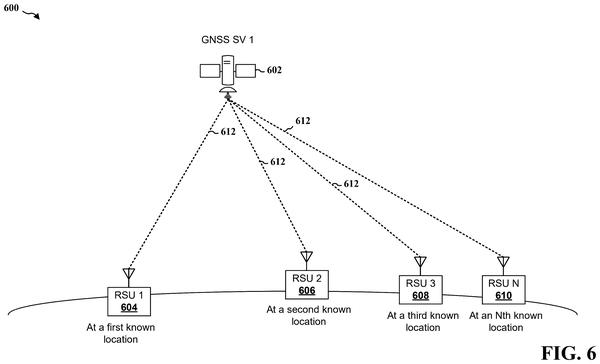
Self-driving cars need GPS they can trust. Qualcomm's dual-receiver approach lets the system catch and reject confident but false position fixes before they corrupt the driving model.
Sensor drift during operation can throw off object detection. Nvidia's approach uses detected objects themselves as calibration anchors, eliminating the need for stationary targets or technician intervention in the field.
Tracking objects as they move between camera views requires each sensor to build context from scratch. Nvidia's approach lets cameras share learned features about tracked objects, cutting the perception gap at handoffs.
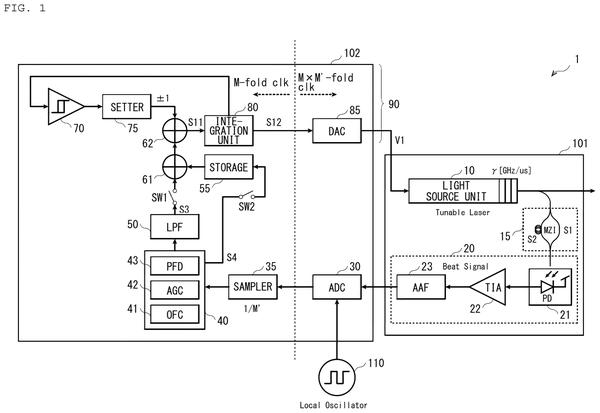
Built-in clock calibration keeps LiDAR distance measurements from degrading as the sensor operates, directly sharpening the real-time environment maps that guide lane changes and obstacle avoidance.
Waymo and Nvidia both need radar to measure closing speed on nearby objects. Nvidia's approach fuses incomplete sensor snapshots to estimate velocity in real time.
The sensor fusion problem has centered on getting cameras and lidar to agree on relative position; Sony's approach adds a third sensor as calibration arbiter, eliminating manual tuning.
Lidar reflection signatures can reveal road surface conditions like ice or wet pavement in real time, letting the car adjust grip assumptions without adding sensors or relying on weather data.
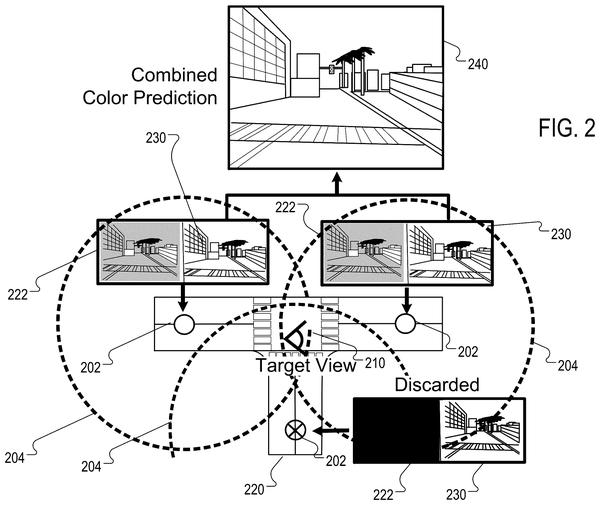
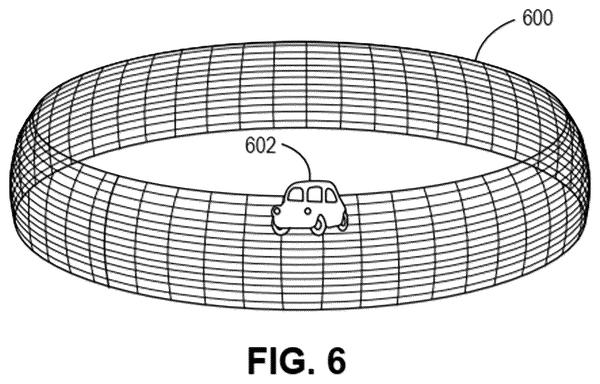
Converting angled camera feeds into a unified overhead map lets the AI reason about object positions without relying on separate depth estimates from each camera angle.
Neural networks trained to infer hidden object geometry improve localization accuracy when pedestrians or obstacles are partially blocked from view, sharpening predictions about what lies beyond a self-driving car's direct line of sight.
A two-stage neural network design splits object detection into separate passes, letting one network focus on localization while the other handles classification, reducing the computational load of processing 360-degree sensor feeds in real time.
Self-driving cars need to recognize pedestrians and obstacles in every lighting condition and weather. Reducing the labeled training data required means faster iteration on detection models across diverse real-world driving scenarios.
Distinguishing shoulder obstacles from actual path hazards requires mapping the car's predicted trajectory against detected objects, not just proximity alone.
Sensor efficiency under variable conditions: Sony's system adapts signal repetition per frequency based on real-time data quality, rather than firing fixed counts across all bands.
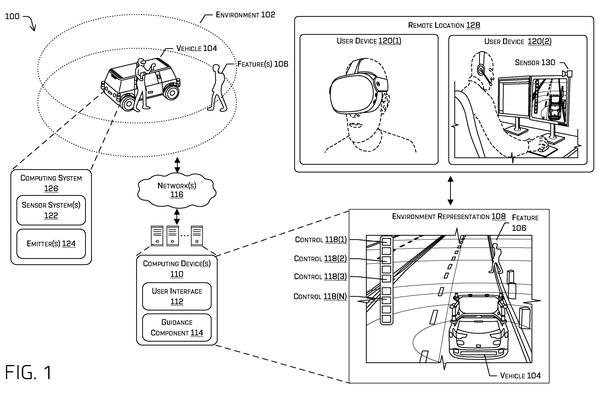
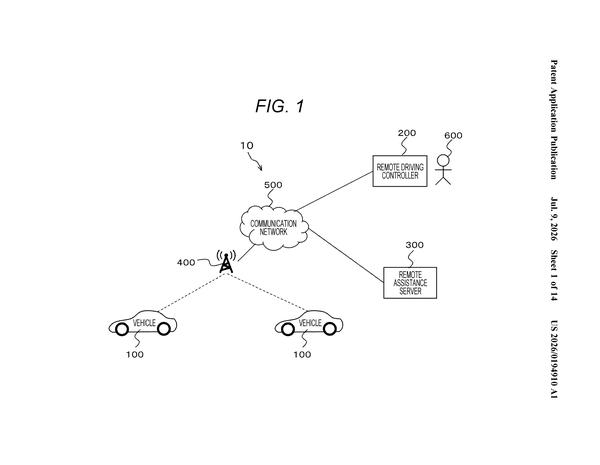
Handling edge cases that stump autonomous systems: remote operator takeover via VR lets a human intervene when the car encounters situations outside its trained model, keeping vehicles moving rather than defaulting to safe stops.
Predicting physical changes to mapped environments from historical data lets autonomous systems refresh 3D maps without repeated field rescans, addressing the gap between static sensor captures and real-world drift in road layouts and obstacles.
Building overhead maps from multiple camera and lidar feeds requires reconciling misaligned data from different sensor angles and timing. Qualcomm applies 3D rendering techniques to sharpen those composite maps and fill gaps where sensors can't see directly.
A car that loses sensor data or processing power mid-drive needs to know instantly which functions survive the failure. Nvidia's system pre-ranks critical features so the computer doesn't have to choose during the crisis.
Stale pre-built maps force most self-driving systems to rely on outdated road data. Zoox's approach generates fresh maps continuously from onboard sensors and machine learning, eliminating the lag between map creation and deployment.
Panoramic pre-scans of planned routes let cars build a forward map of road conditions and signs before they arrive, extending the reaction window beyond what live sensors alone can detect.
Predicting human reaction time in traffic: Waymo maps the delay between when drivers notice hazards and when they act, filling a gap where collisions occur.
Depth perception and object detection become parallel processes rather than sequential ones, letting the AI build a unified scene model from a single camera instead of requiring multiple sensors to cross-reference.
Decoupling lighting from road layout lets simulators generate training data for conditions that rarely occur naturally, multiplying the scenarios a model can learn from without collecting new footage.
Depth sensing across multiple ranges has required tradeoffs between near and far focus. Sony's dual-section sensor splits the workload, letting one half handle close objects while the other captures distant ones simultaneously.
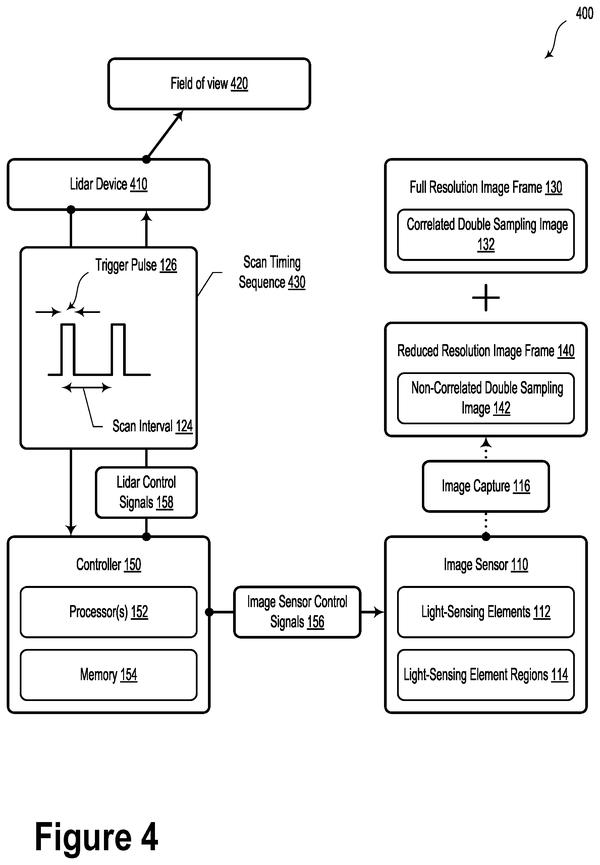
Low-light visibility requires cameras to choose between detail and speed. Waymo syncs dual-exposure captures to LiDAR pulses, grabbing both high-res and fast-readout frames in one cycle to hold sharp road detail even in near-darkness.
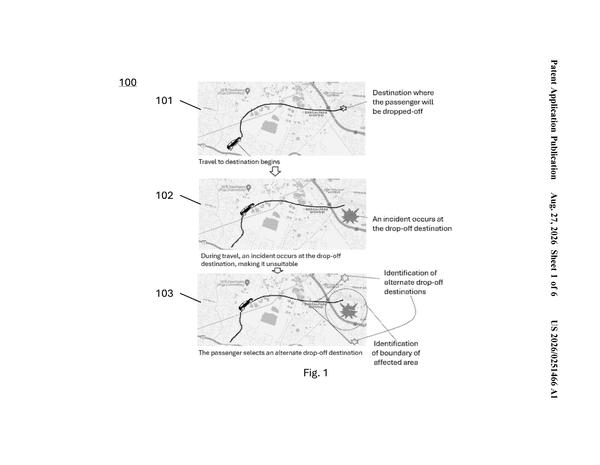
Self-driving cars that refuse unsafe drop-off zones would need real-time assessment of street conditions, weather, and crowd density. IBM's system automates that judgment call rather than leaving it to the passenger's choice or a remote operator.
Filtering out false obstacles like manhole covers reduces unnecessary braking events that can confuse following traffic and degrade passenger experience on city streets.
Self-driving cars need crisp 3D maps to navigate safely, not blurry approximations. Qualcomm's approach fills in missing details by matching rough map objects to a database of real-world shapes, sharpening the sensor data that guides driving decisions.
Self-driving cars need their safety systems running even when one module fails. Nvidia's method isolates restarts so critical functions like steering and braking keep working while a crashed component reboots.
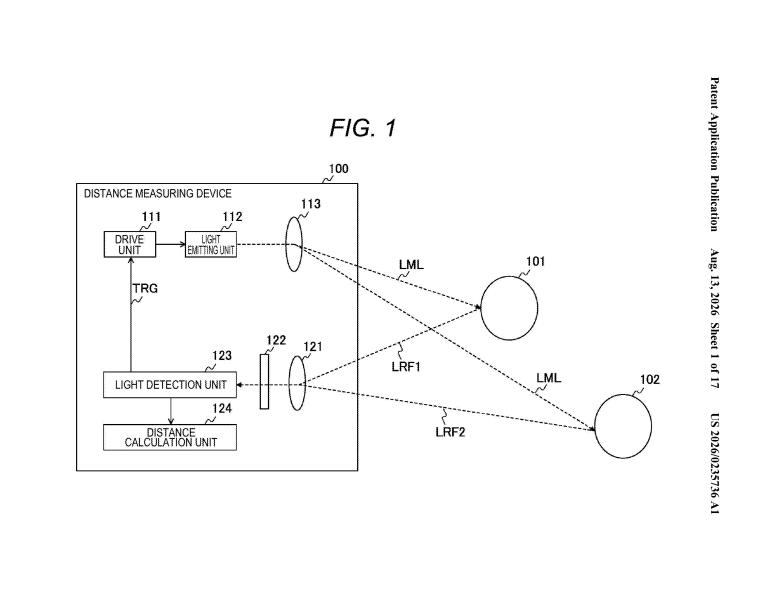
Self-driving cars need lidar working even when sunlight or reflective surfaces flood the sensor. Sony's method restores detection speed after these blinding moments, keeping distance measurements reliable in high-glare conditions.
Self-driving systems need to know when their sensors are compromised. Sony's chip-level degradation detection lets cameras flag themselves before mud or damage silently breaks pedestrian detection or road mapping.
A remote human operator can step in the moment any sensor fails, working from live feeds of the car's remaining vision. This addresses a gap in how autonomous systems handle partial blindness on real roads.
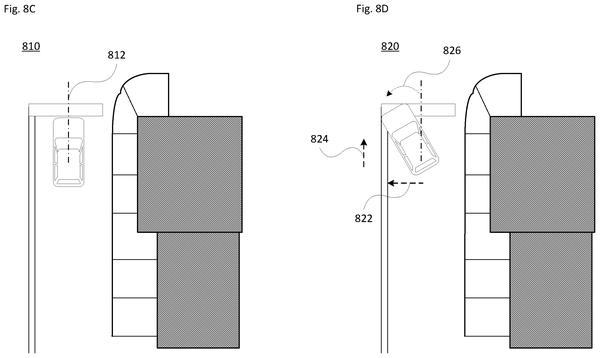
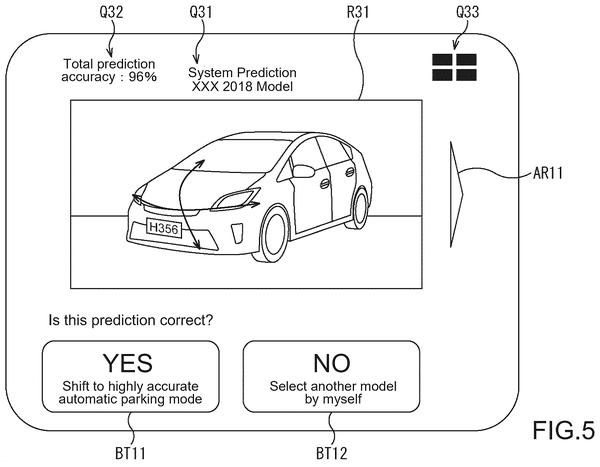
Parallel parking next to a giant SUV when you're driving a compact is genuinely nerve-wracking. Sony's semiconductor arm has filed a patent for a system that simulates the entire parking maneuver before you attempt it, using a live 3D scan of the cars already in the space.
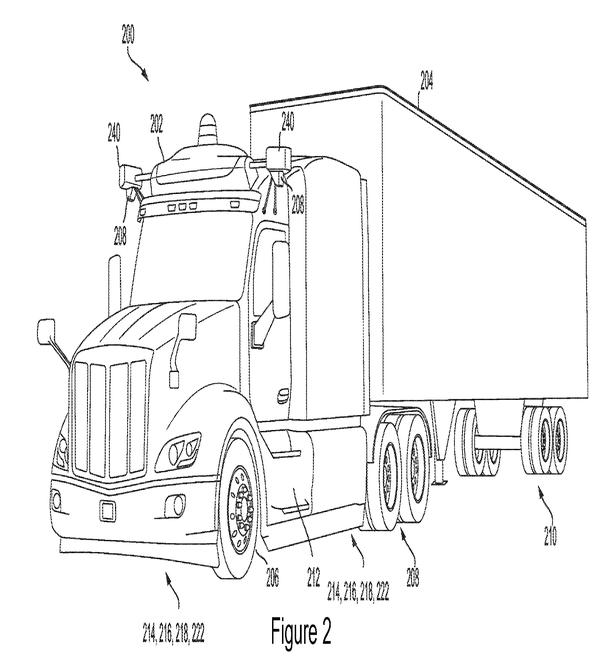
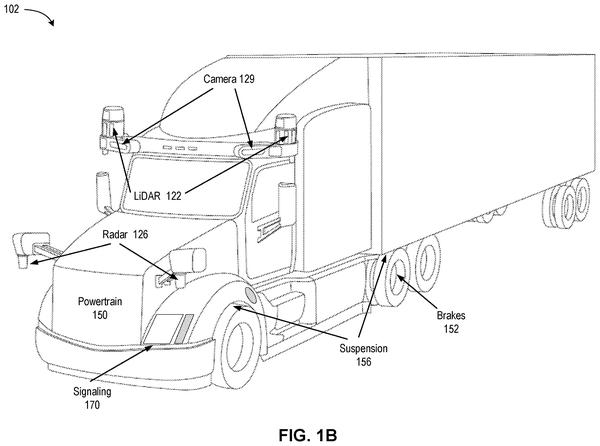
A third independent brake controller ensures the truck can stop even if two fail, replacing driver intervention with redundant hardware paths that self-driving freight cannot afford to lose.
Layering LiDAR and camera data to detect road surface conditions like wet patches and potholes fills a gap between obstacle detection and the granular hazard mapping needed for safe trajectory planning.
Camera timing skew has plagued the perception pipeline; Qualcomm's approach detects and corrects misalignment automatically rather than requiring manual calibration between sensors.
Time-of-Flight sensors bounce infrared off reflective surfaces to measure depth, but glass lets light pass through instead of bouncing back, creating a phantom gap where obstacles exist. Sony's method detects this signature failure mode.
A neural network that identifies intersection boundaries and road patches in real time from camera feeds, letting the car map crossing zones without pre-built maps and determine safe passage during simultaneous arrivals.
A degradation model for each sensor lets the car measure how much rain or fog is blocking its view, then adjust speed and following distance rather than assume normal visibility.
Waymo's filing creates camera angles that were never filmed from existing footage, so the fleet can learn from new viewpoints without driving the same routes again.
Measuring how far objects jut into traffic lanes, not just detecting them, fills a gap between recognizing a parked truck and knowing whether its open doors actually block your path.
Organizing sensor readings into time buckets lets Nvidia detect clock drift across multiple cameras and radar units without heavy computation, a common failure point when self-driving systems fuse data from misaligned timestamps.
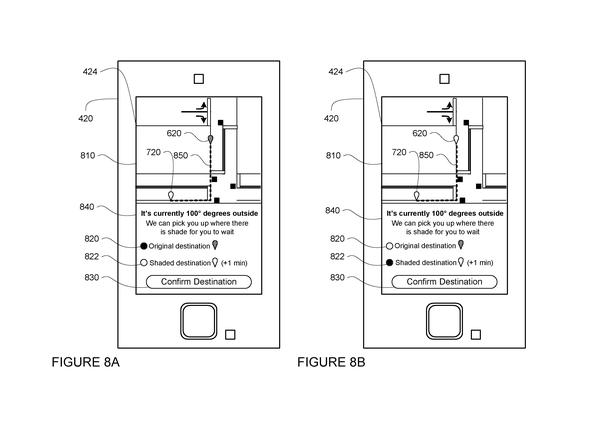
Nobody wants to step out of a self-driving car into a downpour. Waymo is patenting a system that reroutes you to a better drop-off spot when the weather at your original destination is miserable.
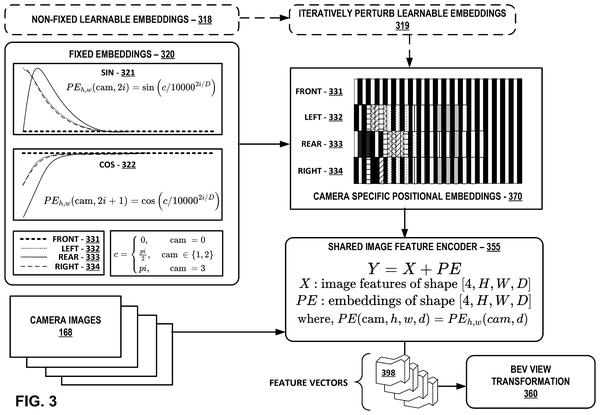
Merging six camera feeds into one scene map requires the AI to know which physical camera each image comes from. Qualcomm's approach trains one encoder to handle all feeds while tracking source camera identity.
Distinguishing moving objects from stationary debris requires temporal context that single frames can't provide. Nvidia's approach fuses sequential camera data so the car's AI can separate a accelerating cyclist from wind-blown trash.
Sensor degradation in bad weather demands active recalibration. Waymo's system detects when rain or fog is corrupting readings and shrinks the field of view to maintain detection reliability rather than relying on degraded data across a wider area.
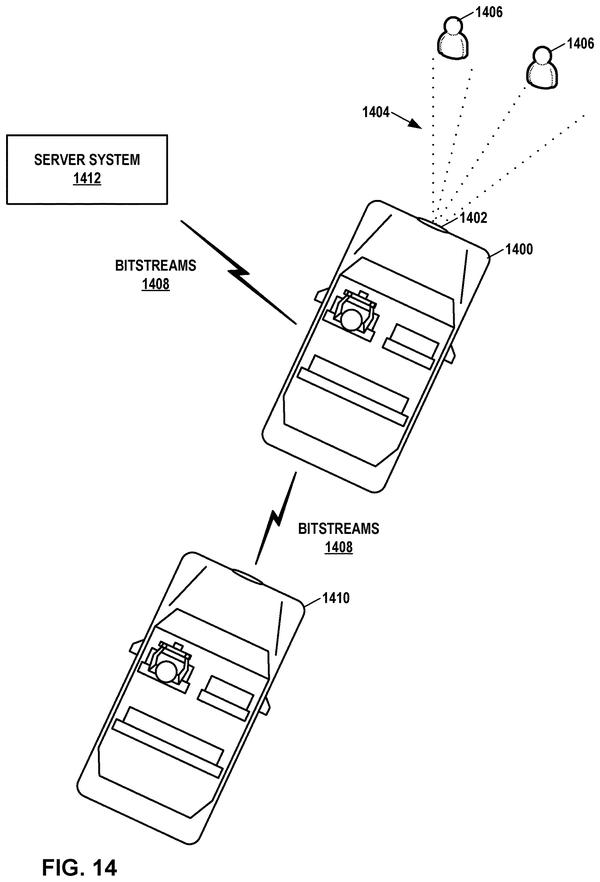
Self-driving cars need to predict hazards beyond their sensor range. This patent lets vehicles request live camera feeds from nearby cars or roadside posts, effectively extending their perception field to spots their own hardware physically cannot reach.
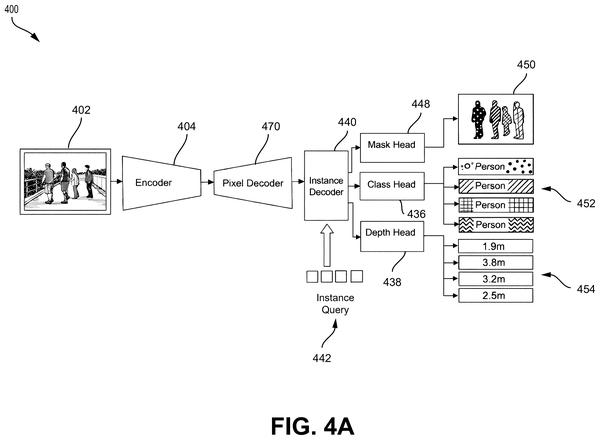
Self-driving cars need pixel-perfect segmentation maps to distinguish road from shoulder from parked cars. Nvidia's method generates those maps without manual annotation, removing a major constraint on how fast teams can retrain their vision models.
Self-driving cars need to separate a pedestrian from a wall behind it. Sony's chip runs two measurement modes in sequence, resolving which reflection came from which object.
Mapping road features lets self-driving cars pinpoint each other's location without relying on GPS signals, solving the coordination problem when multiple autonomous vehicles operate in the same space.
Self-driving cars need depth maps that stay sharp in color-rich scenes. Sony's dual-sensor approach lets cameras measure distance without dimming the wavelength data needed to identify road signs, lane markings, and pedestrians by sight.
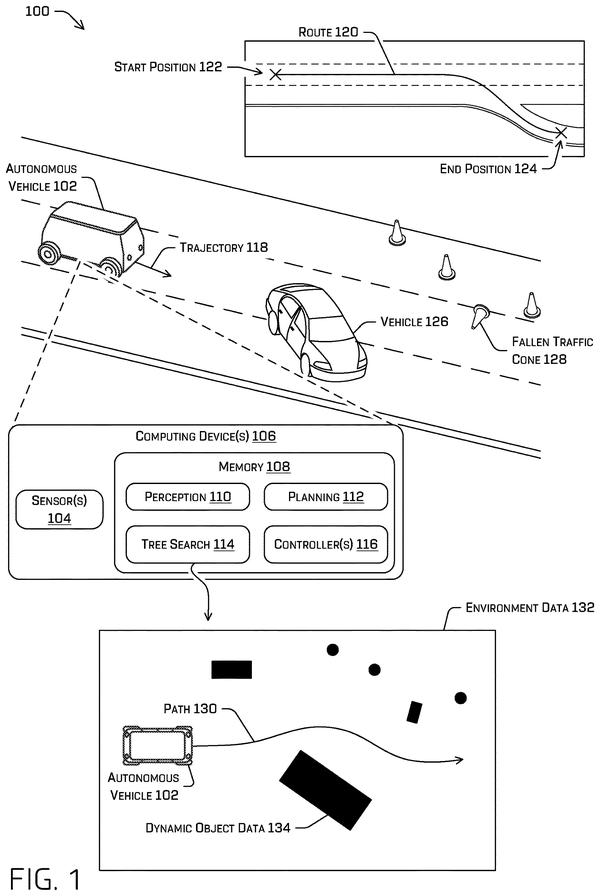
Predicting hidden pedestrians requires the car to simulate multiple escape routes in real time. Zoox's branching search system lets the vehicle evaluate which evasive maneuver minimizes collision risk before committing to one.
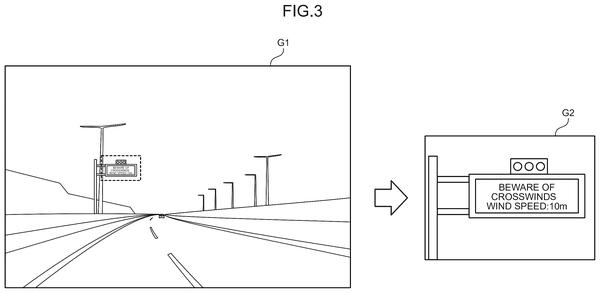
Self-driving systems need to know what signs said, not just that they exist. Sony's approach logs sign data after the car passes, solving the timing problem that makes real-time alerts useless at highway speeds.
Detecting sensor degradation in real time prevents a self-driving car from operating blind in fog, rain, or dust without realizing its vision has failed. Waymo's system compares expected versus actual sensor output to catch gradual performance loss.
Temporal gaze patterns catch driver inattention that single-frame detection misses, adding a monitoring layer that flags sustained distraction rather than momentary glances.
Filtering sensor streams by predicted driving path lets the system process high-resolution data from relevant areas while downsampling peripheral zones, reducing the computational load that limits real-time perception on embedded hardware.
Mapping relies on databases of known markings, but this method lets cars decode unfamiliar road symbols directly from visual input, filling a gap when markings don't match pre-loaded data.
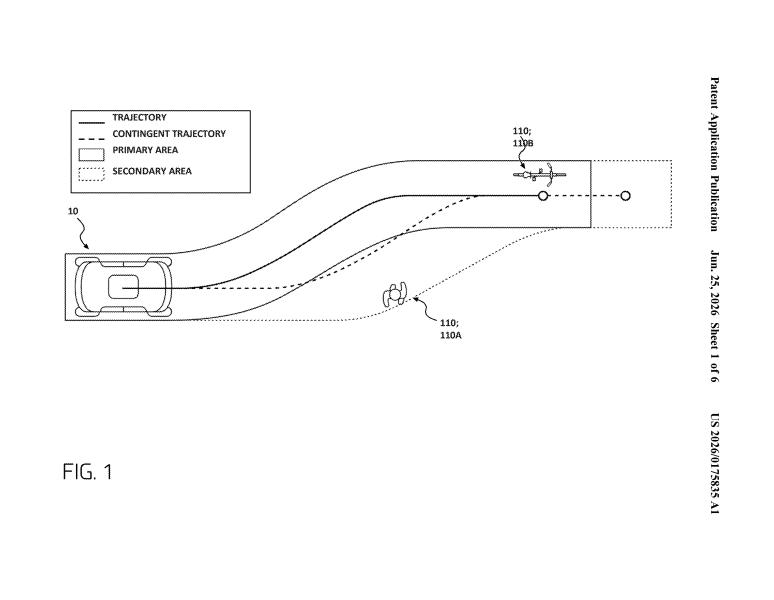
Modeling the geometry of partially blocked lanes lets the car compute safe crossing angles without requiring a full lane change, solving a common urban chokepoint where human drivers constantly negotiate space.
Mapping fixed structures like concrete pillars against stored layouts solves the GPS blackout problem in garages, letting self-driving systems maintain position accuracy where radio signals fail.
Predicting hidden pedestrians requires knowing which vehicles won't swerve into your path. Zoox's system filters out low-probability threats so the car can focus computation on genuinely dangerous nearby objects.
Self-driving cars need fast, reliable localization to navigate safely, and this filing shows how coarse-to-fine landmark detection can speed up the visual recognition bottleneck that currently limits real-time positioning accuracy.
Switching between multiple LiDAR sensors based on real-time driving conditions lets cars rely on whichever laser configuration handles fog, glare, or darkness best.
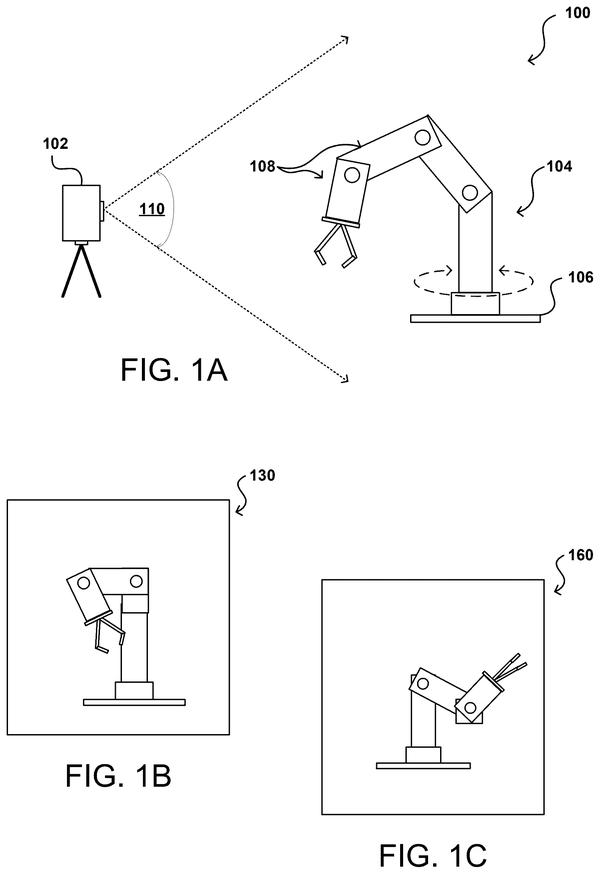
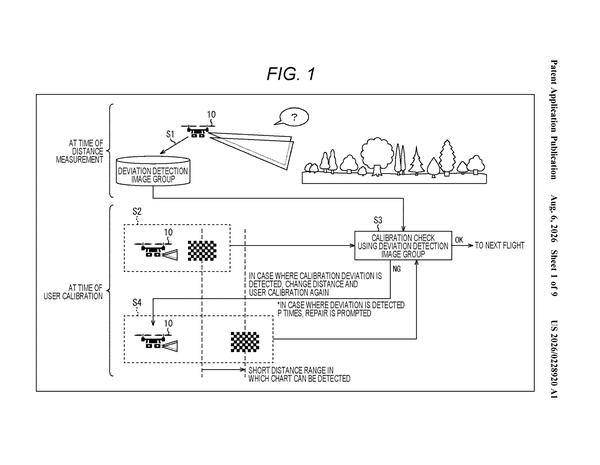
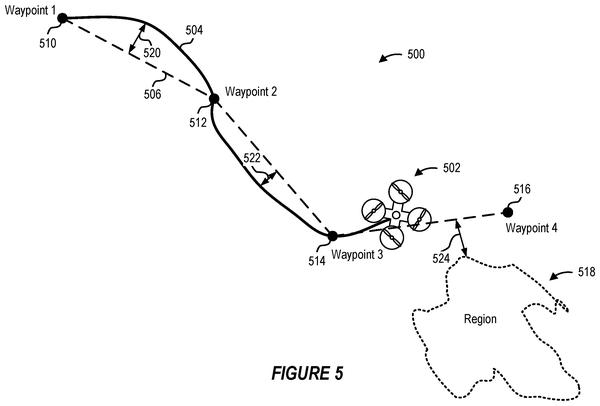
Stereo cameras that drift out of alignment during flight can now self-correct by pairing blurry frames with sharp ones from the same moment, keeping the 3D depth measurement calibrated without waiting for ground processing.
Comparing steering commands from the autopilot against actual wheel position lets the system detect manual override without requiring torque sensors or driver-facing cameras, a simpler way to know when control has shifted.
Predicting hidden pedestrians and spotting distant hazards both require different sensor ranges; this fusion approach lets the system handle near and far threats simultaneously rather than choosing between them.
Probability-weighted response planning lets self-driving cars calibrate braking force to the actual likelihood of collision rather than worst-case scenarios, reducing unnecessary deceleration.
Nvidia's filing moves path planning onto the graphics chip, so a self-driving car can weigh hundreds of steering options per frame instead of picking one.
Sensor noise from internal electronics has plagued camera-based perception. Sony's shielding approach separates the imaging and transmission circuits to keep electrical interference from corrupting the road data that downstream models rely on.
Pre-computing which image regions matter most lets the chip skip wasted calculations when stitching multi-camera feeds into overhead views, cutting the processing load for real-time surround-view rendering.
Predicting pedestrians behind visual obstructions relies on fleet data: cars record where people commonly cross occluded intersections, then share those patterns so approaching vehicles can preemptively adjust speed and trajectory.
Predicting hidden pedestrians and timing lane changes require warnings that actually reach the driver. This patent ensures audio alerts work by embedding test signals that verify speakers function during normal playback.
Devices cross-checking GPS claims against independent position estimates catches spoofed or degraded signals before self-driving cars rely on them, hardening the location data that feeds prediction and planning models.
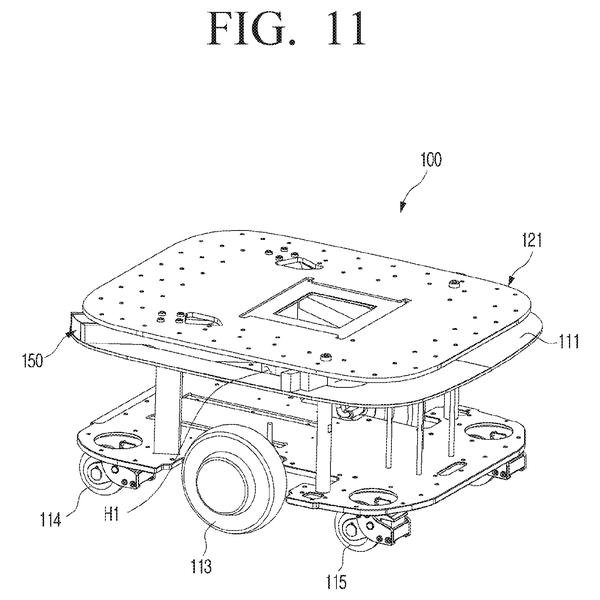
Sensor placement and support structures create detection gaps in current arrays. Samsung's filing proposes mechanical redesign to eliminate these shadows, advancing the physical architecture that self-driving systems depend on to see their surroundings.
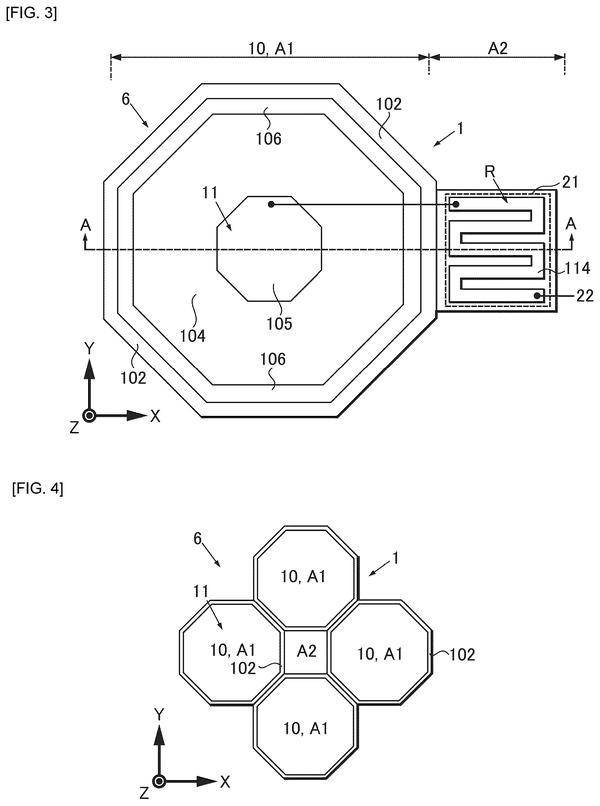
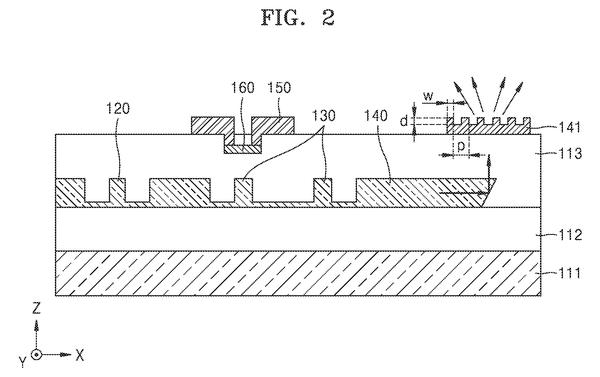
Steering light through nanoscale switches on a single chip removes the need for mechanical spinning components, compressing the entire LiDAR stack into silicon and cutting the size and cost barriers that have kept 3D sensing out of mass-market vehicles.
A single end-to-end neural network replaces the usual pipeline of separate detection, classification, and tracking modules, reducing handoff errors between stages where independent systems can contradict each other.
Combining interior camera and radar feeds lets the system detect occupants across all seats, extending Waymo and Nvidia's sensor fusion work from road sensing into cabin monitoring for child detection.
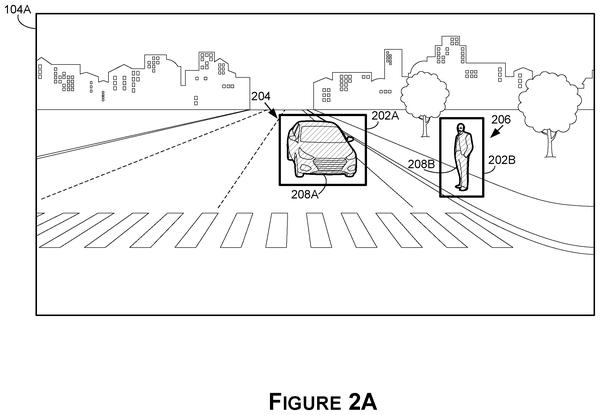
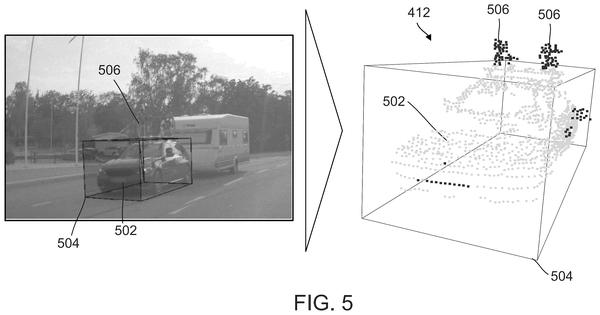
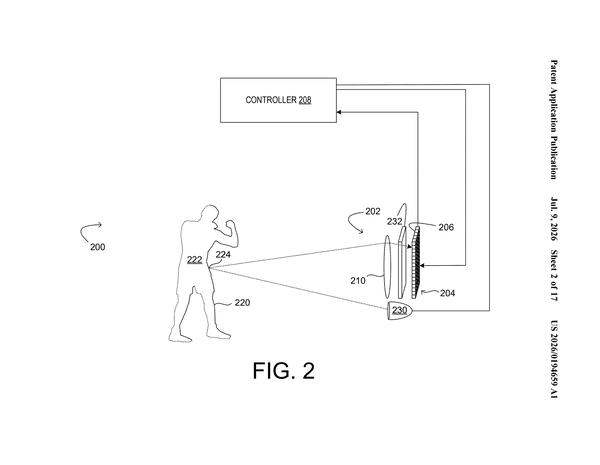
Fitting bounding boxes around detected objects lets the system infer depth and track motion in 3D, solving the core problem of converting flat camera images into spatial coordinates that self-driving systems need to navigate safely.
Interior monitoring needs calibration before it can work, this patent automates the geometric mapping that lets cabin cameras know where passengers and objects actually are.
Event cameras flood with signals in bright sun, killing their speed advantage. Sony's pixel-level control gate prevents saturation without losing the high-frequency data that makes these sensors valuable for fast-moving traffic.
Predicting hidden pedestrians and vehicles fills a gap the watchlist identified: self-driving systems need to infer motion beyond their direct line of sight, not just react to what sensors currently show.
Masking stitching boundaries between surround-view cameras prevents visual discontinuities when pedestrians or vehicles cross seams, keeping the bird's-eye display stable as the system recomposes its 360-degree map.
Thermal and visual sensors tuned separately for each seat location catch children who might be hidden in back rows or footwells, adding a safety layer for autonomous vehicles that park unattended.
Configurable sensor fusion for cabin monitoring lets automakers weight camera, radar, and biometric inputs differently depending on their vehicle class and safety priorities, rather than relying on fixed factory settings.
Mapping the deviation problem: when construction or obstacles force cars off their planned routes, the network needs real-time visibility into actual paths, not just alerts that something went wrong.
A motorized actuator layered with passive dampening lets one suspension system filter out high-frequency road texture while absorbing low-frequency bumps, expanding what sensor data the undercarriage can reliably capture.
Mapping and prediction both depend on fast LiDAR data. Separating geometry from color in compression buffers reduces the bandwidth needed to stream dense 3D scenes in real time.
Dual-pixel sensors with selectable distortion correction let motion-detection circuits operate on either raw or corrected data, improving tracking of fast-moving objects that lens curvature would otherwise blur.
Fusing camera and lidar data lets the system build a 3D map of scattered debris and classify each piece, so the car can decide whether an obstacle requires steering around it or just slowing down.
Radar returns unstructured point clouds that standard vision networks can't parse. Qualcomm's system converts raw radar into grid-based images, letting the same neural architectures work across both sensor types in rain and darkness.
Self-driving cars must distinguish between harmless debris and actual hazards in real time. Zoox's system automates that sorting, letting robotaxis ignore windblown trash instead of braking for every moving speck.
Self-driving cars that monitor passenger brain activity could adjust driving style to match individual comfort levels, adding a personalization layer beyond route optimization and hazard detection.
Radar's phase center shifts with frequency, breaking triangulation. Tesla's method auto-calibrates this per signal to keep spatial mapping accurate without manual tuning.
Self-driving cars can now build and refresh their own maps at the sensor level instead of relying on preloaded data, letting them navigate unfamiliar roads in real time.
Sensor cost cuts the other way: cheaper cameras plus software inference replace expensive hardware rather than upgrading it. This shifts the sensing race from pure hardware specs toward computational tricks that squeeze performance from basic components.
Self-driving cars need one unified picture of the road, not conflicting maps from each sensor. Qualcomm's method automatically aligns and merges 3D scans from multiple angles into a single, consistent view.
Self-driving cars that can infer complete lane geometry from fragments would navigate roads with worn or obscured markings the way human drivers do, closing a gap between lab conditions and real pavement.
Cleaner laser signals mean LiDAR can detect smaller objects and distant hazards with less power. The coating reduces internal reflections that degrade range and accuracy in cluttered roadside scenes.
Wireless vehicle signals arrive when direct sensor contact fails. Qualcomm's patent builds a confidence filter to weigh whether a car should act on those broadcasts or wait for independent confirmation.
Ranking which road objects matter in real time requires processing multiple sensor streams together, not separately, so the system can weigh a pedestrian near the curb differently than one across the street.
Self-driving cars need cameras that stay calibrated through vibration and temperature shifts on the road. Qualcomm's method lets cameras detect and correct their own drift without factory recalibration, keeping sensor data reliable during actual driving.
Resolving depth ambiguity in time-of-flight sensors by distinguishing nearby objects from distant ones at the same signal phase, improving the reliability of lidar-style range measurements in crowded driving scenes.
Recording steering and braking sequences from one vehicle's passage lets the next car replay those moves automatically, cutting the need for live human operators to react to road hazards in real time.
Radio broadcasts from nearby vehicles get synthesized into overhead maps that show moving traffic beyond the car's direct line of sight, filling gaps that cameras and lidar struggle with in fog or around corners.
Radio frequency reflections can detect moving objects without cameras, using Doppler shift analysis across multiple signal bounces to identify velocity and position.
A highway exit might have a 'trucks only' sign that applies to one lane but not the three next to it. Getting that wrong at highway speed is a real problem, and Nvidia has filed a patent for a system that figures out exactly which lanes a sign is talking about.
Volumetric video capture from onboard cameras lets autonomous vehicles record roadside events in 3D rather than flat 2D, potentially giving downstream AI systems richer spatial data to judge what's newsworthy and worth uploading.
Compressing lane boundary data into minimal mathematical descriptions cuts the processing load when cars must track road geometry in real time across multiple sensor streams.
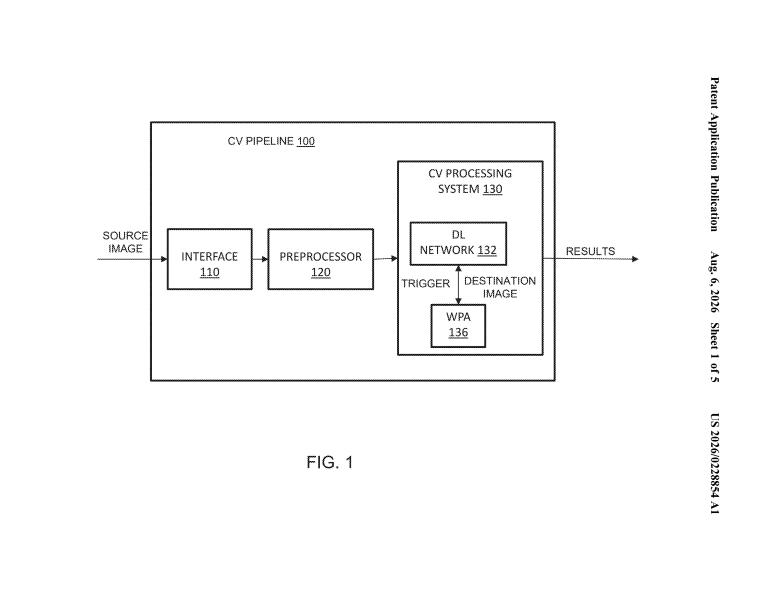
Nvidia's filing works out depth and object labels from ordinary 2D camera feeds alone, which could cut the costly sensor hardware in self-driving cars.
Sensing systems trained on typical roads tend to miss anomalies, so Nvidia's approach weights rare scenarios during training to prevent the model from ignoring unexpected hazards when they do appear.
Tracking moving objects frame-by-frame requires fewer labeled examples when the model learns to predict motion patterns itself, cutting the human annotation burden for real-time 3D scene understanding.
A shared real-time map of nearby autonomous vehicles' positions and status cuts the information gap between pedestrians and self-driving cars, letting humans make crossing decisions with the same situational awareness the vehicles have.
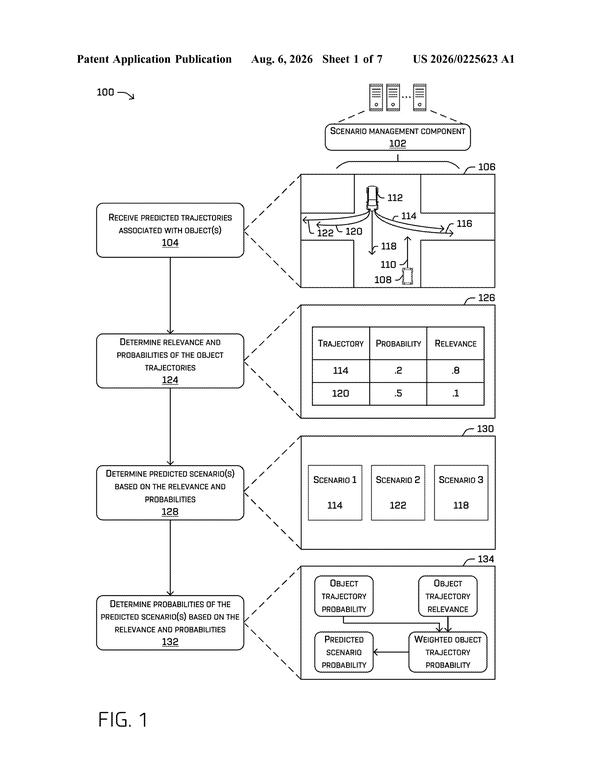
Prediction in the watchlist has moved from single-scenario planning to mapping behavior trees; this patent shows how to compute routes that work across all branches simultaneously rather than picking one path and adapting.
A neural network that maintains stable IDs for each moving object across video frames, so the system knows which car is which rather than treating each detection as a new thing.
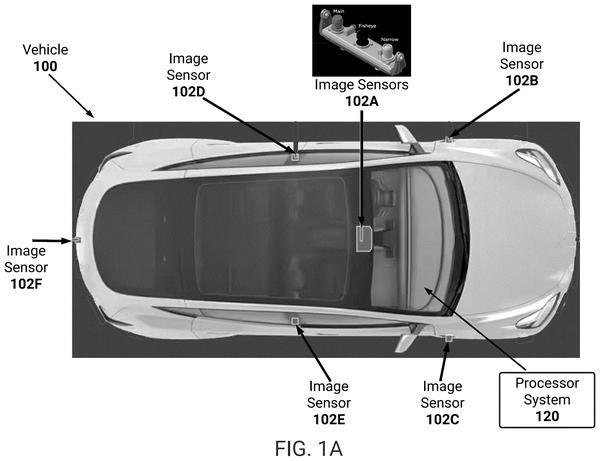
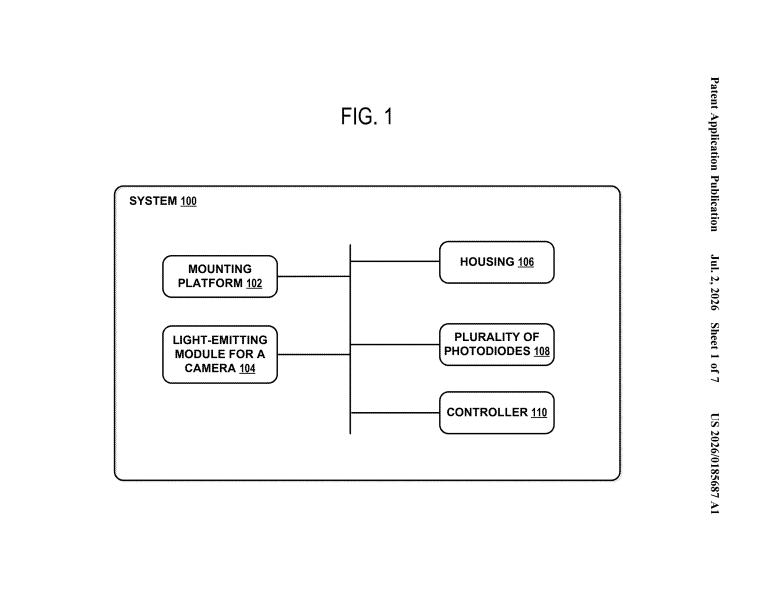
A fisheye camera paired with infrared emitters in one module lets self-driving cars see clearly at night while keeping the sensor package small enough to fit existing vehicle designs.
A self-driving car needs to read both nearby bright objects and distant dark ones from the same laser pulse. Waymo's amplifier lets lidar adjust its sensitivity on the fly instead of losing detail to overexposure or underexposure.
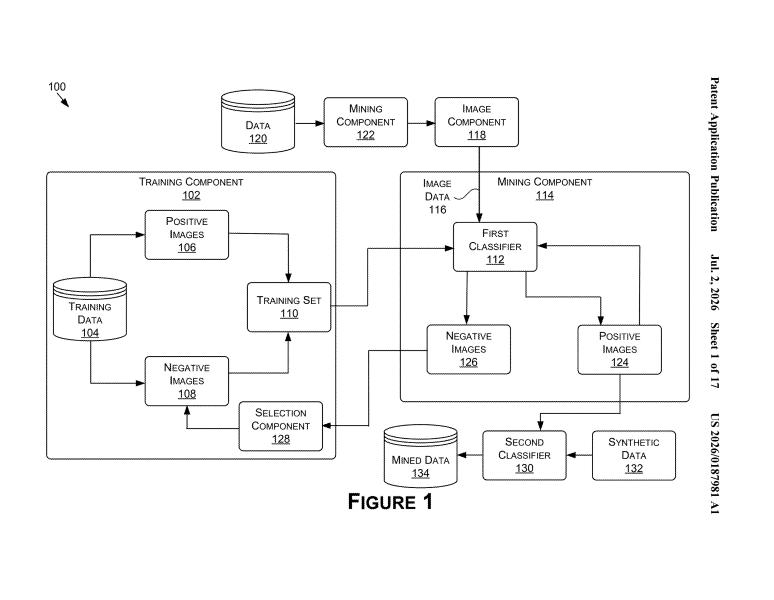
A two-stage filtering system cuts the manual labor of finding training images from video footage. The first pass eliminates obvious negatives; the second ranks remaining candidates by relevance, so engineers label fewer, higher-value frames.
Blocked sightlines at intersections need human judgment to resolve safely. Waymo's filing describes giving remote operators real-time sensor feeds to authorize incremental forward movement when the car's own perception hits a wall.
Simulating dangerous edge cases requires realistic traffic that's prohibitively expensive to create by hand. Zoox's system generates AI traffic automatically, letting engineers test self-driving responses to rare scenarios without waiting for real-world data.
Replaying recorded sensor data from real drives lets Waymo validate new software versions against thousands of actual road scenarios without returning to those locations, collapsing the test cycle from weeks of fresh driving to hours of simulation.
Sensing sirens through fog or urban canyons remains unsolved; Sony's approach inverts the problem by having emergency vehicles broadcast their routes directly to nearby navigation systems, creating alerts before audio detection would work.
Self-driving cars need camera protection from direct sunlight during highway driving. This filing shows how lidar can act as an early warning system, triggering camera adjustments before glare causes missed obstacles.
A two-stage filter first isolates traffic signs from road clutter, then classifies each one, reducing the computational load of scanning every roadside object for meaning.
Early frame processing lets prediction models start work on partial camera data rather than waiting for complete frames, shaving milliseconds off the perception pipeline.
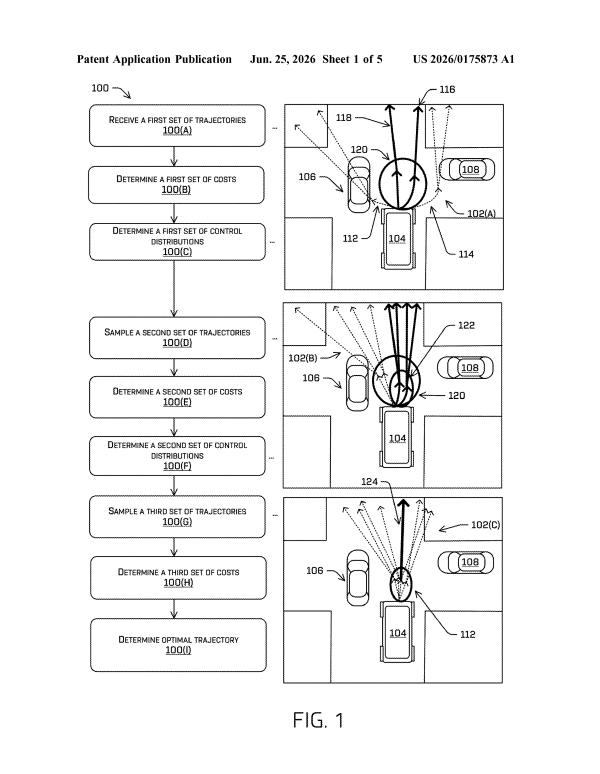
A sampling-and-refinement loop lets the car generate thousands of steering options per second, score them against safety and efficiency metrics, and iteratively discard weak candidates to converge on the best path forward.
A robotaxi that brakes too hard wastes time; one that hesitates costs trust. This filing covers the gap between sensing a red light and executing the stop smoothly enough to feel safe.
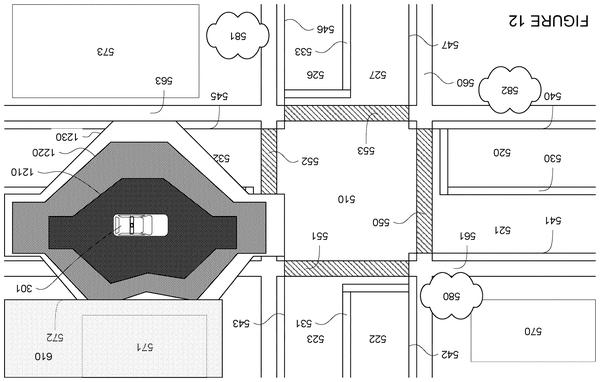
Where the sensing race gets physical: Zoox moves beyond passive perception by patenting active repositioning to clear sensor sightlines when large vehicles block critical road features like traffic signals.
Predicting collision risks requires checking not just the planned path but alternative escape routes too. Zoox's filing shows how to evaluate both simultaneously, letting the car know its options before it needs to act.
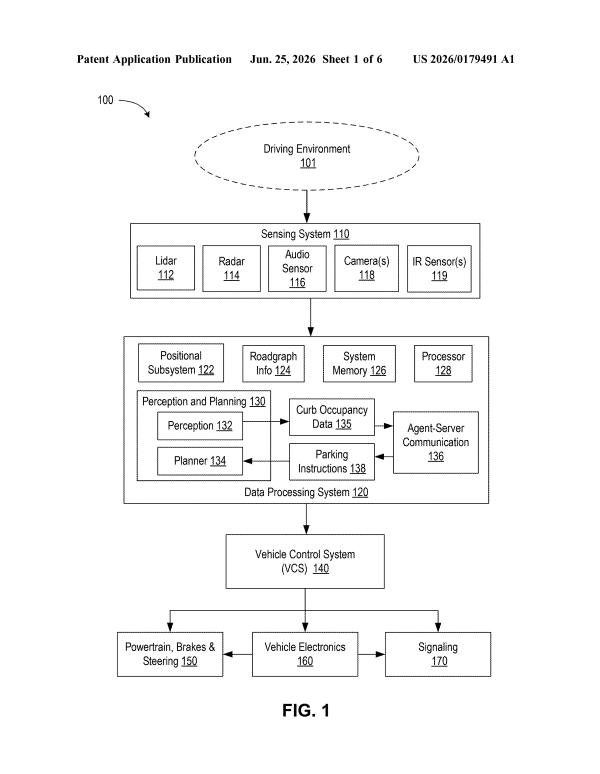
Fleet-wide sensor sharing lets robotaxis know which curbs are actually available before arriving at a block, cutting the search time that makes parking a coordination bottleneck for autonomous vehicles.
A self-driving car needs to see clearly the instant light changes, say, exiting a garage into sun. This patent speeds up how cameras adjust exposure so the system gets usable images without the blind moment human eyes skip past instantly.
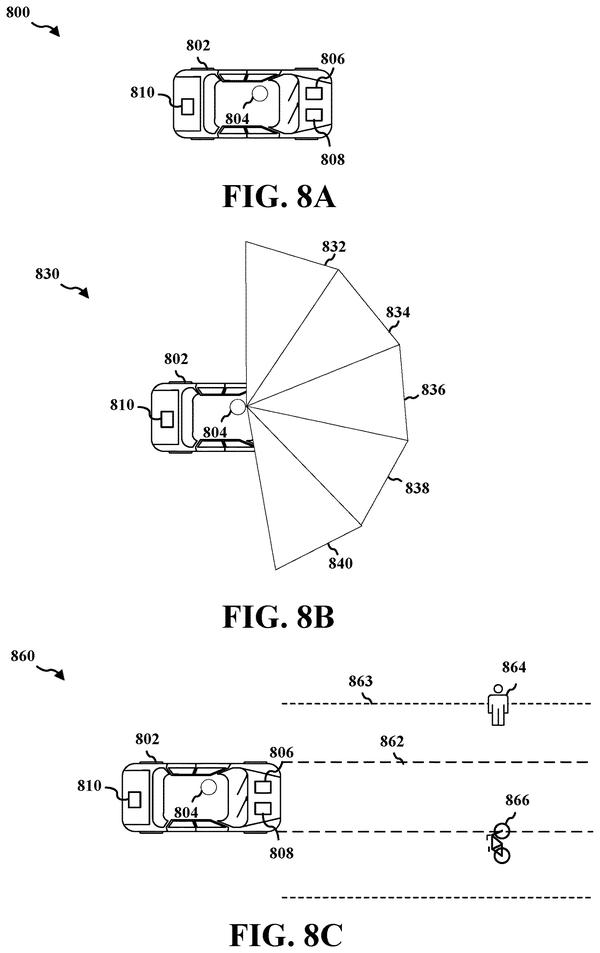
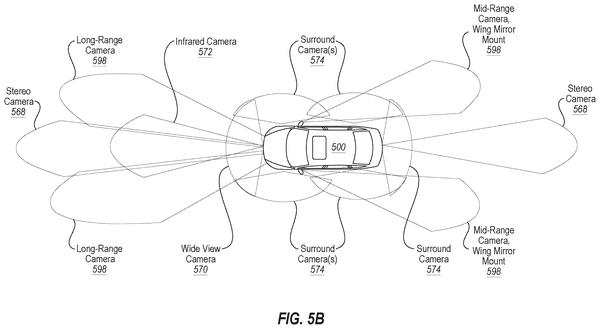
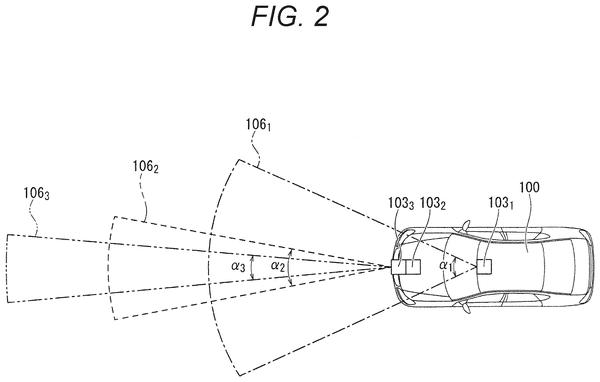
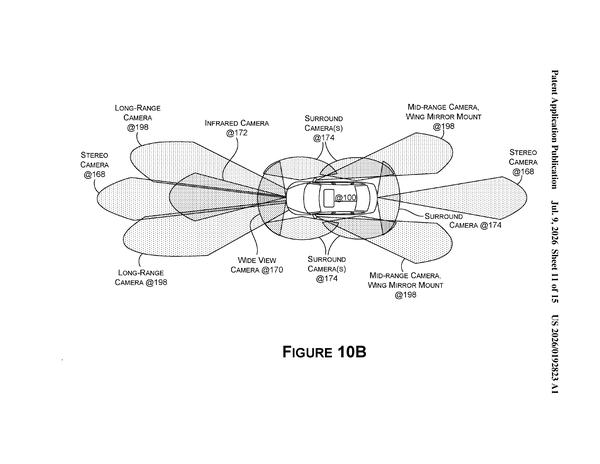
Detecting obstacles at vastly different distances requires cameras built for different focal ranges. Waymo's three-camera setup splits the job instead of asking one sensor to handle both nearby pedestrians and distant vehicles.
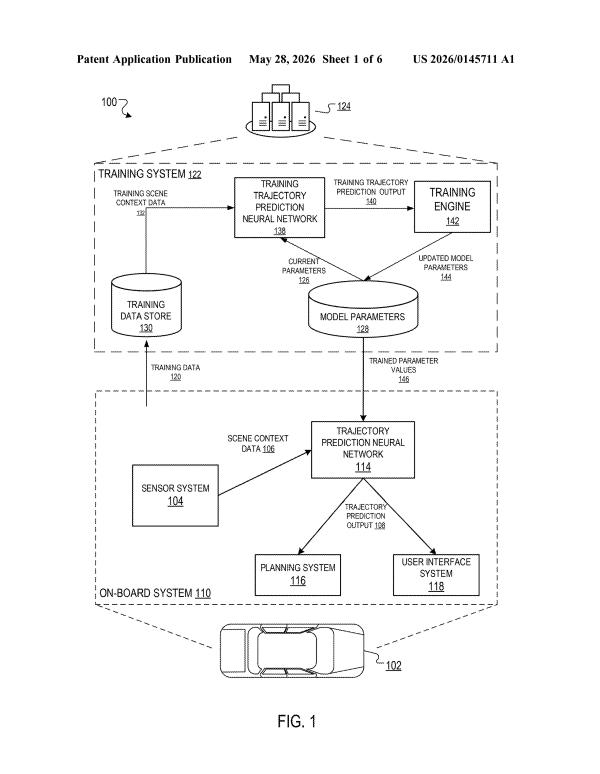
Self-driving cars need to brake or swerve before danger arrives, so Waymo is training its AI to forecast how a traffic scene will evolve seconds ahead using live sensor feeds rather than reactive pattern matching.
Merging route planning with traffic prediction into a single model eliminates the processing lag that comes from running these as separate steps, letting the car respond faster to other drivers' moves.
Coordinating autonomy levels across a fleet rather than having each vehicle decide independently lets cars share real-time sensor data to adapt faster to changing road conditions.
Camera-based lane topology parsing lets Tesla's system infer which roads lanes actually connect to, sidestepping the need for pre-loaded maps at fork points and merges where autonomous vehicles typically lose confidence.
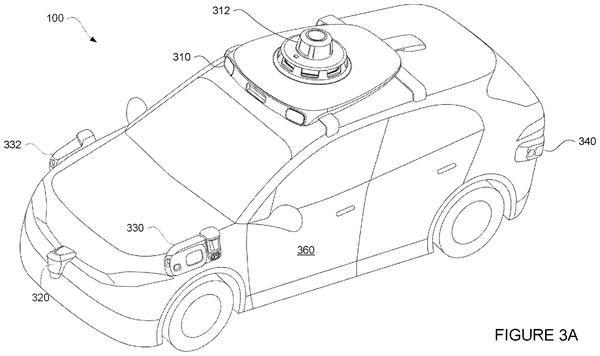
Self-driving AI needs massive amounts of real-world driving data, but Zoox avoids deploying its own vehicles by mounting a full sensor suite on ordinary cars to collect training footage at scale.
Rare dangerous scenarios starve AI training data. Zoox's method synthetically generates edge cases that occur too infrequently in real driving to teach self-driving systems how to handle them safely.
Sensor drift during operation poses a safety risk that existing calibration methods miss. Waymo's approach uses map data as a reference frame to detect and correct misalignment continuously, rather than relying on periodic manual checks.
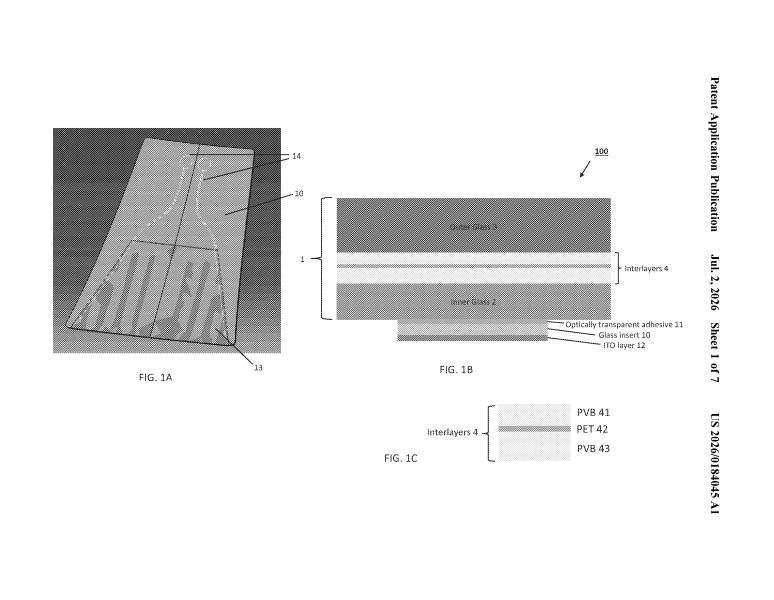
A window combining resistive heating and thermoelectric cooling in adjacent zones lets Waymo control exactly where condensation forms, keeping critical sensor views clear without overheating the optical surface.
Self-driving cars need to know when weather degrades their sensors' reliability, not just when it degrades visibility. This filing lets them measure atmospheric conditions by cross-checking what cameras and lidar actually report.
As fleets grow denser, radar crosstalk becomes a real safety risk. Waymo's solution assigns each vehicle a unique signal code so radars can filter out interference from nearby cars.
A self-driving car in heavy fog could see beyond its sensor range by deploying a drone as a forward scout, turning poor visibility from a dead zone into navigable space.
Switching between time-based and distance-based planning lets self-driving cars handle both highway cruising and tight maneuvers without replanning from scratch each time.
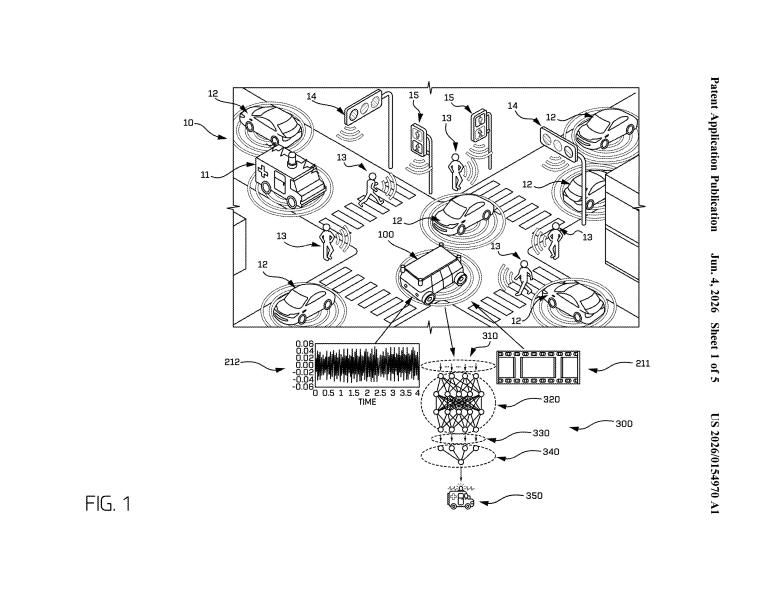
Combining audio from onboard microphones with camera and lidar data lets Zoox detect emergency vehicles before they're visible, filling a gap where vision-only systems fail around corners or in heavy traffic.
Parallel redundant processors let each subsystem monitor independent sensor streams, so a hardware failure in one brain doesn't blind the car to what's happening around it during the limp-home sequence.
The sensor data already misses thin objects in point clouds. Zoox proposes fixing that during training by helping models weight sparse features equally with dense ones, filling a gap in how self-driving systems learn to see obstacles.
Running neural networks on camera frames requires crushing massive matrix math fast enough for real-time decisions. Tesla's chip design processes thousands of multiply-accumulate operations simultaneously rather than sequentially.
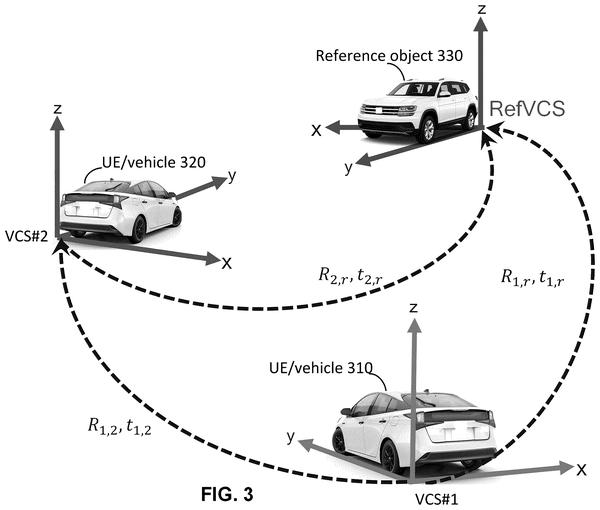
Vehicles in the same fleet exchange sensor observations of each other's position to correct GPS drift and map errors without relying on infrastructure, improving localization accuracy during close encounters on city streets.
A self-driving car needs to know not just where pedestrians and cyclists are heading, but the precise timing of each movement. Zoox's approach trains separate models for trajectory and speed, letting each focus on its specific prediction problem.
Self-driving cars need to predict multiple pedestrians and vehicles simultaneously rather than sequentially. Waymo's neural network cuts the computational cost of running those parallel predictions in real time.
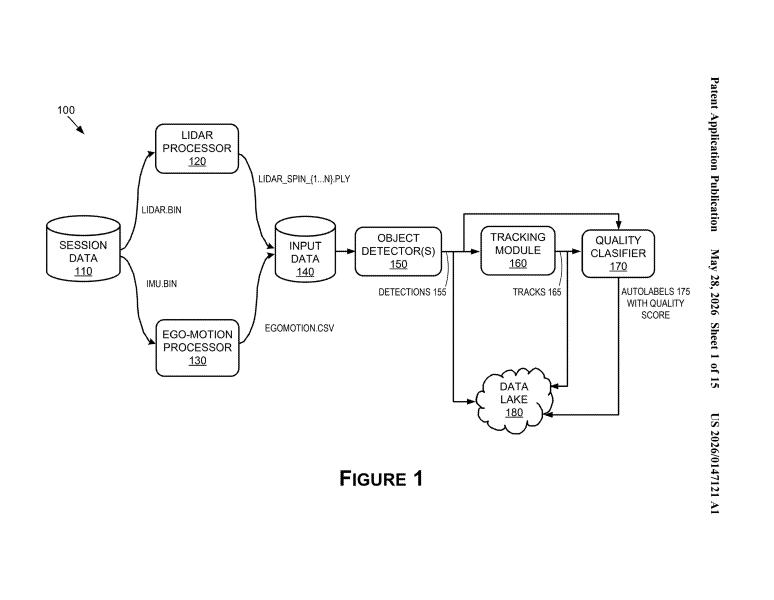
Self-driving systems need millions of labeled training examples to learn what they're seeing. Nvidia's approach lets the AI handle routine annotation work itself, shrinking the human bottleneck that currently slows down data preparation.
Waymo's approach extends LiDAR's effective range by harvesting ambient light data the sensor already collects, solving the blind spot problem where dark or distant objects fail to reflect active laser pulses back to the vehicle.
Depot routing adds a new layer to the sensing problem: vehicles must navigate and self-position within structured service environments, requiring real-time mapping of internal spaces and coordination between car and infrastructure.
Linking camera, lidar, and radar outputs to language descriptions lets the system learn which sensor details actually matter for driving decisions, rather than just matching sensor feeds to each other.
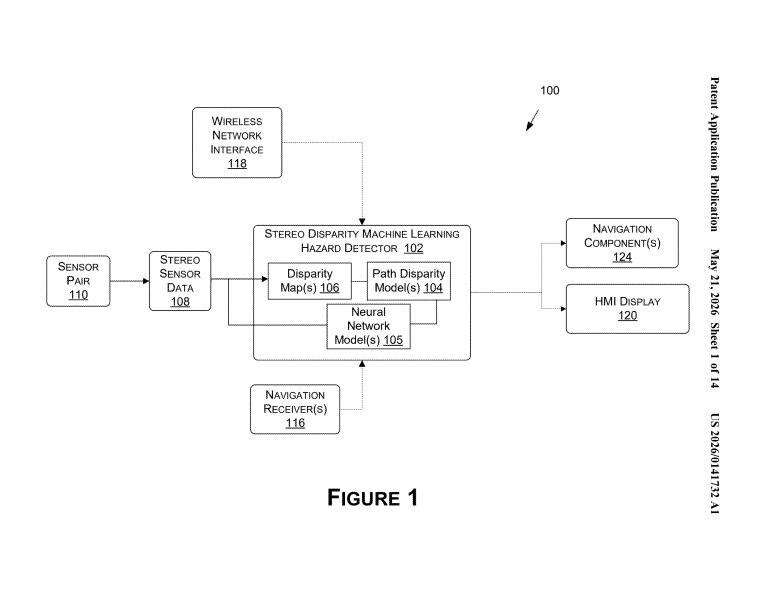
Distinguishing potholes from shadows requires stereo cameras to read depth shifts pixel-by-pixel, then feed those disparities into machine learning models that classify what actually threatens the vehicle versus what's just road texture.
Self-driving systems need to explain what they see in human terms so engineers can verify safe behavior. Waymo's neural network converts raw sensor streams into direct answers to specific questions, collapsing the gap between perception and reasoning.
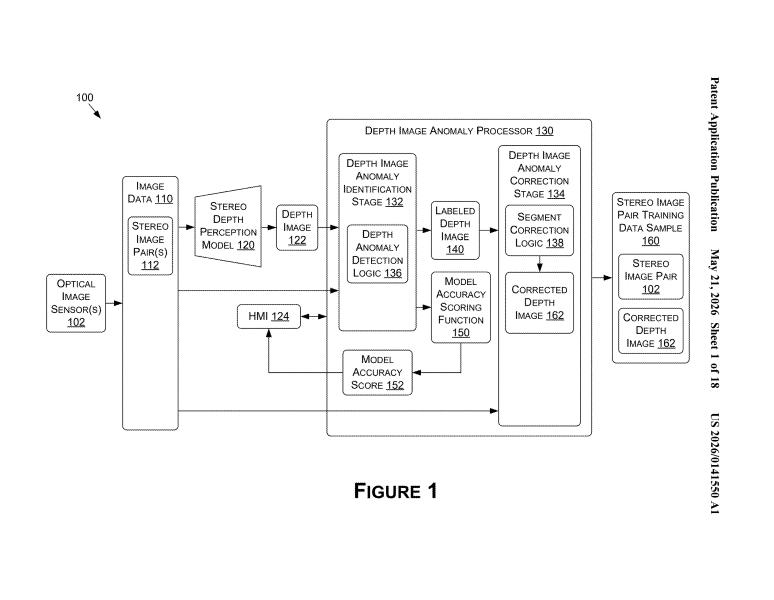
Stereo depth estimates fail predictably in reflective surfaces, so Nvidia built an automated correction loop that catches and fixes bad readings without manual intervention, letting the system self-repair as it encounters problematic lighting or materials.
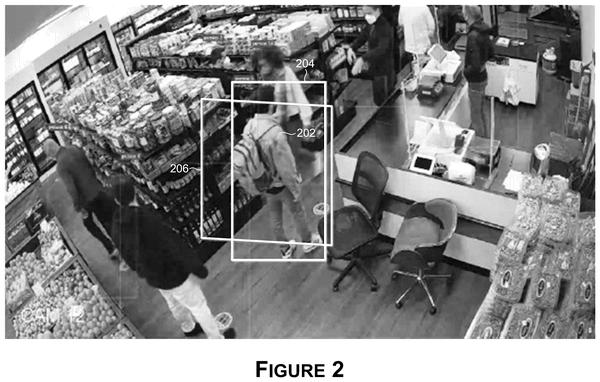
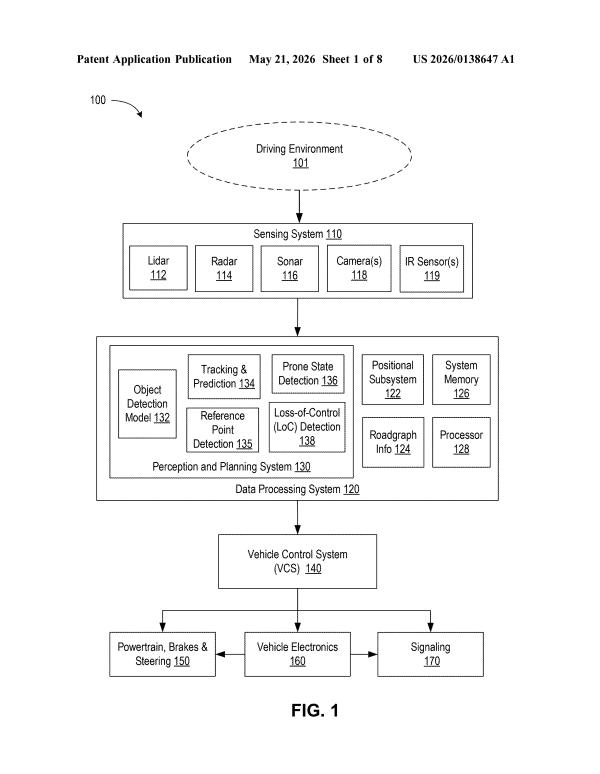
Tracking body geometry in real time lets the system spot imbalance before a cyclist or pedestrian actually falls, giving the car milliseconds to brake or swerve while the person is still upright.
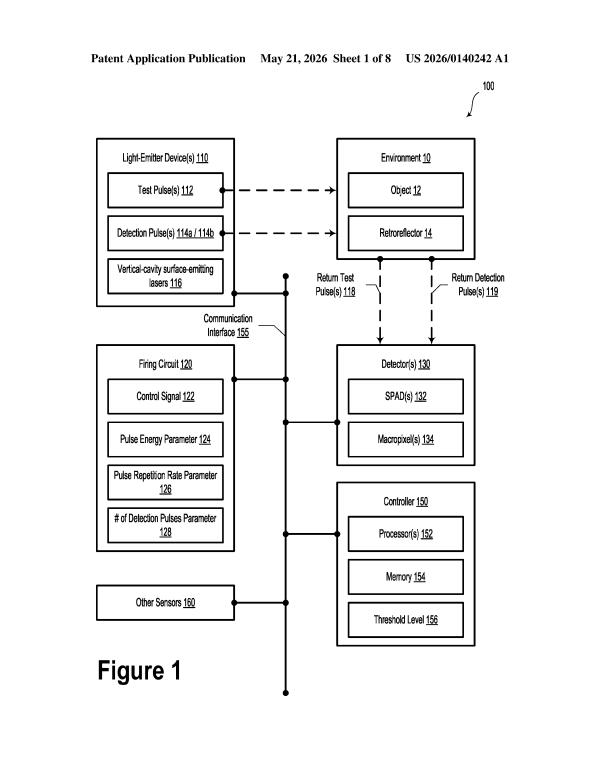
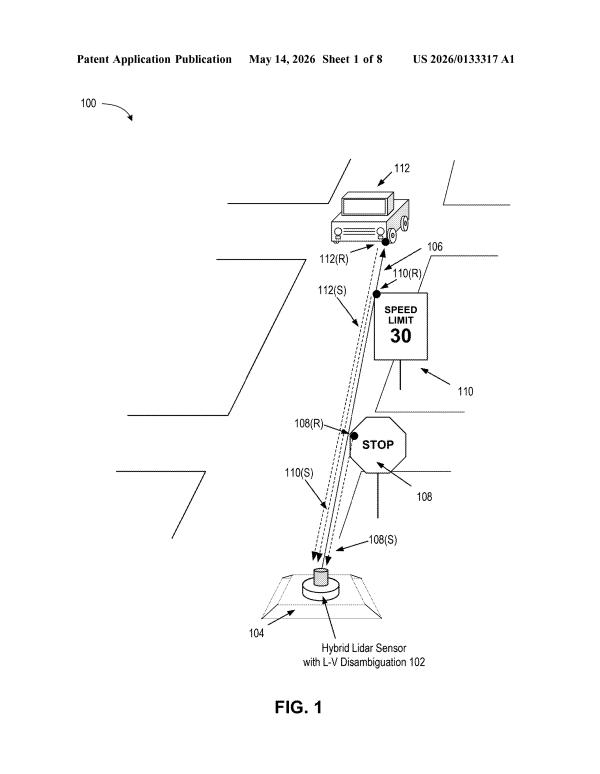
Self-driving cars go blind when lidar bounces off reflective road signs and bike gear. Waymo's system pre-screens for these surfaces so it can dial down sensitivity before they saturate the sensor.
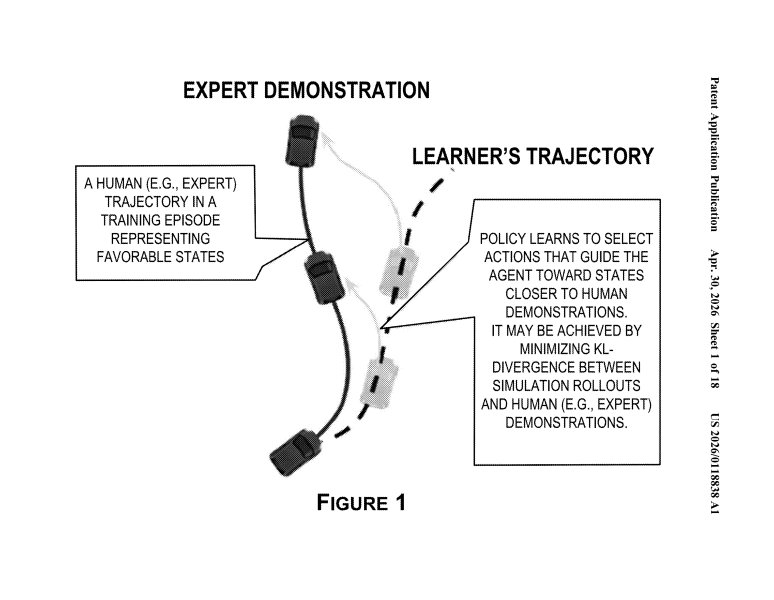
Self-driving cars trained only on flawless human driving freeze when reality deviates even slightly. Nvidia's approach creates a feedback loop where the AI learns recovery moves, not just ideal ones.
The vision-only approach needs rare scenarios to train properly. Tesla's solution generates synthetic images of edge cases, blizzards, floods, traffic violations, rather than waiting for them to occur naturally on real roads.
Planning paths in real-time without recomputing from scratch requires pre-building options. Zoox's lattice approach lets the car swap between pre-computed trajectories when obstacles appear, rather than generating new routes on the fly.
Collecting rare driving scenarios randomly wastes miles; this filing lets Waymo's fleet converge on locations where edge cases actually occur, compressing training data into useful situations.
Continuous friction estimates let the car adjust braking and cornering limits as road conditions shift, moving from static safety margins to live performance boundaries.
Self-driving cars need grip estimates, not just rain alerts. This filing shows Waymo building real-time surface condition sensing that lets vehicles adjust braking and steering before hydroplaning becomes a problem.
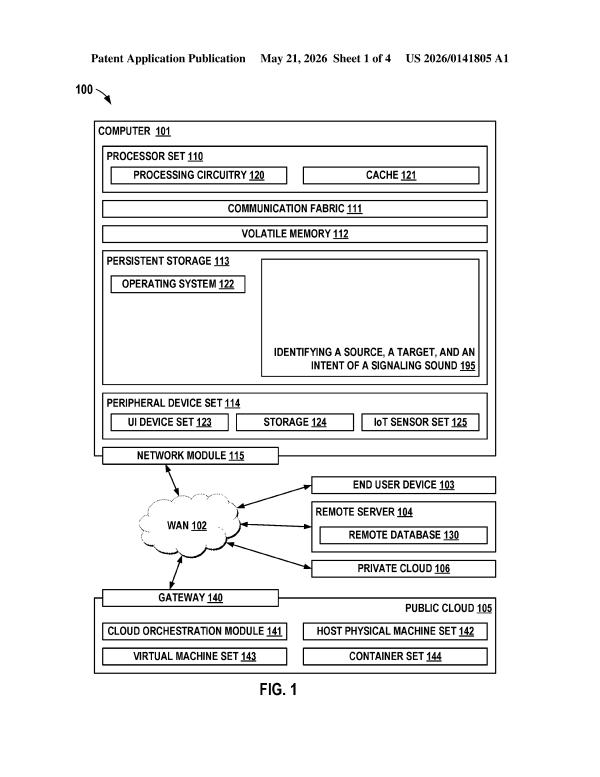
Acoustic localization lets the car pinpoint which nearby vehicle is honking, then notifies the driver of the source and intent, solving the ambiguity of whether a horn blast is directed at your car or someone else's.
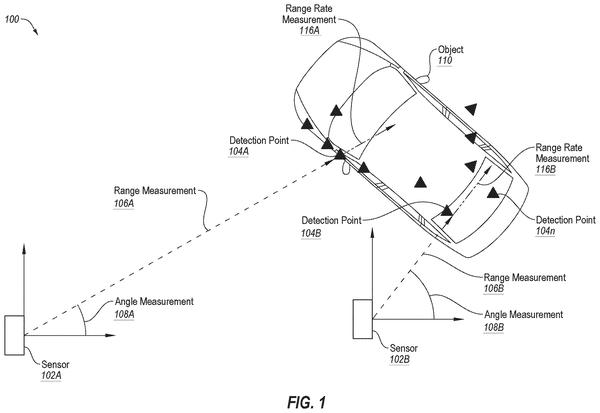
Matching speed data to distance data across multiple objects simultaneously lets the car track what's actually moving and where, rather than creating false threat scenarios from sensor confusion.
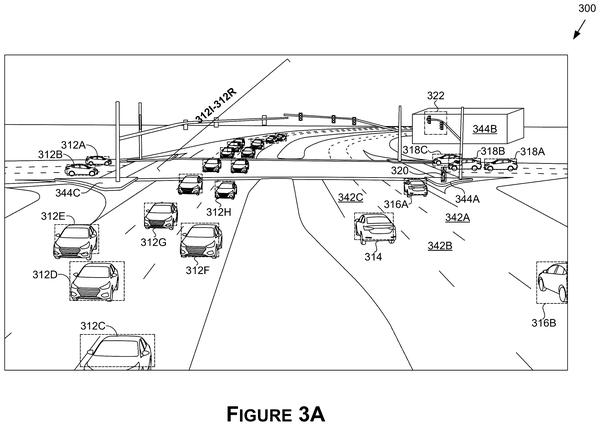
Predicting other drivers' behavior in real time, Waymo's system generates multiple possible lane-change paths and scores them based on forecasted movements of surrounding vehicles, turning a judgment call into a rankable set of options.
A self-driving car that spots danger between other road users can plan safer routes around accidents that haven't happened yet, rather than just reacting after they occur.
Detecting fog optically rather than guessing from degraded data lets the sensor adjust its own parameters in real time instead of relying on pre-set configurations to handle unknown conditions.
Projecting stereo depth onto a top-down map shrinks the compute burden by converting raw camera data into a format self-driving stacks can act on faster, letting embedded chips handle the geometry without offloading to a central processor.
Self-driving systems need overhead maps to plan routes, but generating them from stereo cameras usually demands expensive processors. Nvidia's approach compresses this conversion into a lightweight operation that runs on modest hardware.
Sensor data fusion into driving decisions requires real-time scene understanding. Waymo's transformer model collapses the pipeline from raw perception to steering commands into a single inference step.
Generating synthetic 3D road surface data sidesteps the months-long process of collecting and labeling real-world examples, letting Nvidia's self-driving systems train on road geometry variations without deploying test fleets.
Self-driving systems need to know how to recover from bad decisions mid-drive. Nvidia's approach creates synthetic recovery scenarios at scale rather than waiting for real-world near-misses to naturally occur.
Questions readers ask
Is Waymo or Nvidia further ahead in self-driving sensor technology?
The patents don't show a clear leader. Waymo's filings lean toward sensor fusion and prediction, like LiDAR that adapts to fog or models that guess where hidden pedestrians might be. Nvidia's filings focus more on turning raw camera and LiDAR data into usable formats, like bird's eye views and synthetic training data. Both are solving different pieces of the same puzzle.
Does a patent mean these self-driving features are actually in cars now?
No. A patent filing shows a company protecting an idea it wants to use, not a feature that has shipped. Some of these filings, like Waymo's siren-detecting microphone system or Nvidia's self-correcting training loop, describe research directions that may take years to reach an actual vehicle, if they do at all.
What problems keep showing up across these self-driving patents?
Two problems repeat often: making sense of messy real-world sensor data, and predicting what other road users will do before they do it. Fog, hidden pedestrians, sirens, and unpredictable drivers all point to the same underlying challenge, getting a car to react correctly to things it can't fully see yet.
Is Tesla part of this self-driving sensing race too?
Mostly this watchlist tracks Waymo and Nvidia, but Tesla shows up too, with a patent on reading a situation's intent before the car moves. That overlap suggests the same underlying questions, like when a car should trust its own read of a scene, matter across the industry, not just to two companies.
Want this weekly breakdown for a company we don't cover?
Patentlyze Pro →
The weekly email: the best of Big Tech's filings, in plain English. Free.