
Samsung Patents a Robot LiDAR System That Switches Laser Power Mid-Scan
A LiDAR sensor that's great at spotting distant objects often blinds itself on nearby ones. Samsung's new patent describes a robot that solves this by rapidly toggling its laser between two power levels as it spins, then stitching the results into one accurate picture of the room.
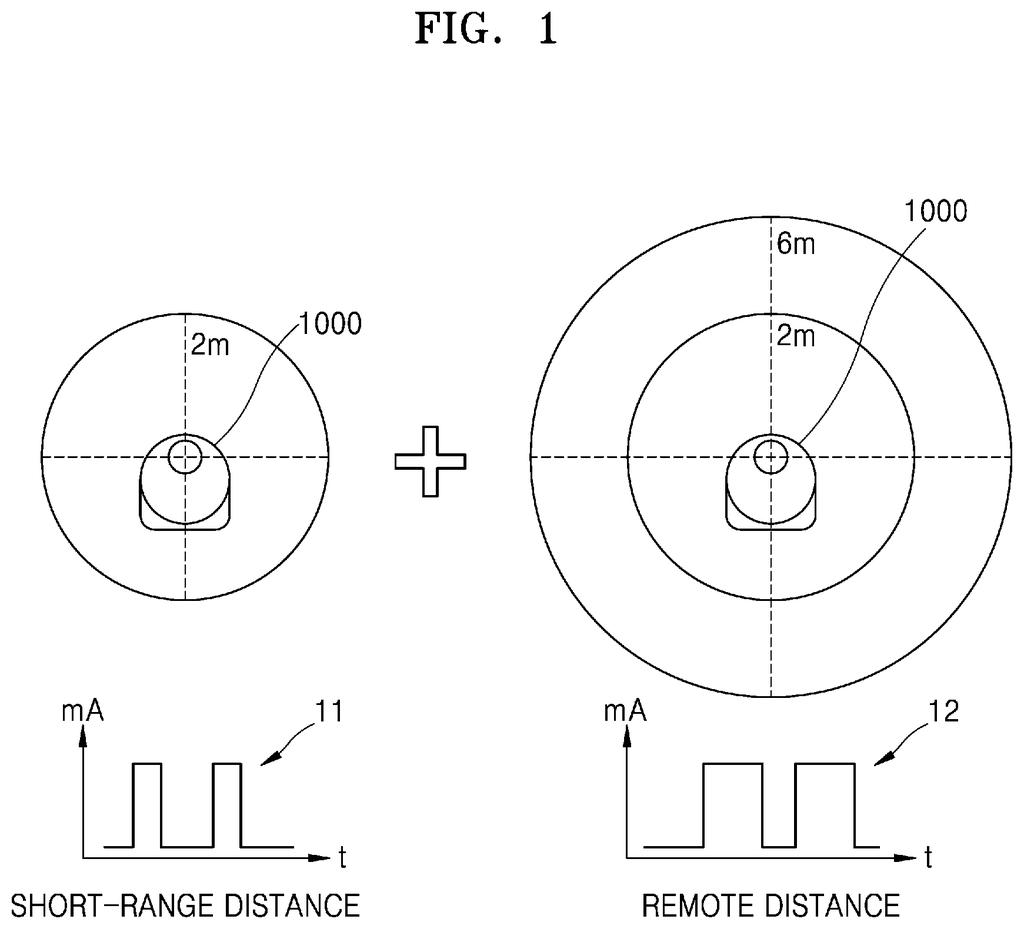
How Samsung's robot sees close and far at the same time
You're watching a home robot glide across your living room, weaving around your coffee table and stopping just short of your dog. That kind of precision depends on the robot's distance sensor, and that sensor has a basic conflict built into it: the laser pulse strong enough to reach the couch across the room will overload when it bounces off the chair that's only two feet away.
Samsung's patent describes a fix where the robot's spinning LiDAR sensor doesn't use a single fixed laser strength. Instead, it alternates between a low-power pulse for nearby objects and a high-power pulse for distant ones, all within the same rotation. The returned signals are then checked and corrected before the robot decides how to move.
The result is a robot that, in theory, can build a more accurate map of mixed-distance environments without needing two separate sensors. Think crowded kitchens, cluttered hallways, or anywhere a robot has to deal with objects at very different distances in the same sweep of its sensor.
… determine, based on the obtained information about the distance, to change an energy of a laser pulse signal of the TOF LiDAR sensor to a short-range pulse energy for short-range objects and a remote pulse energy for remote objects …
Translation: The robot decides whether to use a weak or strong laser pulse depending on how far away an object is.
How the dual-energy laser scan and correction loop works
A Time of Flight (ToF) LiDAR sensor (a spinning laser rangefinder that measures distance by timing how long a pulse takes to bounce back) works well when targets are at a similar range. The problem is physics: a pulse energetic enough to reach 10 meters will saturate the detector when it hits something 30 centimeters away, producing garbage data at close range.
Samsung's system addresses this by adding dynamic power switching. As the sensor rotates, the robot's processor evaluates current distance data and flags whether each angular zone contains short-range or remote objects. It then commands the LiDAR to fire a low-energy pulse toward nearby objects and a high-energy pulse toward distant ones, interleaving both within a single scan cycle.
The returning reflections are processed through a correction step before feeding into the navigation decision. This correction compensates for the fact that the two energy levels return different signal profiles, ensuring the merged distance map is internally consistent.
- Detect current object distances across the scan arc
- Classify each zone as short-range or remote
- Switch laser pulse energy accordingly as the sensor rotates
- Correct and merge reflection data into a unified distance picture
- Drive the robot's movement module from the corrected map
… outputs laser pulse signals of the TOF LiDAR sensor by switching a laser pulse signal of a short-range pulse energy and a laser pulse signal of a remote pulse energy, while the TOF LiDAR sensor rotates …
Translation: The spinning sensor constantly alternates between near and far laser strengths as it scans the room.
What this means for Samsung's home robot ambitions
For Samsung, which has been publicly building toward home robot products, navigation accuracy in real domestic spaces is a core problem. Home environments are genuinely awkward for single-energy LiDAR: furniture at arm's length, walls across the room, and pets moving through the middle distance all coexist in the same scan. A sensor that handles all of those reliably without extra hardware is worth having.
For you as a potential buyer of any robot that uses this approach, the practical upside is fewer phantom collisions, fewer missed obstacles, and a robot that doesn't need to slow to a crawl near cluttered areas. Samsung keeps filing on robot sensing and navigation, and this patent suggests the underlying sensor work is further along than most of the company's public robot announcements have shown.
Samsung's 43rd filing we've tracked since May joins earlier applications like one slowing near edges and one matching scans to floor plans in our home robot applications.
Claim 1 is written broadly enough to cover any robot that (a) reads distance data, (b) switches LiDAR pulse energy based on that data, (c) runs a correction step, and (d) moves from the corrected output. That's a fairly wide net. It doesn't specify a particular correction algorithm, a particular scanning speed, or even a minimum number of energy levels, just that switching happens and correction follows.
That breadth matters because it could be read to cover a range of dual-energy LiDAR implementations, not just Samsung's specific hardware. Whether the claim survives prior-art scrutiny at that scope is a different question, but as written, any robot maker adding simple pulse-energy toggling to a ToF LiDAR might find this claim sitting in their path.
The correction step is the part of the claim that does real work. Without it, you'd just have a robot shooting mixed-power pulses with no guarantee the resulting map is accurate. The patent is essentially claiming the whole loop, sense-classify-fire-correct-move, as a unit. That's a legitimate engineering contribution, even if the individual pieces are not new in isolation.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Samsung patent news breaks.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
17 drawing sheets from US 2026/0276832 A1 · click any drawing to enlarge


Show the other 9 sheets


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in