
A New Google Patent Teaches Robots to Ask "Can I Actually Do That?"
Ask a chatbot how to clean up a spilled drink and it may tell you to grab a vacuum. Google's new patent makes a robot check each AI suggestion against what it can actually do in the room it's standing in.
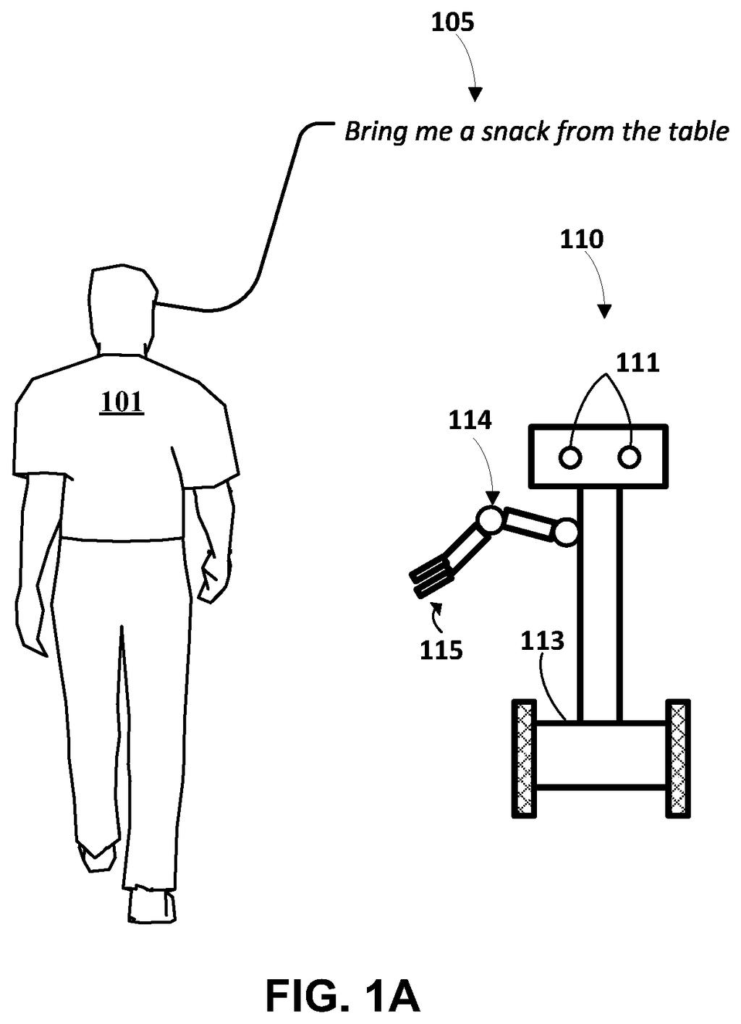
What Google's robot-and-chatbot patent actually does
Imagine you spill a drink and tell a home robot, "I spilled my drink on the table, can you help?" A chatbot-style AI might sensibly suggest using a vacuum. But your robot has no vacuum, and wouldn't know how to run one if it did.
Google's patent goes after that gap. The AI proposes ideas, and the robot tests each one two ways: does this help with what the person asked, and can I actually pull it off from here, given what my camera sees? Only a step that passes both tests gets picked.
Then the robot does that step, looks around again, and asks the AI what should come next. A request like "bring me a snack from the table" becomes a short chain: go to the table, pick up the pear, and so on until the job is done.
identifying a high-level instruction, the high-level instruction being a free-form natural language instruction; identifying state data that is based on sensor data captured by one or more sensor components of a robot; generating a prompt that includes the high-level instruction and the state data; …
Translation: The robot takes a plain-English command and combines it with sensor data to make a prompt.
How the robot scores each possible next move
The filing covers a way to turn a loose spoken or typed request into robot movement. A large language model (the same kind of AI behind chatbots) gets the request plus information from the robot's sensors, such as a list of objects its camera sees. It then writes a plan in plain sentences, like "1. go to the table, 2. pick up the pear."
Each sentence in the plan matches one of the robot's pre-trained low-level skills. A second model, called a policy model (software that turns a skill description and a camera view into motor commands), takes the first skill and the sensor data and produces action output. That output covers where the gripper should be, how it should be angled, and whether to stop.
The description adds a checking step. Each candidate skill gets two scores:
- Task-grounding: how likely the AI thinks the skill is the right next step for the request.
- World-grounding: how likely the skill is to succeed right now, estimated by a value function (a model trained to predict success from the current scene).
The two scores are multiplied and the highest total wins. In the filing's example, "pick up the pear" scores low while the robot is far from the table and high once it has moved closer.
After each skill finishes, the request and the completed step go back to the AI to get the next step, until it chooses "done." The result is a readable plan written in language.
… generate, based on the LLM output and a NL skill description of a robotic skill, a task-grounding measure that reflects a probability of the skill description in the probability distribution of the LLM output.
Translation: The system calculates how well a potential robot action matches what the language model suggested.
What this means for a robot helping at home
If robots ever help in homes or offices, the difference matters a lot. A machine that only understands exact commands like "clean" is a gadget. One that can handle "I spilled my drink" starts to feel like help. This approach also aims to stop a robot from confidently attempting something it can't do, like fetching a vacuum that isn't there. And because the plan is written in plain sentences, a person can read what the robot intends to do.
The filing names Google's own language models, PaLM and LaMDA, as examples of the AI that writes the plan, tying Google's chatbot work to physical machines. It also says new skills are straightforward to add to the robot's repertoire. Keep in mind this is a patent application describing an example setup, such as an office kitchen with a pear and keys on a table. It does not point to a specific product.
Google's 54th filing we've tracked since May in our AI agents acting for you watch follows patents for finishing chores across apps and turning on your TV automatically.
The benefit you would notice is simple: you talk to a robot like a person and it does not embarrass itself. Today a home robot usually needs the exact right command. This filing aims for one that hears "I spilled my drink" and picks from things it can actually do.
The failure it prevents is the confident wrong answer. A chatbot will happily tell you to fetch a vacuum, and a robot that believed it would wander off looking for one. Scoring every option against what the camera sees keeps the plan honest.
The catch is that the robot only knows the skills it has been trained on, so a short skill list means a short list of things it can do for you. Still, the written-out plan is a real plus, because you can read what it intends before it moves.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Google patent news breaks.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
8 drawing sheets from US 2026/0316289 A1 · click any drawing to enlarge


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in