
Sony Patents a Server That Plans the Most Efficient Path for Moving Robots
Getting a fleet of robots from A to B without them bumping into each other is harder than it sounds. Sony's latest patent describes a server that solves that problem one step at a time, picking the most efficient waypoint it can reach without crossing another robot's path.
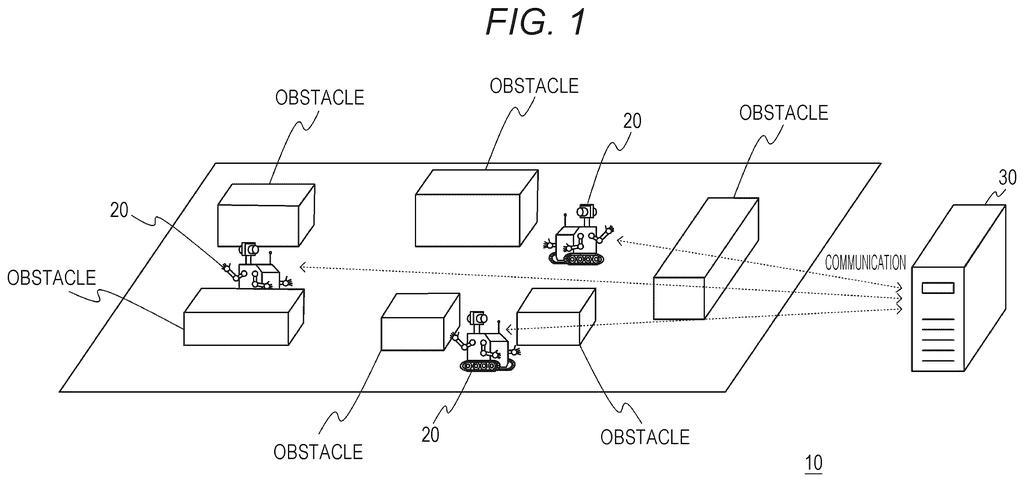
How Sony's server guides robots step by step
Imagine a busy warehouse where dozens of robots are all trying to reach different shelves at the same time. They can't just take the shortest route, because another robot might already be moving through that space. The result is a lot of stopping, waiting, and wasted time.
Sony's patent describes a central server that plans each robot's path in short hops. Instead of plotting the whole route upfront, the server looks ahead and picks the most efficient point the robot can reach right now without cutting in front of another machine. Then it picks the next point, and so on, repeating until the robot arrives at its destination.
The approach is meant to keep the whole fleet moving as smoothly as possible, squeezing out idle time by continuously recalculating as the situation on the floor changes.
… determining a passing point having the highest moving efficiency within a non-interference range with other moving apparatuses in a moving direction from a track starting point of a moving apparatus toward a destination …
Translation: The server calculates the best checkpoint along the safest and most efficient route to avoid other robots.
How the server picks each passing point along the route
The system centers on a route and track planning unit running on a remote server. Rather than computing a complete path from start to finish in one pass, the server works iteratively through three repeating steps.
- Find the best passing point: From the robot's current position, the server identifies the point along the intended direction of travel that offers the highest "moving efficiency" while staying inside a non-interference range (a bubble of space that keeps the robot clear of other moving machines).
- Set the track segment: The server assigns a short path from the current position to that passing point.
- Advance the starting point: The current position is updated to that passing point, and the process repeats.
The loop continues until the passing point is the destination, at which point the full track plan is assembled and sent down to the robot over a communication link.
"Moving efficiency" is the core metric driving every choice. The patent doesn't fix a single definition for it, leaving the server free to optimize for speed, distance, energy, or some combination, depending on implementation.
What this means for warehouses and robot fleets
Warehouses, factories, and logistics hubs are adding mobile robots fast, and the hardest operational problem isn't getting one robot to its destination. It's getting fifty robots there without constant gridlock. A server-side approach means the planning intelligence stays central and updated, rather than each robot trying to negotiate its own path independently.
For you as a consumer, faster and less congested robot fleets translate directly to quicker order fulfillment. For the companies running those fleets, less idle time means lower operating costs. Sony's track record in robotics and sensing patents suggests this fits a broader push into the infrastructure behind autonomous machines, not just the machines themselves.
Sony's 24th filing we've tracked in Enterprise AI since May follows patents on rebuilding app interfaces and remote device repair.
Claim 1 was canceled, which is the first thing worth saying plainly: the broadest, most sweeping version of this patent is already off the table. What remains in the dependent claims is narrower, covering the specific iterative waypoint method the abstract describes.
That narrowness cuts both ways. A competitor building a robot routing system that picks waypoints differently, or calculates interference ranges by a different method, likely has a clear path around this. The patent does not appear to lock up the general idea of server-managed robot path planning.
What it does cover, specifically, is this hop-by-hop efficiency loop. If that particular loop turns out to be the right way to run dense robot fleets, the filing has real teeth. If better methods emerge, it's a historical record of one approach Sony tried.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
13 drawing sheets from US 2026/0277225 A1 · click any drawing to enlarge


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →