
Waymo Patents a System That Helps Self-Driving Cars Plan Pull-Overs Around Hidden Spots
When a self-driving car needs to pull over, the safest spot might be one it can't yet see. Waymo has filed a patent for a system that lets its vehicles slow down early for partially hidden parking spots, rather than either missing them or braking hard at the last second.
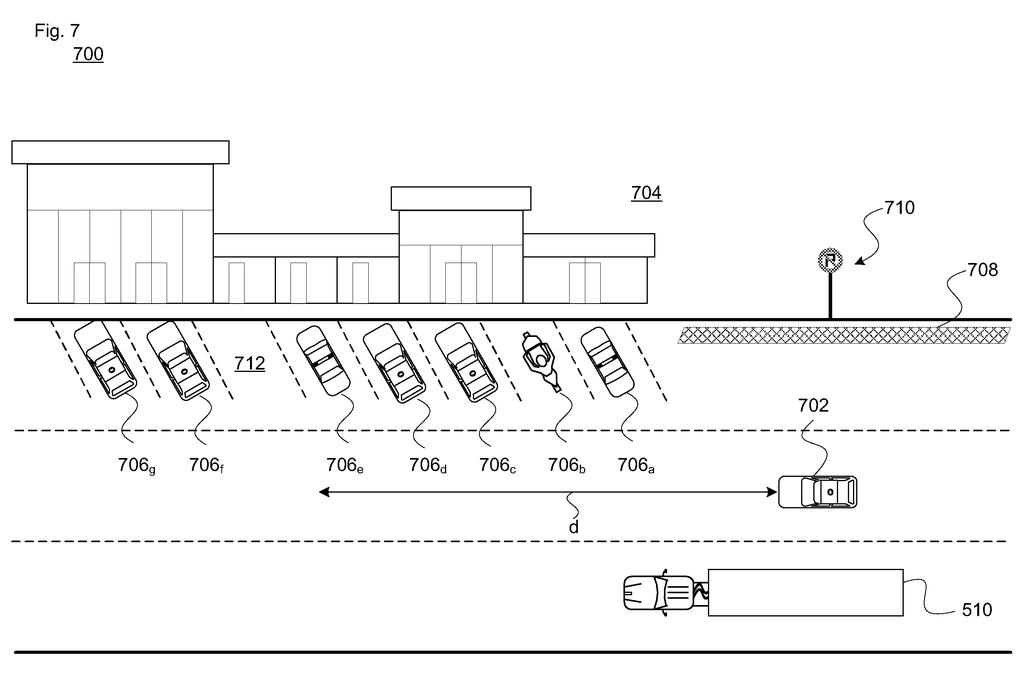
What Waymo's hidden-parking pull-over system actually does
Ever tried to turn into a parking spot only to realize too late that a truck was blocking your view of it the whole time? That split-second scramble, a sudden brake, a missed turn, is exactly what Waymo is trying to eliminate for its robotaxis.
The system described in this patent lets a self-driving car weigh the possibility of a hidden parking spot against the spots it can already see clearly. If the math says the hidden spot is probably the better option, the car starts slowing down before it even gets there, giving passengers a smooth ride and giving other drivers on the road a heads-up that something is about to happen.
The practical effect for you as a passenger: fewer jarring last-second stops, and less of that unnerving feeling that the car is improvising. The car has already thought it through.
determining, by one or more processors, a final offset based on a field of view restriction and a clearance offset to a side of a roadway, the field of view restriction corresponding to one or more occluded areas along the side of the roadway with respect to a vehicle …
Translation: The car calculates a safety buffer that accounts for blind spots beside the road.
How the car scores and compares occluded parking spots
The patent describes a two-part calculation the vehicle runs while approaching a potential pull-over zone.
First, the system figures out a final offset, which is essentially a best-case estimate of how much usable space might exist in an area the car cannot fully see. That estimate factors in the car's field of view restriction (how much of the roadside is blocked by parked vehicles, walls, or other obstructions) and a clearance offset (a safety buffer to the edge of the road). Think of it as the car making an educated guess about what is hiding around the corner.
Second, the system runs a cost comparison across all candidate pull-over spots:
- Visible spots are scored based on real measured data.
- The occluded (hidden) spot is scored based on the best-case estimate.
- Each score is compared to a baseline cost, a threshold representing the minimum acceptable pull-over quality.
If the hidden spot's best-case score beats every visible alternative, the car is authorized to adjust its speed proactively, slowing down so it can safely commit to that spot once it comes into view. The maneuver is only triggered if the occluded option is genuinely superior, not just a fallback.
A best case estimation for any potential parking locations, including partially or fully occluded areas, is compared against predictions for identified visible parking locations.
Translation: The system weighs hidden parking spots against clear ones to find the best option.
What this means for passengers and other drivers nearby
Pull-overs are one of the messier edges of autonomous driving. A car that hesitates or brakes hard at the last moment is uncomfortable for passengers and confusing for other drivers, who may not understand why the vehicle is slowing. This patent addresses both problems at once by moving the decision earlier in time.
Waymo's interest in edge-case maneuver planning shows up in a lot of their filings, and this one is a good example of why: the gap between a car that technically finds a spot and a car that pulls over gracefully is exactly the gap that determines whether riders trust the vehicle. Smoother pull-overs also reduce the chance of a rear-end collision from a following driver who didn't see a sudden stop coming.
Google's 55th filing we've tracked since May in our robotaxi sensing watchlist builds on ideas like avoiding icy roads and pre-planned gear shifts.
The real win lands in the passenger seat, not in the code. When a robotaxi slows down gradually before pulling over, rather than braking sharply at the last moment, the ride feels calm and deliberate. That sensation of being driven by someone who knows where they are going is easy to take for granted until it disappears.
The driver behind the robotaxi benefits too. A gradual, readable deceleration is something any driver can respond to safely. A sudden stop in urban traffic is a much harder problem, and preventing it is a quiet but meaningful public safety improvement.
What Waymo is solving here is a timing problem: getting the car to act on incomplete information early enough that its behavior stays predictable to everyone around it. Passengers will likely never know this logic exists, which is exactly how well-designed features tend to work.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
18 drawing sheets from US 2026/0287373 A1 · click any drawing to enlarge


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in