Waymo (Google)
Waymo (Google) · Automotive · Filed Apr 14, 2026 · USPTO published Aug 20, 2026 · Aug 20 release
Waymo Files Patent for Autonomous Cars That Navigate Around Sensor Blind Spots
Rain, fog, and glare don't just obscure your windshield view, they degrade the sensors a self-driving car depends on. Waymo's latest patent describes a system that maps exactly how much each sensor's vision is impaired and then changes how the car behaves accordingly.
- Publication number
- US 2026/0243892 A1(US20260243892A1)
- Applicant
- Waymo LLC
- Filed · Published
- Apr 14, 2026 · Aug 20, 2026
- Inventors
- Dmitri A. Dolgov, Christopher Paul Urmson
- Status when we published
- Waiting for an examiner
- Document
- 20 claims
- US classification
- 701/28
- Parent application
- Continuation of 18/346,486 (filed Jul 3, 2023)(18346486)
What Waymo's weather-aware sensor model actually does
Imagine you're in a Waymo robotaxi and a heavy rainstorm rolls in. The car's cameras and lasers can't see as far or as clearly as they normally do, but how does the car know that, and what should it do about it?
This patent describes a system that builds a 3D picture of what each sensor on the vehicle should be able to see under ideal conditions. When weather comes into play, the system adjusts that picture to reflect how much the rain, fog, or snow is cutting into each sensor's range. The car then combines all those adjusted sensor pictures into one big map of what's knowable and what's hidden. From there, it changes how it drives, slowing down, keeping more distance, or being more cautious around areas it simply can't see into well.
The key idea is that the car isn't just reacting to what it does see. It's also reasoning about what it can't see and making decisions based on that uncertainty.
… generating, by the computer, a model of a field of view of at least one sensor coupled to the vehicle, wherein the at least one sensor is configured to detect objects in the environment of the vehicle …
Translation: The car creates a digital map showing what its sensors are supposed to see.
How the 3D field-of-view model accounts for rain and fog
The patent describes a multi-step process for building a real-time model of a self-driving vehicle's perceptual limits.
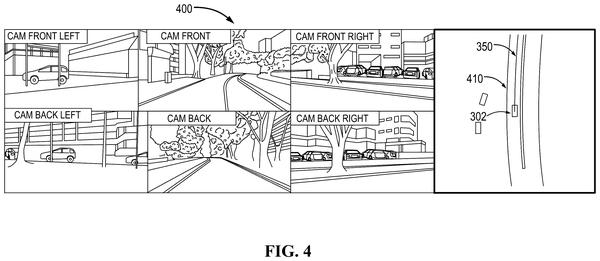
- Per-sensor 3D field-of-view models: For every sensor on the car (lidar, cameras, radar, etc.), the system generates an individual 3D model of what that sensor could detect if nothing were blocking it. Think of it as the sensor's theoretical "cone of vision."
- Weather adjustment: The system receives information about current weather conditions and uses it to shrink or distort each sensor's model. Heavy rain scatters lidar pulses; dense fog cuts camera range. The system applies those degradation factors mathematically to each model.
- Aggregation into a comprehensive model: All the adjusted per-sensor models are merged into one master 3D model of the vehicle's collective awareness, accounting for overlapping sensor coverage.
- Map integration: The comprehensive model is then combined with detailed map data that includes probability scores for detecting objects at specific locations, for example, a busy pedestrian crossing that statistically has a high chance of having someone in it.
The final output is a model of the vehicle's environment that tells the car not just what it currently sees, but how confident it can be about any given area around it. The vehicle's driving behavior is then modified based on that confidence map, becoming more conservative in zones where sensor coverage is poor.
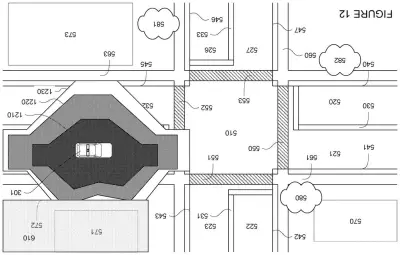
This view need not include what objects or features the vehicle is actually seeing, but rather those areas that the vehicle is able to observe using its sensors if the sensors were completely un-occluded.
Translation: Instead of tracking what is currently visible, the system maps areas that should be visible without blockages.
What this means for self-driving safety in bad weather
Bad weather is one of the hardest unsolved problems in autonomous driving. Most sensor systems can tell you what objects they detect; far fewer can tell you how much the weather has degraded their ability to detect objects in the first place. A car that doesn't know its sensors are impaired can't compensate for that impairment, which is precisely the scenario that leads to dangerous outcomes.
This patent tries to close that gap by making sensor limitation a first-class input into driving decisions, not an afterthought. For anyone riding in or near an autonomous vehicle on a rainy highway, that distinction matters. The approach is also notable for tying probabilistic map data into the model, so the car can weigh its degraded sensor coverage against prior knowledge about where people or other cars are likely to be. Autonomous vehicle safety is one of the more closely watched areas of Big Tech patent news, and this filing reflects how much engineering effort goes into the edge cases most human drivers handle instinctively.
Google's 49th filing we've tracked since May in our self-driving sensor competition follows work on backup braking systems and virtual street-view angles.
Source: US 2026/0243892 A1 at the USPTO (PDF). Full patent text and figures are in the official publication.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Google patent news breaks.
Add Patentlyze on Google
One click.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
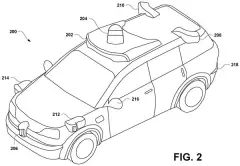
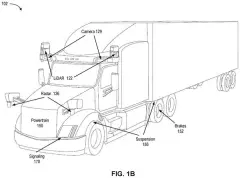
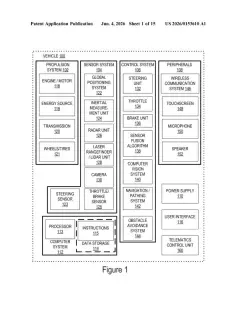
The drawings · 15 sheets
15 drawing sheets from US 2026/0243892 A1 · click any drawing to enlarge


Show the other 7 sheets


More from Google
All 1,127 Google patents →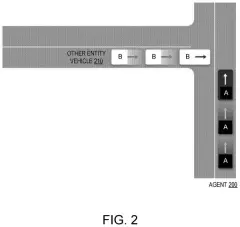
More in Automotive
All 377 Automotive patents →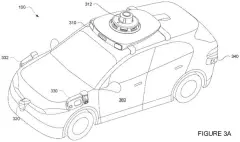
Waymo (Google)
Google Patent Reveals Robotaxi Sensors That Self-Diagnose Vision Loss in Bad Weather
Waymo (Google)
Waymo Patents a Way to Stop Its Robotaxis From Drowning Out Each Other's Radar
Waymo (Google)
Waymo Patents a Dual-Brain Fallback System for When Its Robotaxis Break Mid-Drive
Waymo (Google)