
IBM
IBM · Robotics · Filed May 7, 2025 · USPTO published Nov 12, 2026 · This week's release
IBM Wins a Patent for Robots That Get Rebuilt to Fit the Job
IBM has been granted a patent for a system that does more than pick robots for a job. It predicts where they will break, then has a fabrication machine rebuild them before they leave.
- Publication number
- US 2026/0355953 A1(US20260355953A1)
- Applicant
- International Business Machines Corporation
- Filed · Published
- May 7, 2025 · Nov 12, 2026
- Inventors
- Sarbajit Kumar Rakshit, Sudheesh S. Kairali, Binoy Thomas
- Status when we published
- Granted
- Document
- 20 claims
- US classification
- 700/250
- Examiner
- NGUYEN, BAO LONG T (Art Unit 3656)
What IBM's robot-team patent actually does
Every time a crew needs a robot for a messy outdoor job, like collecting dirt samples at a mining site, someone has to guess which machines can handle it. Guess wrong and a robot gets stuck on rocks, or an arm gives out under strain.
IBM has been granted a patent for a computer system that makes that guess for you. It studies the site, checks how each available robot is built, and picks a team. Then it predicts where that team will fail and orders fixes before the robots head out.
The fixes are physical. The system can have a machine add material to a weak part, trim an arm that is too long for tight spaces, or build a missing piece, like a wheel mechanism, from scratch.
… predicting, by the computer, one or more vulnerabilities associated with an execution of the at least one activity by the set of robots, wherein the one or more vulnerabilities are predicted based on the one or more robotic parameters and the plurality of activity parameters; …
Translation: The system figures out where the chosen robots might fail at the job.
How IBM tests, rebuilds and couples robots
The system starts with data about the job. Sensors such as cameras, LiDAR (laser-based distance sensing) and air-quality sensors capture how rough, steep or slippery the ground is, plus temperature and air conditions. From that it works out the job's requirements and risks, like obstacles or weak connection points.
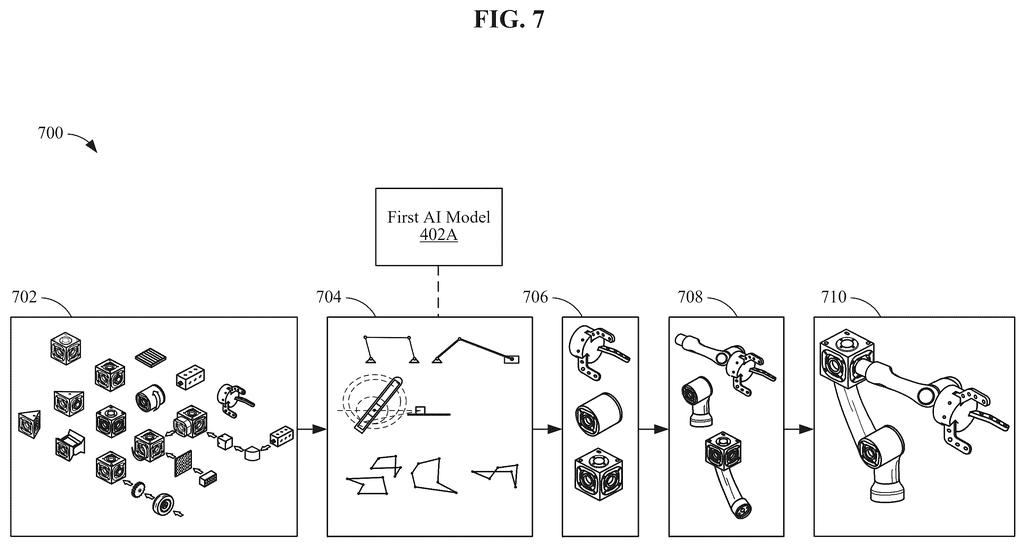
Next it reads the specs of each available robot: how many joints and actuators (the motors that turn electricity into movement) it has, its sensors, and how its weight is spread. An AI model builds a digital twin (a virtual copy) of the robots and runs combinations through a simulated version of the site, with gravity and friction included, to choose the team.
Then it predicts vulnerabilities, such as joints that could fail, rigid connections that limit movement, or sharp pinch points. It issues a modification command, and a fabrication unit (3D printers, welders or laser cutters) adds or removes material. In one example, it thickens an earth-digging mechanism and lengthens its arm by 5 centimeters.
Finally it assembles and drives the team:
- Robots are joined with clamps, brackets, hinges, magnets or hydraulic connectors, with an AI model working out each robot's range of motion and degrees of freedom (the number of independent ways it can move).
- A third AI model plans a smooth path and updates it if, say, a rock appears.
- If simulation shows no team can do the job, the system can fabricate a custom robot.
A modification command is generated to control the one or more modifications in the set of robots.
Translation: Instructions are then created to physically alter the robots so they fit the task.
Why IBM's pre-job robot repairs matter
If you send machines into rough places like mines, construction sites or farms, the practical payoff is fewer failed jobs. Testing combinations in simulation costs almost nothing, while a robot that overheats in 60 degree Celsius air or snaps a joint midway costs real time and money. Catching those weak spots before deployment is the whole pitch.
It is already a granted patent, though the final granted claims may read a little differently from the published application described here. The filing names no product, and it describes a planning system plus a fabrication step. Any real use would depend on robots that can physically couple together and on a machine shop that takes orders from the software.
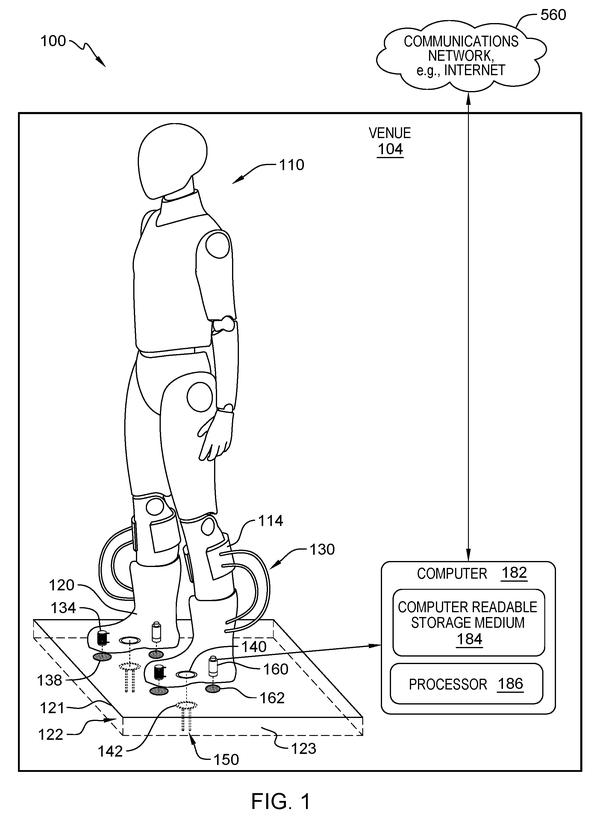
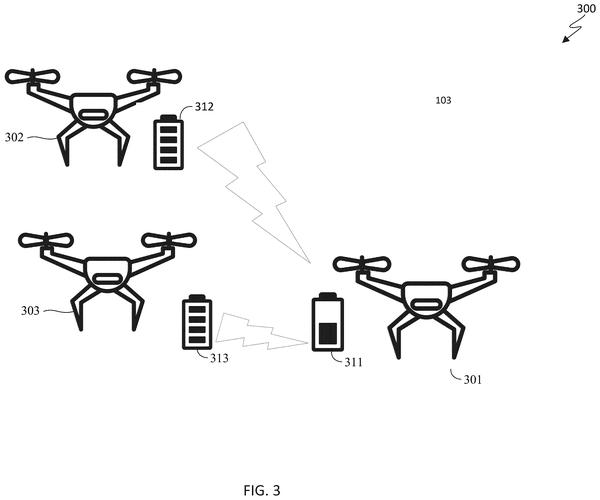
IBM's tenth patent we've tracked since May in our robotics coverage follows ideas like one on floor charging for humanoid robots and one on drones sharing battery power.
Source: US 2026/0355953 A1 at the USPTO (PDF). Full patent text and figures are in the official publication.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time IBM patent news breaks.
Add Patentlyze on Google
One click.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings · 9 sheets
9 drawing sheets from US 2026/0355953 A1 · click any drawing to enlarge


Show the other 1 sheets


No comments yet