
Google Files Patent for Cars That Notice When Road Construction Moves the Lane Lines
Google's patent turns ordinary cars with cameras into lane-line watchers that notice when construction shifts the paint, then tells the map to forget the old version.
What Google's lane-marker patent actually does
Ever trusted your navigation app, only to find the lanes on the road no longer match what's on the screen? That happens because the map still remembers how the road used to be painted.
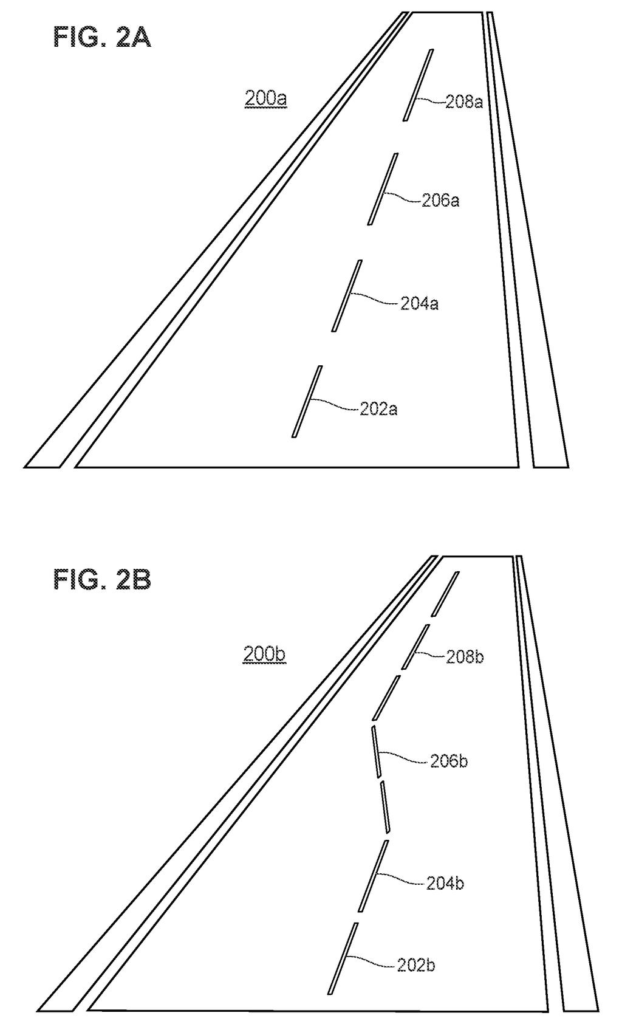
Google's patent describes a fix. Cars with cameras spot lane lines as they drive and send a report to a server, each one stamped with a place and a time. The server compares those reports with the lane lines the map has on file. When lots of reports from the same spot, in the same stretch of time, disagree with the map by a wide margin, the system decides the lines have moved and throws out the old data for that spot.
There is a privacy rule too. A change is only reported once enough different vehicles have seen it, so no single car's trip can be picked out of the data.
The computing device identifies relationships between the data points according to the error metric for each data point, a time when each data point was collected, or a location of each data point, and identifies a lane marker change event occurring within the geographic area based on the relationships between the data points.
Translation: The system analyzes reports from multiple cars over time and location to figure out that a lane has actually been moved.
How cars and servers spot a moved lane line
Each vehicle takes camera pictures of the road and looks for stable regions, spots in the image (such as high-contrast edges) that stay recognizable despite blur, glare or a changing angle. It turns those into numerical features and compares them with template images of lane markers using machine learning (software that learns patterns from examples). When it finds a match, the car works out where the marker sits using its pixel position in the image, the image's scale and the camera's height off the ground. It then sends that position, plus the time the photo was taken, to a server.
The description lays out what the server does next:
- It compares each reported patch of road (one example is a square about one square meter) with the lane lines stored in its map database, and scores the gap using root mean square error (a standard way of averaging how far off a set of points is).
- It bundles that score with the patch's location and collection time into one data point, then groups the points with a clustering method (software that finds points sitting close together).
- A group of high-error points that are near each other in place and time counts as a lane marker change event. The example uses an error threshold of 8 and a cutoff of 5 days.
The server then discards the old lane data for that area, and the claims also cover cars receiving updated map data that leaves it out. The description adds that no change is reported unless enough different vehicles saw it that no single car can be identified.
Why stale lane data matters for navigation
Lane-by-lane directions only work if the map knows where the lanes really are. The filing says that when a lane is added or shifted, the map pieces from before the change no longer line up with the ones from after, and the stored lane lines turn wrong. For you, that could mean fewer moments where an app or a car tells you to use a lane that has vanished. The filing names driverless navigation as one use.
Because the reports come from vehicles already driving the roads, the map can notice changes as they happen. The filing's stated aim is that outdated lane data is discarded right away, so drivers and driverless cars are not left relying on it.
Google's 73rd filing we've tracked since May in our self-driving sensing race watch adds to work like one on grading routes and one on ignoring sensor glitches.
Privacy rules mean a change only counts once enough different cars have seen it, so a lane shift on a quiet road could sit unflagged for weeks while a busy highway gets fixed the same day.
Once the system discards old lane data, that spot on the map goes blank until fresh reports accumulate. A blank is more honest than a wrong answer, and that trade reads as worth it.
The error threshold is the design's sharpest edge: set it too sensitive and a faded stripe triggers a false alarm that wipes good data, set it too loose and real construction slips through unnoticed. The filing offers example numbers but no guarantee of where that dial lands in the real world, which is where the whole system either earns its keep or fails.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Google patent news breaks.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
5 drawing sheets from US 2026/0351015 A1 · click any drawing to enlarge


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in