
Nvidia Files Patent for Multiplying Rare Road Situations to Train Self-Driving Cars
A truck blocks your view, a pedestrian steps out, and the driving software has never seen that exact moment. Nvidia's patent application describes how to manufacture that moment, and thousands like it, by changing speeds, gaps and weather.
What Nvidia's driving-scenario library does
Every time you roll past a row of parked trucks, there's a small chance someone steps out from between them, and you can't see it coming. Self-driving software has to be ready for that moment, and for thousands of other rare ones, but real roads only hand it a few examples.
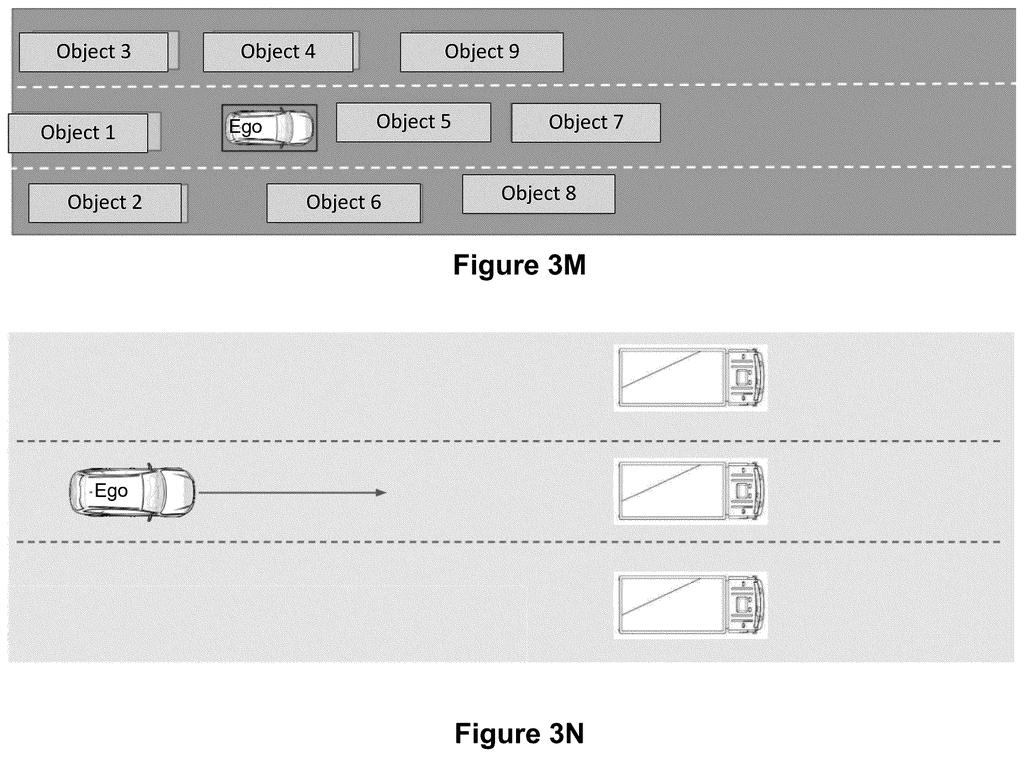
Nvidia's patent application describes a way to multiply those examples. Start with a basic situation, such as one car cutting in front of another, then change the numbers: how fast each vehicle is moving, how far apart they are, whether it's raining or dark, even what kind of vehicle is involved. Each tweak becomes a new practice scenario.
The raw material can come from recorded drives, the car's own sensors, or footage that people have labeled by hand. The result is a big library of situations used to teach driving software what to do.
… defining a scenario that includes at least one interaction between the one or more agent machines and the ego machine in the environment, the at least one interaction including one or more of relative speed, relative distance, or relative acceleration between the ego machine and a respective one of the one or more agent machines …
Translation: It maps out how the self-driving car and other vehicles move and interact around each other.
How Nvidia turns one road scene into thousands
The core claim is a method for describing driving situations as data. The software takes information about other vehicles (the filing calls them agent machines): their paths, their types, and their speed and acceleration. It takes the same details for the ego machine, which is the vehicle being trained, plus the distance between them. From that, it defines a scenario built around an interaction, such as relative speed, relative distance, or relative acceleration, and records data describing that interaction.
Other claims cover the multiplying step: change the numbers, change the vehicle types, or add occlusions (things that block the car's view, like a parked truck hiding a pedestrian) to get more scenarios. The claims also list stock situations:
- A car cutting in front of the ego vehicle
- A vehicle ahead braking hard
- A motorcycle overtaking a heavier truck
- Stop-and-go traffic with three to nine vehicles nearby
- A pedestrian or bicycle crossing from behind a blocking vehicle
Under the hood, the description says a unified data interface pulls recorded data from a cloud database and caches it so repeat searches run faster. Data can come from offline tracking, the car's live sensors, or human-labeled footage. Chains of filters, crops and merges trim recordings down to the useful stretch. The filing says vision-language models (AI that describes images in words) usually get speed and distance wrong, and this adds those numbers back.
… varying parameters of relative movement between an ego machine and the agent machines, and varying parameters of surface and weather conditions, and traffic conditions, it is possible to create many more sophisticated scenarios than has been possible with prior approaches …
Translation: By changing how vehicles, weather, and traffic interact, the system can generate complex training situations.
Why hidden-pedestrian drills matter for AI drivers
For you, this is about the rare moments that decide whether a self-driving or driver-assist system handles a surprise. Rare cases are hard to collect from real driving, so building them by changing speeds, gaps, weather and lighting is a way to practice them far more often. The filing singles out hidden pedestrians and cyclists.
The filing also describes use in robots, drones and boats, and it names Nvidia's Drive Sim and Isaac Sim tools. The examiner's first review rejected the claims as filed, which is routine at this stage and usually followed by amendments, so the final scope may shrink.
Nvidia's 92nd filing we've tracked since May, after one on learning traffic from cameras and one on filling in hidden objects, adds another piece to the self-driving sensing race.
Every shortcut has a price. Scenarios built by tweaking numbers on a recorded scene are only as varied as the scenes you started with. A hidden-pedestrian case multiplied a thousand times still teaches one lesson a thousand ways, and a truly strange event may never appear in the library.
The design also leans on human labeling for its most exact data, and people are slower and costlier than software. Each extra hand-checked clip trades speed for trust. The number of possible combinations grows fast too, which means more computing to generate and train on them.
The trade reads as worth it, because a wrong guess about a pedestrian's distance is expensive on a real road. Still, the claims are broad and basic, and the real value will sit in how good the finished library is, which a patent text cannot show.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Nvidia patent news breaks.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
25 drawing sheets from US 2026/0316792 A1 · click any drawing to enlarge


Show the other 17 sheets


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in