
Qualcomm Files Patent to Speed Up Turning Phone Photos Into 3D Scenes
Qualcomm's new patent application goes after a stubborn flaw in photo-to-3D tools: blank walls and one-sided photo shoots make rooms look wrong from new angles. Its fix is to start from a depth-based skin of triangles instead of a guess.
What Qualcomm's triangle-first 3D capture does
Right now, one popular way to turn photos into a 3D scene you can look around in starts by guessing where things sit in space from the pictures alone. That guess gets shaky on blank walls and flat surfaces, and when you only shot the room from one side. View the result from a new angle, like straight above, and the walls and bed look wrong.
Qualcomm's patent application skips the guessing. If your device has depth readings, it combines them with the camera's position to build a triangle mesh, a skin of tiny flat tiles that follows the walls, floors and furniture. It then lays one small blob of color on each tile and tunes those blobs against your real photos.
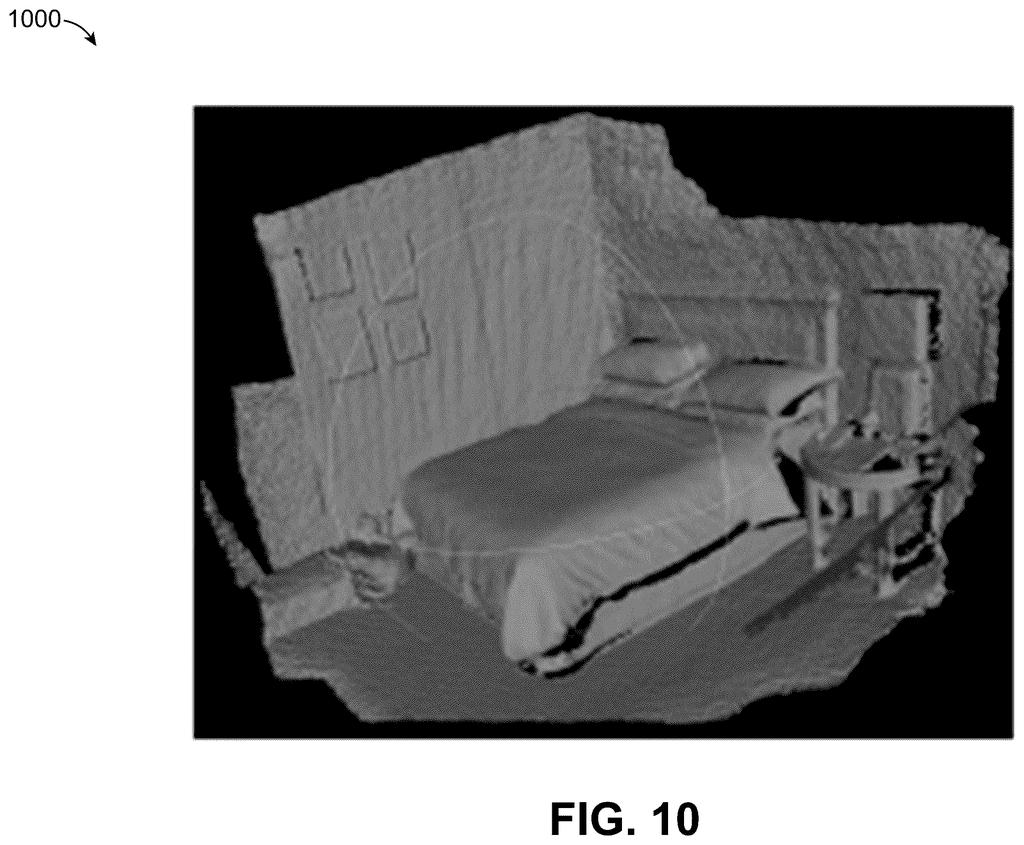
Because the starting point is already close, the system has less to learn. Qualcomm's own comparison images show realistic results after 7,000 training rounds, where the older approach ran 30,000 rounds and still looked off from new angles.
generate, based on image sensor pose information and depth information of a plurality of views of a scene, a three dimensional (3D) mesh of the scene; initialize a Gaussian splatting model based on the 3D mesh of the scene …
Translation: It builds an initial 3D wireframe from camera angles and depth data before applying advanced rendering.
How depth readings seed the 3D blobs
Claim 1 covers a four-step loop. First, a processor builds a 3D mesh (a skin made of tiny triangles that follows every wall, floor and piece of furniture) from the camera's position at each shot and the depth readings from those shots. Second, it sets up a Gaussian splatting model, a scene made of thousands of soft, colored blobs (called splats) that blend into a picture, using the mesh as the starting layout.
Third, it renders pictures from that model and compares them with the real photos. Fourth, it nudges each blob's settings to shrink the difference. That is ordinary training: repeated trial and error guided by an error score.
The dependent claims add shortcuts:
- One blob goes on each triangle, and the mesh can be thinned out first by sampling or merging triangles.
- Each blob is flattened into a disc by setting its thickness, along the direction the triangle faces, to zero.
- Opacity (how see-through a blob is) is locked to a fixed value, such as zero or one in the description, when the mesh says a surface is opaque or transparent.
The description adds that when the depth data is reliable, blob positions and orientations can also be frozen, leaving mostly color to learn. It says whether to freeze opacity depends on how good the 3D reconstruction is.
… update, based on a difference between the rendered images of the scene and images of the scene captured by an image sensor, one or more parameters of the parameters of the Gaussian splatting model.
Translation: The system refines the 3D model by constantly comparing its generated pictures to the actual camera shots until they match.
Why phone-based 3D scanning could get cheaper
If you want a 3D copy of your living room for a headset, a game or a shared virtual space, today's method needs a lot of computing and a good spread of photos. A phone that can do the heavy lifting in fewer training rounds uses less battery and makes less heat, which is the problem Qualcomm's background section names directly. A mesh that handles blank walls also fixes the spots people notice first.
Qualcomm sells the chips inside many phones and headsets, so a faster recipe for 3D capture on the device itself fits its business. The examiner's first review rejected the claims as filed, which is routine at this stage and usually followed by amendments.
Qualcomm's 536th filing in our Qualcomm coverage since May adds to a camera push that includes re-angling photos after capture and keeping zoom sharp on low power.
The part of this filing closest to shipping is the part that needs no new hardware. It is a software recipe: build a surface skin from depth readings and camera positions, then train on top of it. Phones already track their own position and many already measure depth, and the filing says depth maps can also come from AI estimates.
The shortest route to a product is a room-scanning feature that runs on the phone itself, which is where Qualcomm says the savings matter, since less training means less heat and battery drain. What has to exist first is a reliable mesh builder. The filing admits its shortcuts, like locking positions and skipping opacity, only make sense when the depth data is good.
The evidence is thin. The only proof shown is a handful of comparison pictures of an indoor room, and the speedup is counted in training rounds rather than minutes or battery use. It reads as a credible engineering shortcut that still needs real-world testing, with a path to a product that is mostly software work.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Qualcomm patent news breaks.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
15 drawing sheets from US 2026/0330751 A1 · click any drawing to enlarge


Show the other 7 sheets


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in