
Zoox Patents a System That Maps and Weighs Every Possible Self-Driving Car Decision
Every time a self-driving car approaches a tricky intersection, it has to pick one path from thousands of possibilities in a fraction of a second. Zoox is patenting a system that maps out those possibilities like a game tree, then uses AI to prune it down to the one that's actually safe.
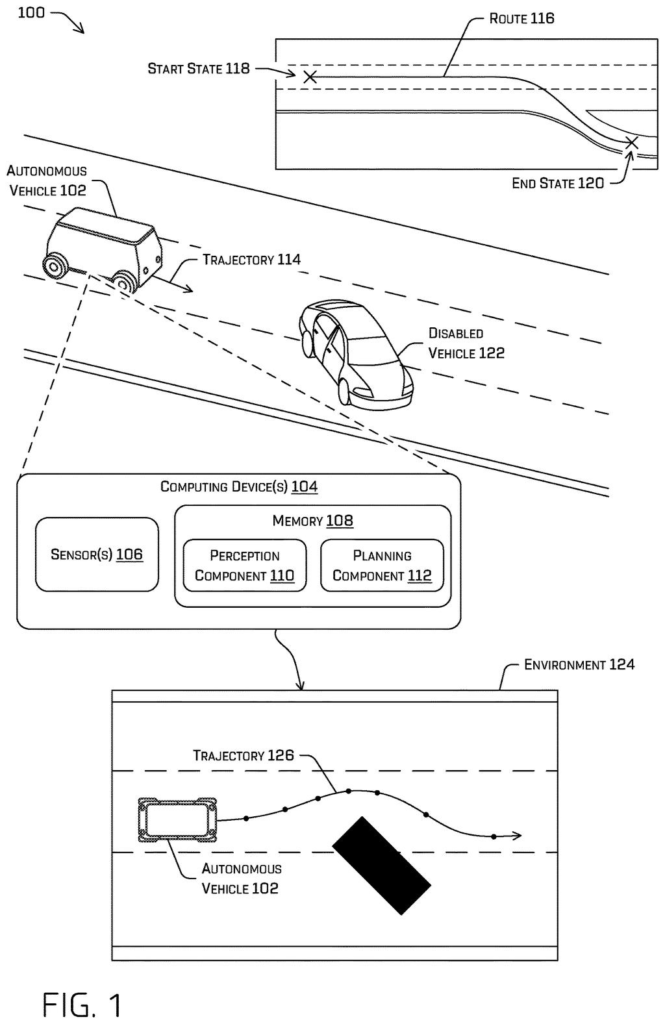
How Zoox's self-driving car picks its next move
Self-driving cars face a genuine planning problem: the road ahead can branch in dozens of directions depending on what every other driver, cyclist, and pedestrian decides to do next. Today's systems often rely on a fixed set of rules to navigate that complexity, which works fine in predictable conditions but can break down when traffic gets weird.
Zoox's approach adds a second layer. The car still uses its preset rules, but it also runs a machine learning model that watches the live scene and suggests additional moves the rules alone might not have considered. Those options get laid out in a branching structure (imagine a flowchart of every choice the car could make over the next several seconds), and a cost score gets attached to each branch based on how safe and efficient that path looks.
The car then picks the branch with the best score and drives it. The whole process repeats continuously, so your route gets recalculated on the fly as other vehicles move and conditions change. You'd notice this working not as a fancy feature, but as the absence of hesitation or jerky corrections at complex intersections.
… generating, using the machine learned model, a candidate action for controlling motion of a vehicle in the environment; determining, based at least in part on the candidate action and a technique, a trajectory for controlling the vehicle …
Translation: The artificial intelligence proposes possible driving moves and figures out a path for the vehicle.
How the tree search blends rules with AI predictions
The system frames the driving problem as a tree search, a technique borrowed from game AI where every possible sequence of moves gets mapped out before the best one is chosen. Each node in the tree represents the car's state at a moment in time; each branch represents a candidate action, such as accelerating, yielding, or changing lanes.
What makes this patent distinct is how the candidate actions are generated. The system draws from two sources:
- Heuristic actions: predefined rules (essentially the car's built-in playbook) that cover common scenarios.
- ML-generated actions: outputs from a machine learned model that observes the current environment and proposes moves the rulebook might not cover.
Each candidate path gets scored using state transition costs (how risky or inefficient is this immediate move?) and future state predictions (what does the environment probably look like several seconds from now if the car takes this path?). The search algorithm explores the tree, weights those costs, and selects the trajectory with the lowest combined score.
The vehicle is then controlled directly from that trajectory. Because the process runs continuously, the tree gets rebuilt at each planning cycle, so the system adapts as the environment evolves rather than committing to a plan made seconds ago.
… a search algorithm may be used to determine and evaluate a set of possible candidate actions for a vehicle, including candidate actions based on a predetermined exploration policy and additional candidate actions based on machine learned models …
Translation: The car weighs rule based driving options alongside choices generated by machine learning models.
What better path-picking means for robotaxi passengers
For a passenger, the payoff is a ride that handles surprises without flinching. A car that can only follow preset rules will sometimes freeze up or make overly cautious moves when a situation falls outside its playbook. A system that also asks "what does the AI think I should try here?" has more options to choose from, which means fewer awkward pauses and smoother handling of edge cases like double-parked delivery trucks or unusually aggressive merges.
Zoox keeps filing around autonomous planning at a time when proving safety and reliability is the central competitive challenge for robotaxi operators. A more thorough path-selection process directly reduces the failure modes that erode passenger trust, and that matters whether your fleet has ten cars or ten thousand.
Amazon's new filing is the 30th we've tracked since May in our self-driving sensing race watchlist, joining earlier Zoox work like a two-track steering system and a robot car road-confusion warning.
The moment this system earns its keep is when something unexpected happens in front of you: a cyclist swerving, a car door opening, a pedestrian stepping off the curb. Instead of reacting to just one planned path, the car has already weighed dozens of possible responses and picked the one that costs least in risk and discomfort.
What passengers will actually feel, or not feel, is the difference between a smooth correction and a lurch. The system is specifically designed to catch those moments before they become corrections you notice.
The real question is how well the car defines "safe" in its scoring, because that judgment call shapes every decision. Get it right and the ride feels calm and confident. Get it wrong and no amount of calculation underneath changes what you feel in your seat.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
12 drawing sheets from US 2026/0296419 A1 · click any drawing to enlarge


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in