Nvidia
Nvidia · AI / ML · Filed May 27, 2025 · USPTO published Aug 20, 2026 · Aug 20 release
Nvidia Patents a Single AI Model That Controls Any Type of Robot
Teaching a robot to walk is hard enough. Teaching one AI model to walk a humanoid, trot a four-legged dog-bot, and roll a wheeled cart is a different problem entirely. Nvidia's new patent describes a system that tries to do exactly that.
- Publication number
- US 2026/0241554 A1(US20260241554A1)
- Applicant
- NVIDIA Corporation
- Filed · Published
- May 27, 2025 · Aug 20, 2026
- Inventors
- Wei LIU, Huihua ZHAO, Yan CHANG, Chenran LI
- Status when we published
- Examiner raised objections; the company can respond
- Document
- 20 claims
- US classification
- 700/245
- Examiner
- MOYER, DALE S (Art Unit 3656)
- Parent application
- Claims priority from a provisional application 63759693 (filed Feb 18, 2025)
How Nvidia's one-model robot brain handles different bodies
Today, robots that look and move differently typically need separate AI programs to control them. A humanoid walking on two legs and a four-wheeled warehouse cart have almost nothing in common physically, so their software has been trained separately from the ground up.
Nvidia's patent describes a single AI model that can control multiple robot body types at once. You tell the model what kind of robot it's dealing with (a humanoid, a quadruped, a wheeled vehicle), give it the robot's current position and where it needs to go, and the model figures out what movements to send. The key trick is that it was trained on several body-specific models first, then compressed into one general model that can mimic what each specialist would have done.
For people building robots, this could mean less time maintaining a separate AI for every robot design in a fleet. One model, many bodies.
… generate, based at least on a generalist action policy processing the state and the identifier, at least one action for the robot, wherein the generalist action policy was generated using a combination of a base action policy corresponding to the plurality of types of robots and one or more specialist action policies individually corresponding to different robot types …
Translation: The system creates movement commands by combining a core AI model with specialized models built for specific robot designs.
How the generalist policy blends specialist robot models
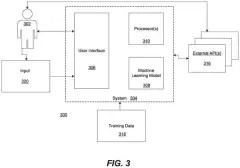
The patent centers on what Nvidia calls a generalizable mobility model: a single neural network that accepts two inputs alongside its navigation goal. The first input is the robot's state (its current joint positions, orientation, and surroundings). The second is an identifier, essentially a label that says 'this robot is a humanoid' or 'this robot is a quadruped.'
The model was built through a process called knowledge distillation (think of it as cramming multiple specialists' expertise into one generalist). Nvidia first trains separate specialist action policies for each robot type. Those specialists are then used as teachers to train a single generalist action policy that learns to mimic what each specialist would output when given the right type identifier.
At runtime, the generalist policy receives the type label and produces motor commands specific to that body. The system also references a base action policy that covers behaviors shared across all robot types, which keeps the generalist from having to relearn common locomotion fundamentals for every new robot.
- State input: position, environment data, and navigation target
- Identifier input: robot type label (humanoid, quadruped, wheeled, etc.)
- Output: motor actions appropriate to that specific body type
- Training: distilled from type-specific specialist models into one generalist
The generalizable mobility model can be a distilled combination of multiple robot type-specific models, and can use the identifier to mimic type-specific actions output by the multiple robot type-specific models to transmit to the robot to move the robot.
Translation: The AI learns to act like many different expert robot programs so it can control any machine.
What one universal robot model means for real deployments
For robotics teams managing a mixed fleet, maintaining separate AI models for each robot design is expensive and slow. Every time you update the movement logic for one robot, you may need to retrain or re-test all the others. A single shared model that adapts based on a type label cuts that overhead significantly, and it makes adding a new robot body type a matter of fine-tuning one model rather than building from scratch.
The broader bet here is that robot locomotion can be treated more like a general skill than a body-specific craft. Whether that holds as robots take on more varied physical forms is an open question, and a single model may sacrifice some peak performance on any one body type to cover all of them. That tradeoff runs through a lot of the interesting tech patents coming out of the robotics and embodied AI space right now, where generalization and specialization are constantly being weighed against each other.
Nvidia's 27th filing we've tracked since May in our robot grasping and movement work follows an AI grading system and object orientation detection with a new application in the same space.
Source: US 2026/0241554 A1 at the USPTO (PDF). Full patent text and figures are in the official publication.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Nvidia patent news breaks.
Add Patentlyze on Google
One click.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings · 28 sheets
28 drawing sheets from US 2026/0241554 A1 · click any drawing to enlarge


Show the other 20 sheets


More from Nvidia
All 665 Nvidia patents →
More in AI assistant & agent
All 436 AI assistant & agent patents →
Intel
Intel Patents a System That Rewrites a Robot's Movement Plan Mid-Task
Samsung
Samsung's New Patent Teaches Home Robots to Fix Their Own Failed Plans
OpenAI
OpenAI Patents a Way for Its AI to Call Outside Tools Without Being Programmed to Do So
Microsoft