
Sony Patents a System That Checks Whether a Robot's Planned Path Is Actually Safe
Before a robot takes a single step toward its destination, Sony's new patent wants it to stop and ask: is this route actually safe? The answer depends on how nearby objects are grouped and where those groups sit relative to the planned path.
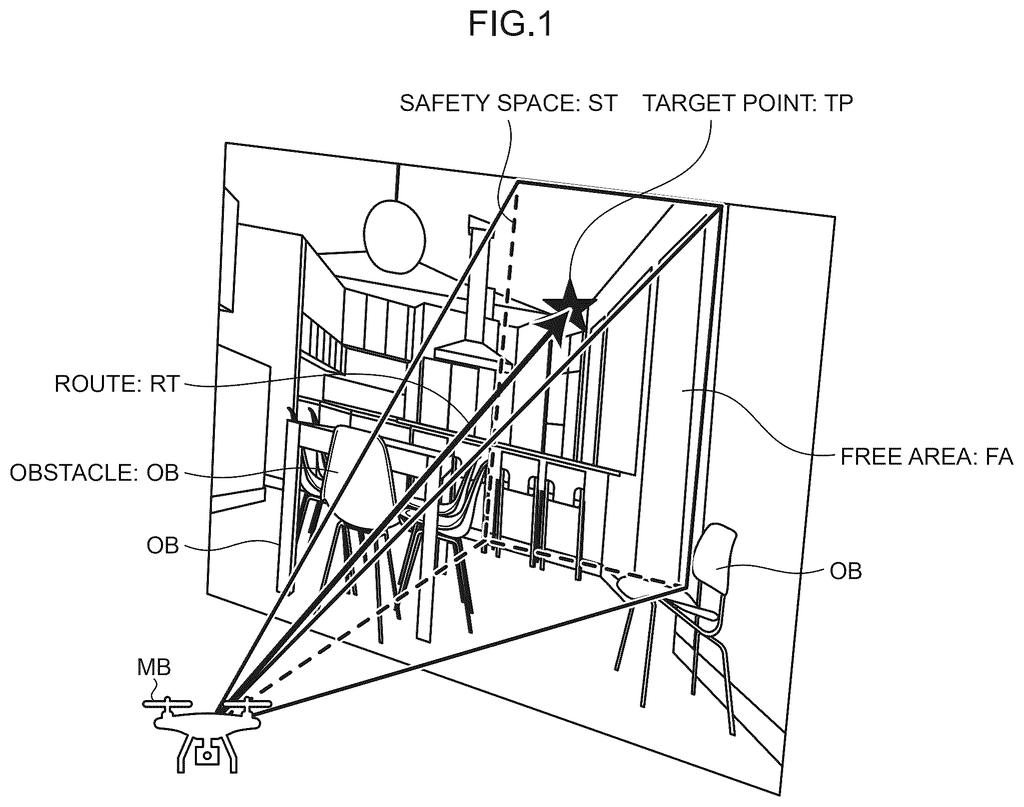
What Sony's obstacle-aware route check actually does
Every time a robot or delivery drone picks a path to its destination, it has to figure out what's in the way. Most of the time that works fine, but the tricky part is knowing whether something that isn't quite blocking the path is still close enough to be dangerous.
Sony's filing describes a method where the device first maps nearby objects by grouping sensor readings into clusters, then checks how those clusters are distributed to identify real obstacles, and finally scores the planned route based on how close those obstacles are. Think of it like a navigator that doesn't just check whether the road is blocked, but also flags a route that passes uncomfortably close to a parked truck.
The goal is to give mobile machines, whether robots, drones, or autonomous vehicles, a way to judge route safety before committing to movement, rather than reacting only after something is already in the way.
calculating a route of a mobile body to a target point; detecting an obstacle based on a distribution of a cluster group indicating a surrounding object; and evaluating safety of the route based on a positional relationship between the obstacle and the route.
Translation: The system plots a path, spots nearby objects, and checks if the route is safe.
How the system maps clusters into obstacles and scores the path
The patent describes three linked steps that run on a computer controlling a mobile device.
First, a route calculation step figures out a path from the device's current position to a target point. This is standard navigation, nothing unusual yet.
Second, a cluster-based obstacle detection step processes sensor data. Instead of treating every sensor reading individually, it groups nearby readings into clusters (think of a cluster as a blob representing one object, like a chair leg or a person's ankle). The system then looks at how those clusters are distributed in space to decide which ones represent actual obstacles worth worrying about.
Third, an evaluation step scores the safety of the route by checking the positional relationship between those detected obstacles and the planned path. If an obstacle sits too close to the route, even if it doesn't technically intersect it, the route gets flagged as less safe.
Together these three steps create a feedback loop: plan a route, check what's around it, decide whether that route is acceptable before moving.
What this means for robots moving around people
For anyone sharing a space with a robot, whether in a warehouse, a hotel corridor, or eventually a home, this kind of pre-movement safety check is the difference between a machine that avoids you predictably and one that only stops when it's already too close.
The practical payoff is a robot that treats proximity as a risk, not just direct collision. That's a more conservative and human-friendly way to operate. Sony's string of mobile-robotics filings shows the company is building out the safety layer of autonomous movement piece by piece, which matters more than any single flashy capability.
Sony's tenth robotics filing we've tracked since May follows work like the adaptive arm and the self-correcting hand.
The concept here is straightforward: check whether a path is safe before taking it, using grouped sensor data rather than raw point-by-point readings. That's a sensible engineering choice, because real environments are messy and objects rarely show up as neat single points.
From a reader's perspective, the payoff is subtle but real. A robot that pre-evaluates route safety is less likely to drift uncomfortably close to you, your pet, or your furniture. You'd notice the absence of near-misses rather than any visible feature.
The filing is light on specifics about how clusters are defined, what thresholds mark a route as unsafe, or how the system handles moving obstacles. Those details matter a lot in practice, and their absence makes this read as an early-stage or broad claim rather than a finished system.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Sony patent news breaks.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
19 drawing sheets from US 2026/0277229 A1 · click any drawing to enlarge


Show the other 11 sheets


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in