Sony
Sony · Robotics · Filed Sep 30, 2025 · USPTO published Aug 20, 2026 · Aug 20 release
Sony Patents a Two-Layer Artificial Skin That Gives Robots a Better Sense of Touch
Sony is working on an artificial skin for robots that uses two different materials layered together, one soft and one firmer, so a robot can feel where and how hard something is pressing on it.
- Publication number
- US 2026/0243614 A1(US20260243614A1)
- Applicant
- SONY GROUP CORPORATION
- Filed · Published
- Sep 30, 2025 · Aug 20, 2026
- Inventors
- KEI TSUKAMOTO, KEN KOBAYASHI, YOSHIAKI SAKAKURA
- Status when we published
- Waiting for an examiner
- Document
- 11 claims
- US classification
- 73/862.626
- Parent application
- National Stage Entry of PCT/JP2024/010427 (filed Mar 18, 2024)(PCTJP2024010427)
How Sony's layered robot skin reads pressure
Imagine picking up a raw egg with a robot hand. Too much pressure and it cracks; too little and it slips. Robots today often struggle with this because their surface sensors can't reliably tell the difference between a gentle touch and a firm squeeze.
Sony's patent describes a sensor covered by two distinct layers of material. The inner layer is very soft and flexible, so it deforms easily when something touches it. The outer layer is firmer, meaning it spreads and evens out the force before it reaches the inner layer. Together, they help the sensor underneath read a cleaner, more accurate map of exactly where pressure is being applied and how much.
Think of it like wearing a latex glove over a sponge. The sponge (soft inner layer) squishes to absorb contact, while the glove (firmer outer layer) keeps the shape controlled. The sensor sitting below all of that gets a much clearer picture of what the robot is touching.
… an internal layer portion that is arranged on the sensor section, the internal layer portion being made of a flexible material, and an external layer portion that covers the internal layer portion, the external layer portion being made of a deformable material that has a higher elastic modulus than the material of the internal layer portion.
Translation: The skin uses a soft inner layer topped by a firmer outer layer to help the robot feel pressure.
How the two materials work together under pressure
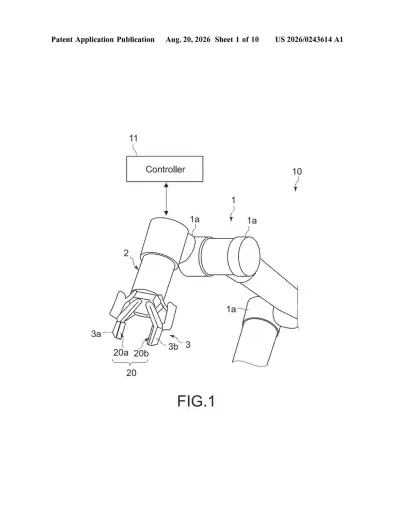
At its core, this patent describes a pressure-distribution sensor wrapped in a two-layer surface coating designed for robotic hands, grippers, or any surface a robot might use to interact with objects.
The internal layer portion sits directly on top of the sensor and is made from a highly flexible material. Flexibility here means the layer deforms a lot with very little force, which lets even small touches register on the sensor beneath it.
The external layer portion covers the inner layer and is made from a material with a higher elastic modulus (meaning it resists deformation more, like rubber compared to foam). This stiffer outer skin does two useful things: it protects the softer inner layer from tearing, and it distributes incoming forces more evenly before they reach the sensor, reducing noise in the pressure readings.
The sensor section itself is capable of detecting a full pressure distribution map, not just a single point of contact. That means the system can tell whether something is pressing on one corner of a gripper pad or across the entire surface, which is essential for delicate manipulation tasks.
The sensor section is configured to be capable of detecting a pressure distribution. The surface layer is arranged on the sensor section, and includes an internal layer portion and an external layer portion.
Translation: The device uses a two-part skin covering a sensor to map out exactly where and how hard something is touching it.
What better robot touch sense means in practice
Robotic touch sensing is one of the harder unsolved problems in physical AI. Most robots today rely on cameras and pre-programmed grip strengths to handle objects, which is why they still struggle with anything fragile, irregular, or unpredictable. A sensor that accurately maps pressure across a surface in real time could let a robot adjust its grip on the fly, the way your fingers do without you thinking about it.
Sony sits at an intersection of consumer electronics, gaming hardware (PlayStation controllers have haptic feedback built in), and professional robotics, so a tactile sensor like this could find its way into more than just industrial arms. The newest Big Tech patents in robotics and sensor hardware show a steady push toward physical AI that can handle the messiness of the real world, and Sony's two-layer skin approach is a concrete step in that direction.
Sony's third filing we've tracked since July in our robot grasping and movement work follows the thumb design application and the collision avoidance one.
Source: US 2026/0243614 A1 at the USPTO (PDF). Full patent text and figures are in the official publication.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Sony patent news breaks.
Add Patentlyze on Google
One click.
There are more where this came from
We read the new patents from Big Tech, carmakers and more and send you the ones worth knowing. Plain English, free, every week.
The drawings · 10 sheets
10 drawing sheets from US 2026/0243614 A1 · click any drawing to enlarge


Show the other 2 sheets


More from Sony
All 722 Sony patents →
More in Hardware
All 2,375 Hardware patents →
Samsung
Samsung Patents a Robot Hand That Adjusts Its Grip Based on What It's Holding
Samsung
Samsung Patents a System That Adjusts Warehouse Robots Around Live Worker Traffic
Intel
Intel Patents a Way to Keep Robots from Drifting Off Course
Samsung