
Nvidia Patents Technology That Measures Object Distance Using Two Cameras
Figuring out how far away something is from a pair of flat camera images is harder than it sounds, especially when objects block each other. Nvidia has filed a patent for a neural network trained specifically to solve that problem.
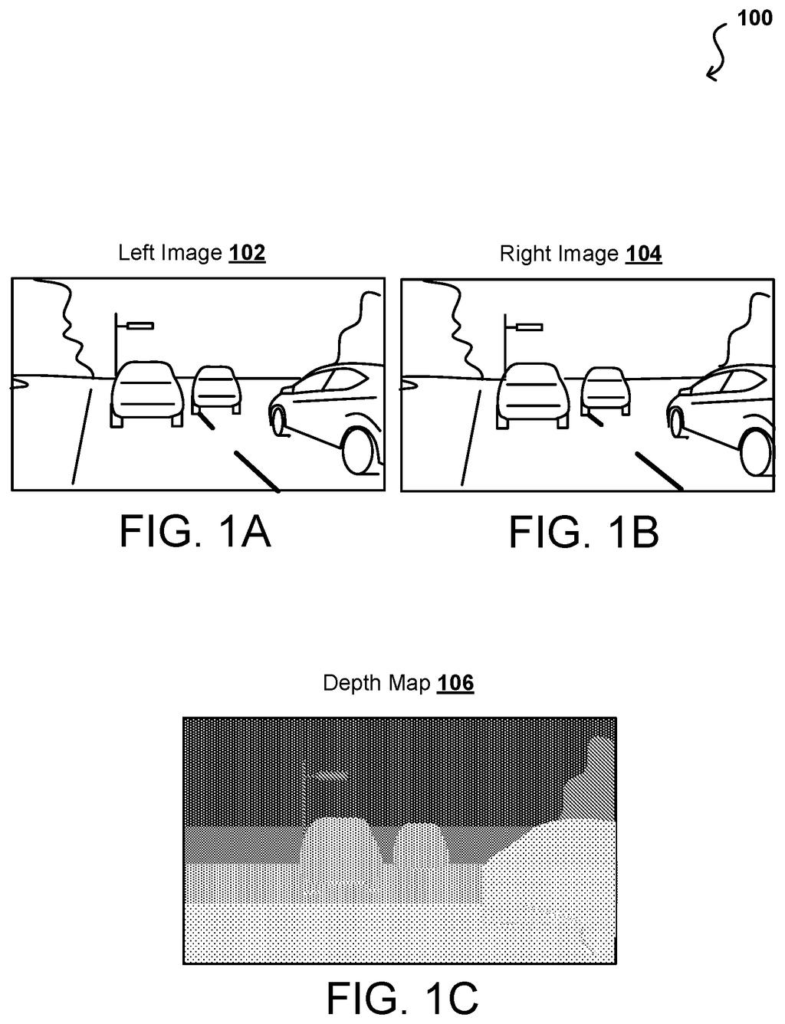
What Nvidia's stereo depth-sensing patent actually does
Imagine you're trying to judge how far away a pedestrian is, but a parked car is partly blocking them. A single camera struggles badly with this, and even two cameras side by side can produce blurry or wrong depth estimates right at those edges.
Nvidia's patent describes a neural network trained to produce distance maps from two cameras mounted side by side, the same setup you find in robots, self-driving cars, and some AR headsets. The key difference is in how the network is trained: it uses special penalty rules that sharpen depth at object edges and handle the spots where one object hides another.
The result is a system that should produce cleaner, more reliable depth information than earlier approaches, particularly around the tricky boundary areas where most depth sensors make their biggest mistakes.
… one or more processors comprising circuitry to use one or more neural networks to determine a distance of objects detected in the scene based, at least in part, on one or more disparity maps and a combination of gradient loss, occlusion loss, and disparity loss calculated using the one or more disparity maps …
Translation: Special computer chips use artificial intelligence to calculate how far away things are by comparing images.
How the disparity network handles overlapping objects
The patent describes what Nvidia calls a disparity network: a neural network that takes two images captured at the same moment by two cameras spaced a small distance apart (stereo cameras) and works out how far away every part of the scene is.
The core idea is in how the network is trained. Instead of just measuring raw pixel error, the training uses two extra penalty terms:
- Gradient loss: penalizes the network when its depth estimate has blurry or incorrect transitions at object edges. This pushes it to produce sharp, accurate depth boundaries rather than smeared ones.
- Occlusion loss: specifically targets the spots where one object hides part of another. These occluded regions are where stereo depth systems typically fail worst, because the left and right cameras see slightly different views of the overlap zone.
During training, the network learns to minimize all three penalty sources together, which forces it to handle edge cases it would otherwise gloss over. At inference time (when the trained model is actually running), it takes a stereo image pair and outputs a dense depth or distance map covering the full scene.
… a disparity network is trained to determine distance data from input stereoscopic images using a loss function that includes at least one of a gradient loss term and an occlusion loss term …
Translation: The AI system learns to measure depth from two camera views by minimizing specific types of visual errors.
What this means for cameras that need to judge distance
Stereo-camera depth sensing is already used in robotics, autonomous vehicles, and some mixed-reality headsets. The persistent weak spot has always been object boundaries and occlusions, where depth estimates fall apart just when you need them most, such as when a robot arm reaches toward an object that's partially behind another.
If this training approach produces measurably better depth maps in those edge cases, it would make existing stereo-camera hardware more useful without requiring new sensors. That's an attractive proposition: Nvidia keeps filing on perception systems for autonomous and robotic platforms, and better depth sensing feeds directly into collision avoidance, scene understanding, and spatial tracking tasks that are central to all of it.
Nvidia's 81st filing we've tracked in self-driving sensing since May builds on earlier applications like depth from regular video and fixing wide-angle distortion.
The legal claims in this patent were canceled before publication, so whatever protection it was meant to establish never took effect, which limits how seriously to take it as a signal of where things are headed.
What the document actually describes is a refinement to how a depth-sensing system learns during training, specifically by penalizing mistakes around edges and blind spots that arise when two cameras see slightly different things. No new hardware is required, but two cameras already need to be mounted, calibrated, and feeding data into a system fast enough to act on it in real time.
The shortest path from this document to something a person could use runs through a platform where all of that infrastructure already exists and only the training process changes. That is a narrow opening even under ideal circumstances, and the canceled claims make it narrower still.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Nvidia patent news breaks.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
54 drawing sheets from US 2026/0300718 A1 · click any drawing to enlarge


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in