
Nvidia Files Patent for a Self-Check in Cars That Aren't Sure Where They Are
A self-driving car's sense of where it is can be wrong, and this Nvidia patent has the car grade that guess and stop trusting it when the score drops. Think tunnels, where there are almost no landmarks to check against.
What Nvidia's car self-check actually does
Imagine your car drives into a long tunnel. GPS fades, and the walls give the car's cameras almost nothing to recognize. The car still has a guess about where it is, but how much should it trust that guess?
Nvidia's patent tackles that problem. A self-driving system normally finds its position by matching what its sensors see against a detailed stored map. This filing adds a second opinion: a separate check that grades how good the position guess is. It looks at two things. One is whether the guess agrees with how far the car has actually moved. The other is how well the landmarks the car sees line up with the map.
If the combined score is low, the car can stop relying on its position guess until things improve. If the score is high, it carries on as usual.
determining, based at least one or more differences between a motion pose and a localization pose associated with a machine within an environment, a pose error associated with the localization pose; …
Translation: The system calculates how far off a vehicle's tracked movement is from where it thinks it is located.
How the car weighs motion against the map
The system has two parts. The first, a localization component, works out the car's localization pose (a technical name for its position and the direction it faces). It starts from GPS, then refines that using camera, LiDAR (laser scanning) and RADAR data matched against a high definition map.
The second part is the error checker, and it computes two errors. The pose error compares the localization pose with a motion pose, built by taking the car's previous pose and applying movement data from motion sensors (accelerometers and gyroscopes). The feature error measures how well things the car sees, such as poles, signs and lane markings, match the same things in the map.
The two errors are combined, optionally with different weights, into an accuracy metric. The filing says this can use a Kalman filter (a standard math tool for blending noisy measurements) and can also output uncertainty. The check reruns as new sensor data arrives, with example intervals from 10 milliseconds to a second, and it avoids fixed time windows, which the filing says made older error estimates less relevant.
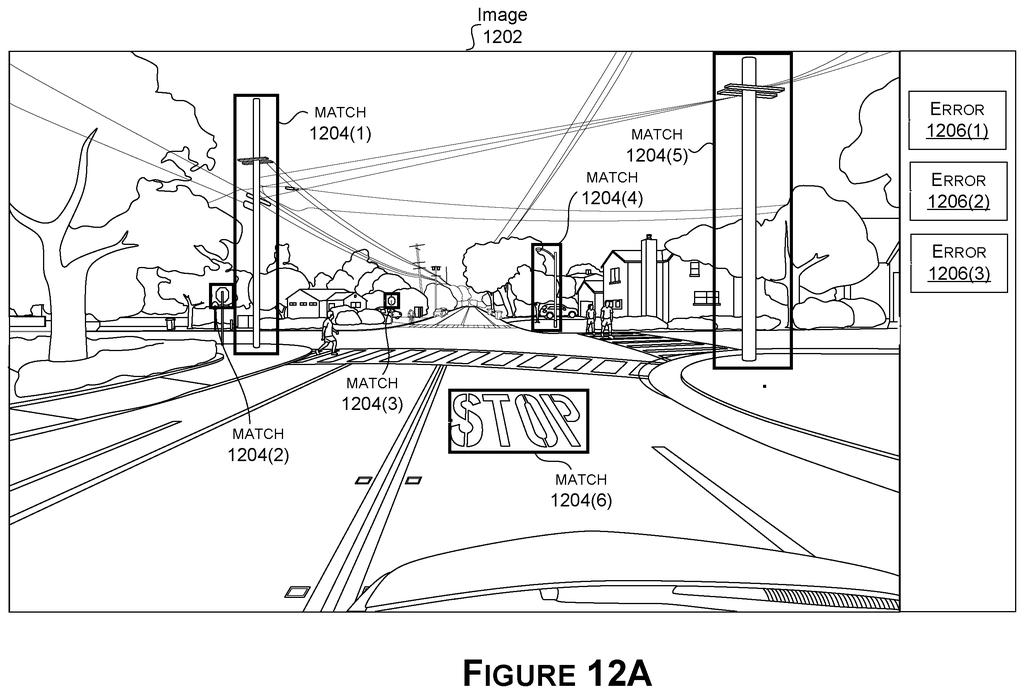
The score is compared against a threshold. In one mode the car does not use its position estimate to navigate, and in the other it does. The filing's examples show a street with six matches (poles, stop signs, a streetlight, a road marking) producing small errors, and a tunnel with no matches producing large ones.
A second component of the vehicle may then determine the error(s) associated with the estimated pose based on both actual motion of the vehicle within the environment, as determined using second sensor data, and comparing features represented by the first sensor data to features represented by the map.
Translation: Another part of the car double checks its position by looking at real movement and matching surrounding objects against stored maps.
What this means for tunnels and driver assist
The most practical result is a car that knows when it might be lost. Driver-assist and self-driving systems rely on a position estimate for steering and planning. If that estimate drifts in a tunnel, in bad weather, or on a street missing from the map, the rest of the car needs a way to tell.
For you, the benefit would show up as a failure that never happens: a car that declines to trust a shaky position instead of steering by it. The filing also lists uses beyond cars, including robots, drones, warehouse vehicles and augmented reality headsets (anywhere a machine has to know where it is). It doesn't say which products would use it.
Nvidia's 94th filing we've tracked since May in the self-driving sensing race builds on work like using maps to spot rare signs and multiplying rare road situations to keep training data sharp.
If you drive a car with lane centering or hands-free features, the moments you would feel this are a tunnel or a storm that blocks the sensors. A car that can say "my location guess is bad right now" can slow down or hand control back sooner. That prevents a specific failure: steering with full confidence from a wrong position.
When it works, you will never see it. Nothing dramatic happens, and that is the point of a safety check.
The filing describes the grading and the switch between modes, but gives no figures for how accurate the grading is or what the car does while it distrusts itself. That second part decides whether you would experience a gentle handover or an abrupt one. As written, it is a sensible safety idea with a clear benefit, and a modest one.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Nvidia patent news breaks.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
The drawings
22 drawing sheets from US 2026/0316784 A1 · click any drawing to enlarge


Show the other 14 sheets


Want this weekly breakdown for a company we don't cover? Patentlyze Pro →
Be the first to weigh in