
Mobileye (Intel)
Mobileye (Intel) · Automotive · Filed Feb 19, 2026 · USPTO published Oct 1, 2026 · Oct 1 release
Mobileye Patents a Camera-Only System That Picks the Perfect Parking Entry Point
Before a self-driving car can squeeze into a parking spot, it has to figure out exactly where to stand first. Mobileye's new patent describes a system that calculates that precise starting position using nothing but camera images.
- Publication number
- US 2026/0296408 A1(US20260296408A1)
- Applicant
- MOBILEYE VISION TECHNOLOGIES LTD.
- Filed · Published
- Feb 19, 2026 · Oct 1, 2026
- Inventors
- Tomer COHEN, Tomer BABA, Shai SHALEV-SHWARTZ, Jonathan Philippe Y. BOINET, Ori PETEL, Sheina GENDELMAN, Mark MATUSEVICH, Victoria PODOLEANU
- Status when we published
- Waiting for an examiner
- Document
- 28 claims
- US classification
- 701/25
- Parent application
- Claims priority from a provisional application 63760757 (filed Feb 20, 2025)
How Mobileye's parking system reads a space before you enter it
Imagine circling a crowded parking garage and spotting an open space. You know you need to swing wide before pulling in, but getting that approach angle right takes real judgment. Mobileye's patent is about teaching a car to make that same judgment automatically.
The system uses cameras already mounted on the vehicle to identify the left and right edges of a parking space, plus the opening where you'd drive in. From those three reference points, it calculates a specific starting position that guarantees the car can slide straight in without clipping either boundary on the way.
Once that starting position is locked in, the car drives itself to that spot and then executes the full parking maneuver. The key promise is that the system never has to make a mid-park correction caused by a bad approach angle, it gets the geometry right before the car commits to the move.
… determine a parking space approach maneuver initial position, wherein the parking space approach maneuver initial position is determined based on the determined first and second indicators of the left and right boundaries and also based on a determined indicator of an entrance to the parking space; …
Translation: The system calculates the ideal starting spot for parking by looking at the parking space boundaries and entrance.
How the system turns painted lines into a precise approach position
The patent describes a processor-based system that takes live camera footage as its primary input. It scans that footage to identify two things: the left and right boundaries of a parking space (think painted lines, curbs, or the sides of neighboring cars) and the entrance to that space, meaning where the open end of the spot faces the lane.
From those three detected references, the system computes what the patent calls a parking space approach maneuver initial position. Think of this as the exact spot on the road where the car should stop, oriented at the right angle, before beginning its entry move. The math behind this position is specifically designed so the car's full body outline (called the vehicle envelope in the patent) will stay between the boundaries all the way through the maneuver.
Critically, the claim requires that once the car starts from this initial position, it can complete the entire parking maneuver without the vehicle ever crossing or touching the left or right boundary inside the space. No mid-maneuver corrections, no back-and-forth shuffling caused by a bad entry angle.
- Camera images in: the system reads live sensed image data
- Boundary detection: identifies left edge, right edge, and space entrance
- Position calculation: determines the mathematically safe approach point
- Actuator control: steers and drives the car from that point into the space
One or more actuator systems associated with the host vehicle may be caused to active to cause the host vehicle to navigate into the parking space from the parking space approach maneuver initial position.
Translation: It then automatically triggers the vehicle controls to drive the car straight into the parking spot from that starting position.
What this means for camera-only self-parking cars
Most parking-assistance systems on the market today rely on ultrasonic sensors or a mix of radar and cameras. A system that works from cameras alone is cheaper to produce and easier to deploy across a wider range of vehicles, since cameras are already standard on most modern cars for lane-keeping and collision-warning features.
For drivers, the practical upside is a parking move that doesn't require the car to stop, reverse, and re-approach because it misjudged the entry. The system's logic front-loads all the geometry work before the car makes its first turn. Mobileye's long bet on camera-first perception makes this patent a logical piece of their broader autonomous-driving stack, not a standalone gimmick. If the approach holds up in practice, it could make automated parking more reliable in tight real-world spaces where ultrasonic sensors often struggle with distance and direction.
Intel's fourth filing we've tracked in our self-driving sensing race watchlist since September follows the dashboard message timing patent and Mobileye's distance from road slope work.
Source: US 2026/0296408 A1 at the USPTO (PDF). Full patent text and figures are in the official publication.
Get our take in your Top Stories
Liked this breakdown? Add Patentlyze as a preferred source on Google, and our plain-English take shows up more often in your Top Stories the next time Intel patent news breaks.
Add Patentlyze on Google
One click.
There are more where this came from
We read every patent application Big Tech publishes and send you the ones worth knowing. Plain English, free, every week.
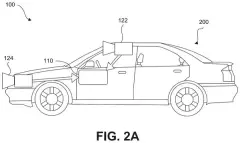
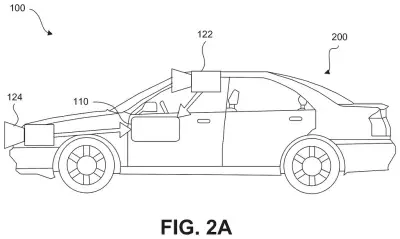
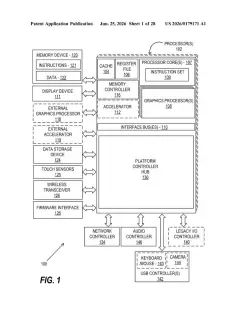
The drawings · 68 sheets
68 drawing sheets from US 2026/0296408 A1 · click any drawing to enlarge


Show the other 52 sheets


Sheets 61 to 68 are in the full USPTO filing.
More from Intel
All 199 Intel patents →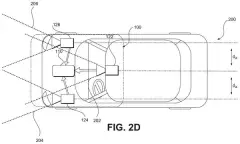
More in Automotive
All 377 Automotive patents →
Nvidia
Nvidia Patents a System That Catches Self-Driving Cars Acting Erratically Before a Crash
Nvidia
Nvidia Patents a Camera View System That Switches 3D Modes While You Park
Nvidia
Nvidia Patents a System That Tells Self-Driving Cars When Their Cameras Are Too Slow
Nvidia
No comments yet