New Google Patents For Waymo's Robotaxi Senses, and what they reveal
This watchlist tracks Waymo patents on sensing and prediction: hearing sirens through microphones, adapting lidar to fog, spotting hidden pedestrians and wobbly cyclists, and filtering out glare from reflective signs. Together they show Waymo building layered awareness so its robotaxis can react before a hazard becomes visible.
based on all tracked filings in this watchlist · refreshes every week
Google is filing patents around how its self-driving cars collect, share, and check the quality of what they see, covering the cameras, light sensors, and the chips that process it all.
The filings cluster most heavily around two problems: helping the cars see clearly in tough conditions like darkness and bad weather, and making sure the sensors are working properly so the car knows when its vision is limited.
What’s new in Waymo's robotaxi senses
a dated entry each week this watchlist moves · older entries stay archived
Sep 17, 2026 2 filings joined
This week's filings both deal with how the car handles information under pressure. One covers cutting unneeded sensor data; the other covers planning gear changes ahead of time.
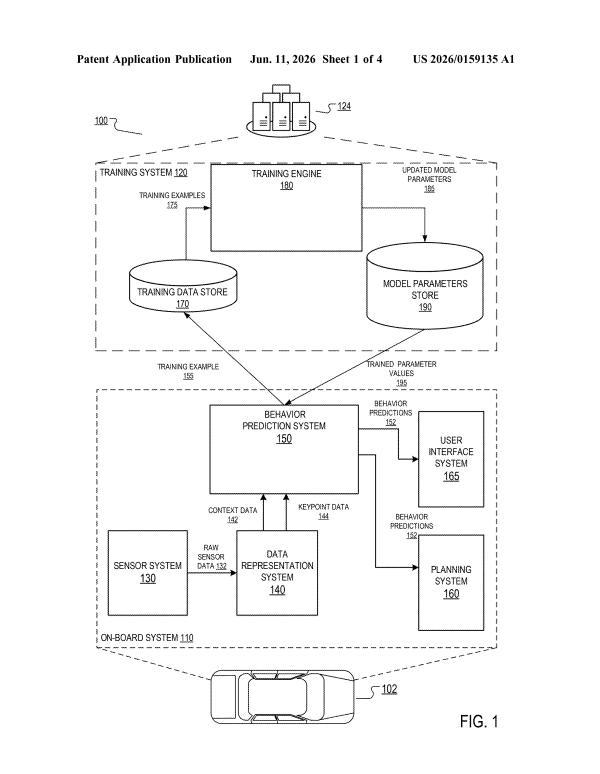
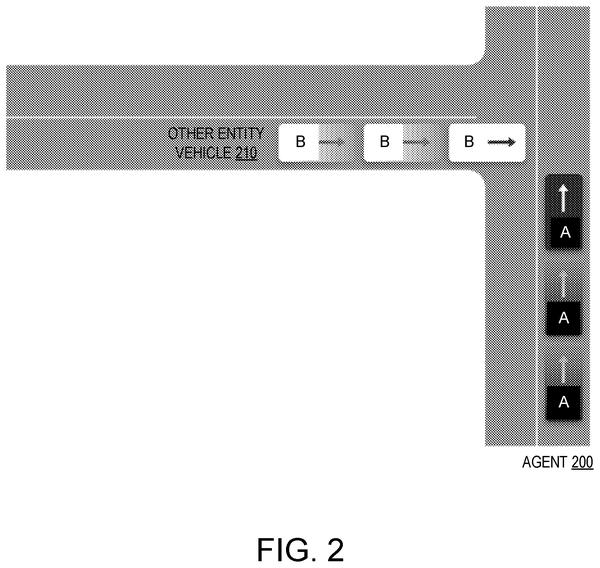
This week's filing focuses on predicting crashes before they happen. Waymo is working on software that watches every nearby object and guesses where it will move next.
This week's new filing looks at using laser light bouncing off rain, fog, or snow to help a self-driving car figure out what the weather is doing around it. The focus is on helping the car's sensors read the road even when conditions are bad.
Aug 27, 2026 2 filings joined
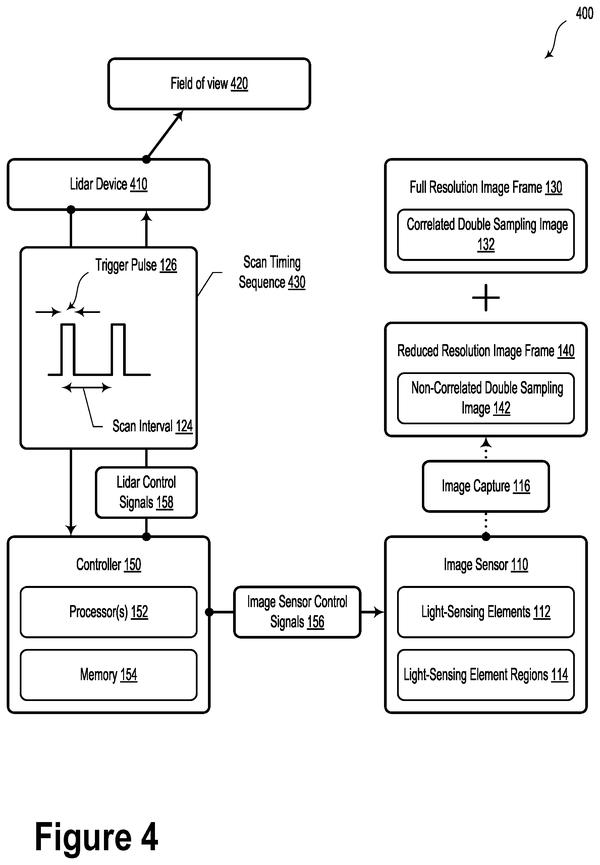
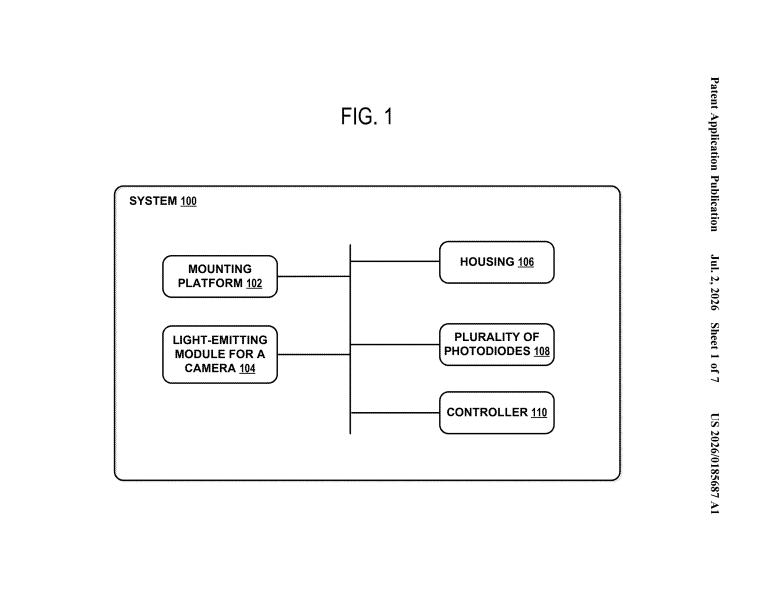
This week's filings focus on how Waymo's self-driving cars see and respond to the world around them. One filing covers predicting how quickly a human driver will react, while the other looks at using laser sensors to help cameras capture clearer images in the dark.
Aug 20, 2026 1 filing joined
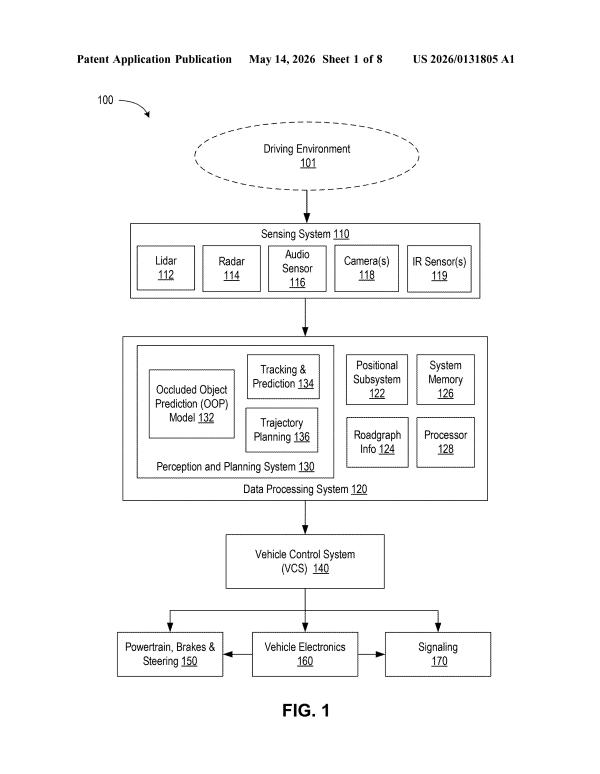
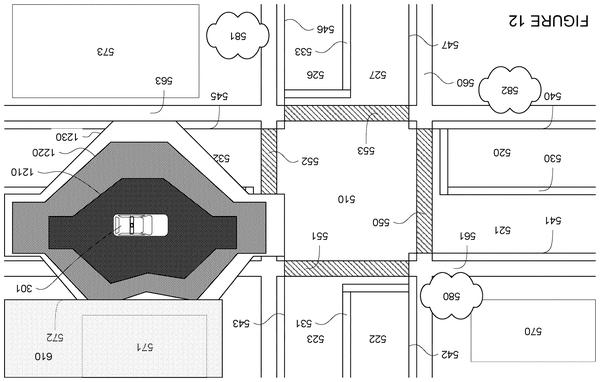
This week's filing focuses on how Waymo's self-driving cars handle spots the car's sensors cannot see, suggesting the team is working on ways to keep the car moving safely even when part of its view is blocked.
the problems Google keeps filing on · each with its three newest filings · new filings join every week
Sensors That Know When They're Broken 7 filings
A self-driving car that can't see is dangerous, but only if it doesn't know it can't see. These filings cover ways for the car's sensors to detect their own failures, from radar going quiet to cameras losing clarity to fog and frost blocking the view.
Pedestrians often step out from behind things with no warning, giving the car almost no time to react. These filings cover ways to predict where hidden people are, read body language, and spot cyclists about to fall.
Cameras and Lidar Working Better Together 9 filings
Each sensor type has blind spots and weaknesses the other can cover. These filings address how to combine spinning light sensors with cameras, cut lag, improve long-range clarity, and stop sensors from interfering with each other.
Teaching a car to understand its surroundings the way a person would describe them is a hard problem. These filings cover systems that let the car answer questions about what it sees, predict what it will see next, and connect sensor data to plain language.
A self-driving car needs to guess what every nearby vehicle and person is about to do, not just react after it happens. These filings cover predicting crashes between other cars, planning routes while reading other drivers, and forecasting a few seconds ahead.
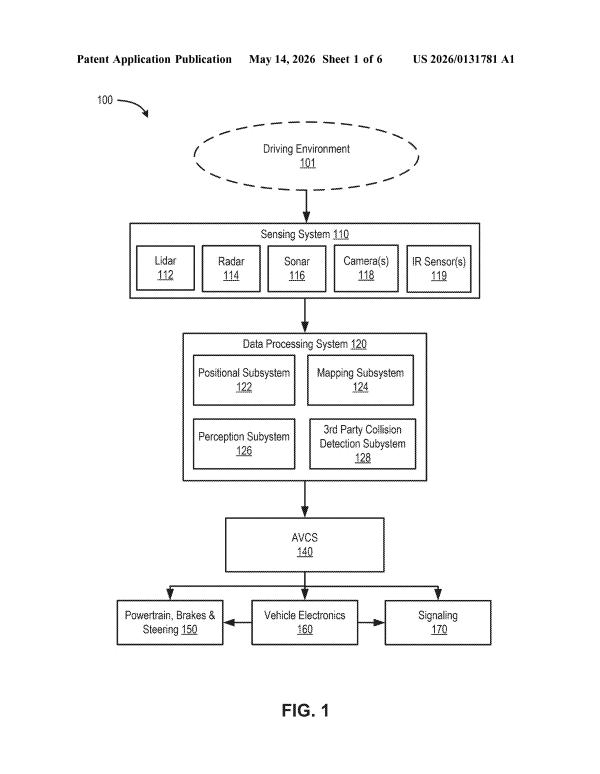
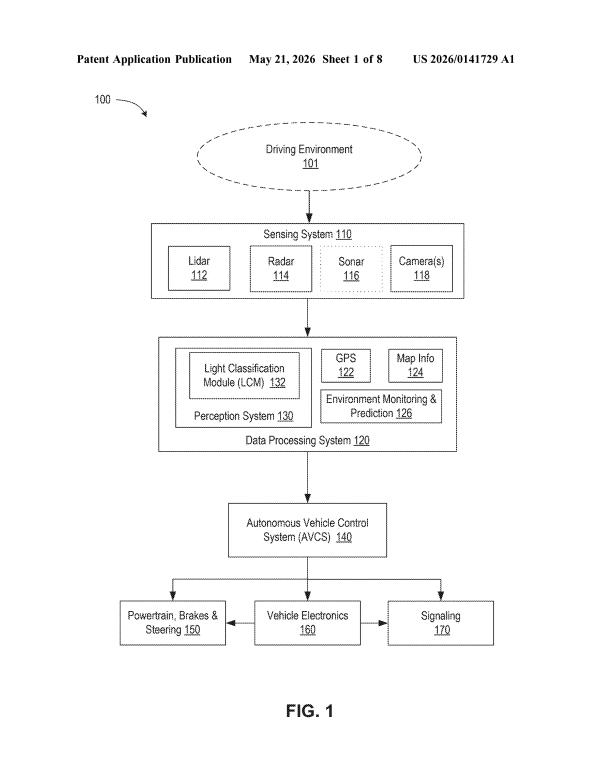
Filtering raw LIDAR output in real time lets Waymo reduce the computational load without sacrificing the detection of nearby hazards like pedestrians and cyclists that the watchlist tracks.
A car that shifts too late lurches and confuses passengers. Waymo's system predicts upcoming road geometry from sensor data to pre-stage gear changes, keeping acceleration and deceleration smooth enough to feel deliberate rather than reactive.
Extends the sensing work by adding prediction: the system forecasts trajectories for the vehicle and every nearby object, then checks for path intersections before they happen. Shifts collision detection from reactive to proactive.
Knowing road grip in real time means the car can brake appropriately before losing traction. This filing extends lidar beyond obstacle detection to surface conditions, filling a gap where maps and weather data can't measure what's actually under the wheels.
Estimating human reaction latency fills a gap in Waymo's existing sensing toolkit, which tracks object detection and motion prediction but not the cognitive delay between when a hazard appears and when surrounding road users actually respond to it.
Dual-exposure camera captures synchronized with lidar pulses to maintain image sharpness across sudden lighting transitions, directly sharpening the sensor fusion that glare filtering alone cannot solve.
A robotaxi in heavy rain needs to know which sensors have gone blind and by how much, then adjust speed and following distance accordingly. This patent maps each sensor's degradation in real time so the car can compensate before it gets into trouble.
Narrowing a sensor's field of view when weather degrades it keeps the system focused on nearby, readable space instead of trying to see farther through rain or fog where readings fail. This sharpens the car's ability to spot obstacles that matter most.
The watchlist so far treats sensing as a solo problem: one car filtering its own data. This filing introduces a networked layer where vehicles pull live sensor feeds from nearby cars or roadside infrastructure to see past physical obstructions.
The watchlist already covers adapting lidar to fog; this patent adds a monitor that detects when sensor degradation happens, so the car knows when it can't trust what it's seeing.
The fleet-learning approach extends beyond what individual sensors see: cars can now inherit warnings about hidden pedestrians from previous trips through the same locations.
A robotaxi needs to spot the actual passenger among dozens of pedestrians and confirm the match before pulling up. This patent adds visual tracking of foot traffic patterns to solve that identification problem.
The watchlist so far covers Waymo's work filtering out interference: glare, fog scatter, hidden objects. This filing adds a hardware fix, using coated optics to prevent light loss before it even enters the waveguide, tightening signal quality at the source.
After establishing how robotaxis need to see through fog and darkness, this filing shows the sensor hardware itself: a custom amplifier that lets lidar handle bright and dim reflections at once, the way human eyes adjust to sudden changes in light.
Uneven infrared output would blind night-vision cameras in dark conditions. Waymo's rotating test rig catches these flaws before lights go into cars, ensuring consistent sensor performance across all angles.
Incremental forward creeping controlled by remote operators lets the car gather sensor data around obstructed corners without committing to a full crossing, extending the robotaxi's ability to move through situations where its own perception hits a wall.
A robotaxi's software needs validation before deployment, and replaying thousands of recorded road scenarios lets Waymo verify that new code produces the same steering, braking, and decision points as proven driving behavior.
The watchlist has shown how Waymo's sensors need to work together to see clearly. This filing reveals how lidar actively protects cameras from overexposure when bright light floods the scene.
A robotaxi that knows where parking exists before arriving eliminates the circling phase entirely, letting the car navigate straight to an available spot or wait efficiently rather than burning time on search.
After building a car that listens and predicts, Waymo now sharpens what it actually sees: a camera that locks exposure faster than human eyes adjust to sudden light changes.
Detecting physical failures in the vehicle itself, flat tires, cargo shift, trailer misalignment, fills a blind spot in autonomous sensing that exists beyond the road ahead.
Three specialized cameras covering near, mid, and far ranges let the system detect both curb-side pedestrians and distant obstacles in one unified view, filling gaps that single-lens designs leave blind.
A robotaxi that can't trust its own sensors is grounded. This filing shows how Waymo plans to keep radar working as a reliable input by catching degradation before it turns into blind spots.
The prediction layer fills in what the car needs after it perceives the scene: given what cameras and lidar see right now, what does the road hold in the next few frames. That forecast feeds into planning the safe next move.
Recognizing objects at the sensor itself cuts the latency and bandwidth needed to process what a robotaxi sees. This shifts the computational load from the car's central computer to individual cameras, each running its own AI model suited to its viewing angle.
A unified prediction model that plans the car's path and forecasts other vehicles' movements in one step, eliminating the lag that comes when separate systems must sync their outputs.
Tracking a pedestrian's 3D skeleton in real time lets the car spot weight shifts and shoulder angles that precede crossing, catching intent before the person moves.
Comparing live sensor data against stored map geometry lets the car catch a drifted camera or lidar without needing a service visit, filling a gap in the perception pipeline that earlier patents assumed was already solved.
A robotaxi that can't see through frost becomes a liability. Dual heating zones let Waymo keep critical sensors clear without the power drain of uniform heating across the entire window.
After showing how robotaxis can see through obstacles, this filing reveals how they measure visibility itself, using camera and lidar data to gauge fog and rain density rather than guess from appearance alone.
Radar crosstalk between nearby autonomous vehicles creates false detections and blind spots. Waymo's solution assigns each vehicle a distinct code sequence so their signals don't interfere, letting multi-car fleets operate safely in tight urban spaces.
Keeping the car moving safely when onboard computers fail requires two independent computing systems that can each steer the vehicle to a safe stop, confirming Waymo's bet that redundancy matters more than a single powerful processor.
Filtering which nearby agents matter most before computing their paths cuts the neural network's processing load, letting predictions run faster on the robotaxi's onboard hardware.
A robotaxi that sees dead zones around it would gain confidence in murky conditions. This filing shows how to convert wasted sensor data, light the LiDAR already captures but ignores, into a makeshift map of whatever its main laser pulses miss.
After showing how robotaxis sense hazards on the road, Waymo now maps what happens when they leave it. This patent puts the vehicle itself in charge of finding the right maintenance bay, turning depot logistics into a navigation problem the car solves solo.
A robotaxi that narrates what it observes can feed those descriptions into prediction models, giving the system a way to reason about unfolding situations using language as an intermediate step rather than jumping straight from sensor data to forecasts.
The prediction theme extends beyond traffic and weather: Waymo is now working to spot the instant a cyclist or pedestrian begins to lose balance, giving the car milliseconds to brake before impact rather than reacting after someone has already fallen.
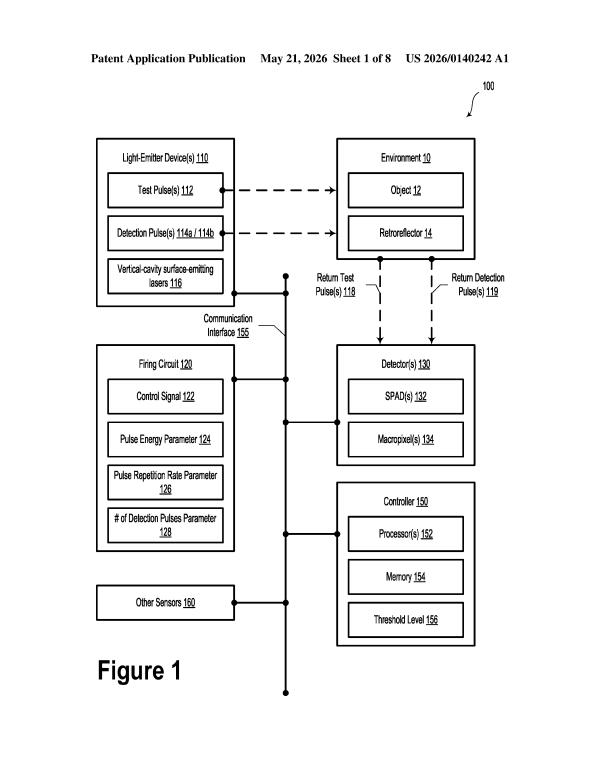
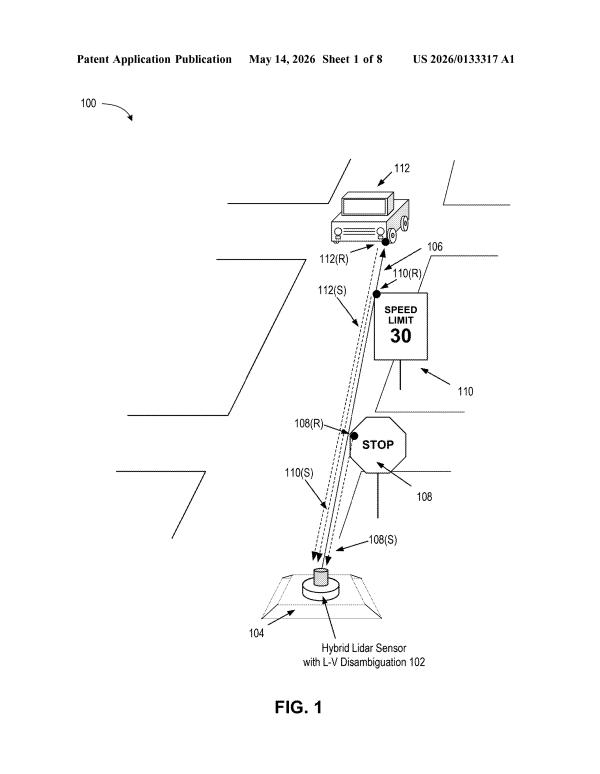
Lidar's vulnerability to retroreflectors, surfaces designed to bounce light straight back and saturate the sensor, requires early detection so the car can adjust its laser power before losing visibility of actual obstacles nearby.
A localized vision-language model lets the car's planning and prediction systems query specific road regions directly, avoiding the computational cost of re-analyzing entire camera feeds each time a subsystem needs clarification on what it's seeing.
A robotaxi that learns from rare edge cases needs exposure to them. This filing shows how Waymo routes its fleet to deliberately seek out the specific scenarios its system still struggles with, rather than hoping chance encounters provide enough training data.
After building a car that sees and predicts, Waymo now ensures it can execute safely: a real-time grip calculator that lets the robotaxi know its own limits on wet roads before it commits to a maneuver.
Predicting hydroplaning requires knowing not just that rain fell, but how much water actually clings to pavement. Waymo's deep learning model measures surface wetness in real time, letting its robotaxis adjust behavior before losing grip.
Two cameras watching the same brake lights from different angles let Waymo filter out reflections and dirt, confirming the robotaxi needs multiple viewpoints to trust what it sees on the road ahead.
Pairing distance to velocity readings stops the sensor from assigning a cyclist's speed to a bus or vice versa, a confusion that could send the car's prediction system wildly off course at intersections.
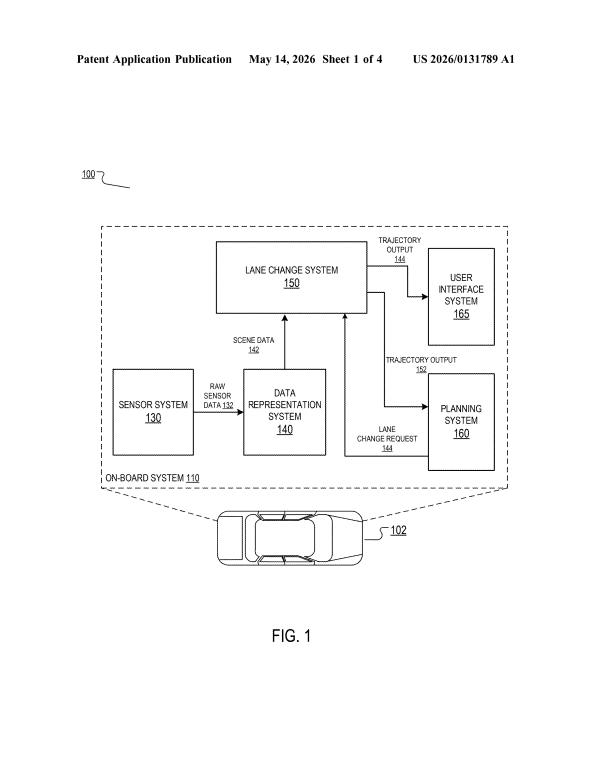
Generating multiple lane-change paths and ranking them by predicted driver behavior adds a prediction layer to the robotaxi's decision-making, moving beyond static obstacle detection.
A robotaxi that spots danger between other road users can slow or steer clear before wreckage spreads into its path, turning prediction of third-party crashes into collision avoidance for itself.
After learning to see through fog and hear sirens, the robotaxi now reasons about what lurks beyond its line of sight, assigning risk scores to invisible pedestrians based on context clues.
Microphone arrays that detect siren frequencies let the robotaxi respond to emergency vehicles before they enter the camera's field of view, compressing the reaction delay that plagues lidar-and-camera-only systems.
Converting raw sensor streams into usable maps has meant separate pipelines for different data types; this filing shows how a single transformer model can fuse camera, lidar, and radar directly into steering commands.
Questions readers ask
What does this Waymo patent watchlist actually track?
It follows Waymo patent filings about how its self-driving cars sense the world and predict what people and other vehicles might do next, from hearing sirens and reading fog to guessing when a hidden pedestrian or wobbly cyclist could move into the road.
Do these patents mean Waymo robotaxis already hear sirens or see through fog today?
Not necessarily. A patent shows a system Waymo has designed and filed for legal protection, which points to research direction. It does not confirm the feature is running in current robotaxis on public roads.
Why do so many filings focus on predicting what other road users will do?
Several patents in this watchlist model hidden pedestrians, cyclists losing balance, and crashes between other vehicles. That pattern suggests Waymo is spending real engineering effort on anticipating danger before it happens, not just reacting to what a sensor sees at that moment.
How is this different from a typical self-driving sensor patent?
Many filings here combine sensing with judgment, like a lidar that adapts to fog or filters reflective glare, paired with models that decide what a lane change, an acceleration, or a stranger's next move should look like, rather than covering hardware alone.
Want this weekly breakdown for a company we don't cover?
Patentlyze Pro →
The weekly email: the best of Big Tech's filings, in plain English. Free.